Related Experiment Video
Updated: Jun 22, 2025
Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
Connectivity preservation control for multiple unmanned aerial vehicles in the presence of bounded actuation
Xianghong Xue1, Bin Yuan1, Yingmin Yi1
1Department of Automation and Information Engineering, Xi'an University of Technology, Xi'an, 710048, China.

Abstract:
This paper proposes a novel multi-unmanned aerial vehicle (UAV) connectivity preservation controller, suitable for scenarios with bounded actuation and limited communication range. According to the hierarchical control strategy, controllers are designed separately for the position and attitude subsystems. A distributed position controller is developed, integrating an indirect coupling control mechanism. The innovative mechanism associates each UAV with a virtual proxy, facilitating connections among adjacent UAVs through these proxies. This structuring assists in managing the actuator saturation constraints effectively. The artificial potential function is utilized to preserve network connectivity and fulfill coordination among all virtual proxies. Additionally, an attitude controller designed for finite-time convergence guarantees that the attitude subsystem adheres precisely to the attitude specified by the distributed position controller. Simulation results validate the efficacy of this distributed formation controller with connectivity preservation under bounded actuation conditions. The simulation results confirm the effectiveness of the distributed connectivity preservation controller with bounded actuation.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:14
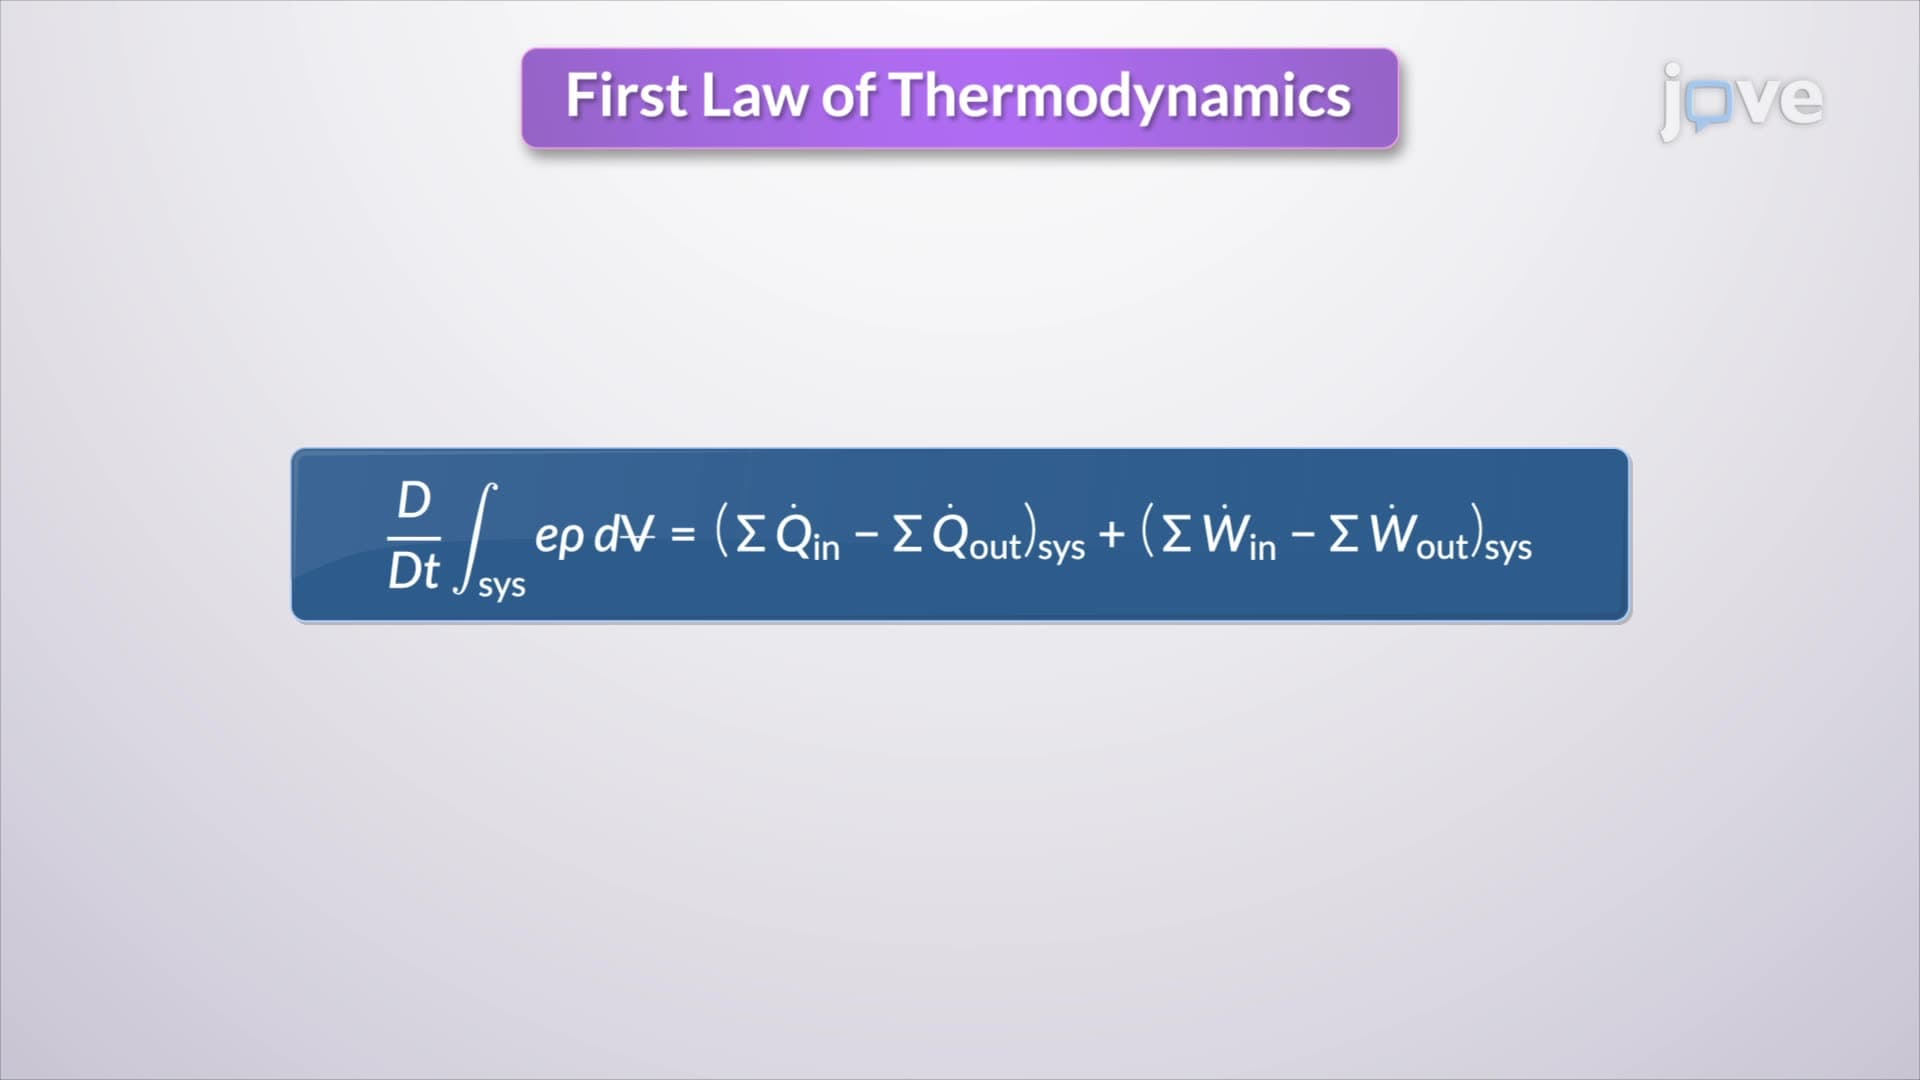
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:21
Pilot and Numeric Relaying
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:14
Conservation of Mass in Moving, Nondeforming Control Volume
In the context of a detention basin, the conservation of mass states that the total mass of water entering the basin must equal the mass leaving the basin plus any accumulation of...
 01:07
Conservation of Mass in Fixed, Nondeforming Control Volume
In the case of a sewer pipe, which can be modeled...