Related Experiment Video
Updated: Jun 21, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Robust internal model control based on a novel generalized extended state observer and its application on a
Fan Wang1, Tianji Cheng2, Feng Jing1
1Xi'an Institute of Optics and Fine Mechanics, Chinese Academy of Sciences, Xi'an 710119, China; Key Laboratory of Space Precision Measurement, Chinese Academy of Sciences, Xi'an 710119, China.

Abstract:
Disturbance observer (DOB) and extended state observer (ESO) are extensively utilized to handle external disturbances and model uncertainties in the control system. Nevertheless, the integration of these two methods to improve disturbance suppression remains an open question. In this research, the disturbance compensation mechanism of DOB is employed to compensate the disturbance estimation error of ESO, thereby achieving an effective integration of DOB and ESO. Additionally, a generalized ESO (GESO) is proposed to replace ESO. A robust internal mode control (RIMC) scheme is then developed by incorporating GESO into a two-degree-of-freedom internal mode control (TDF-IMC) framework. Moreover, the equivalence of RIMC and classical TDF-IMC is given by a rigorous derivation under the frequency domain description. Finally, the RIMC is applied to the control of a two-inertia system to verify its superiority in terms of robustness, disturbance rejection, and resonance suppression.

Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:18
Second Order systems II
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
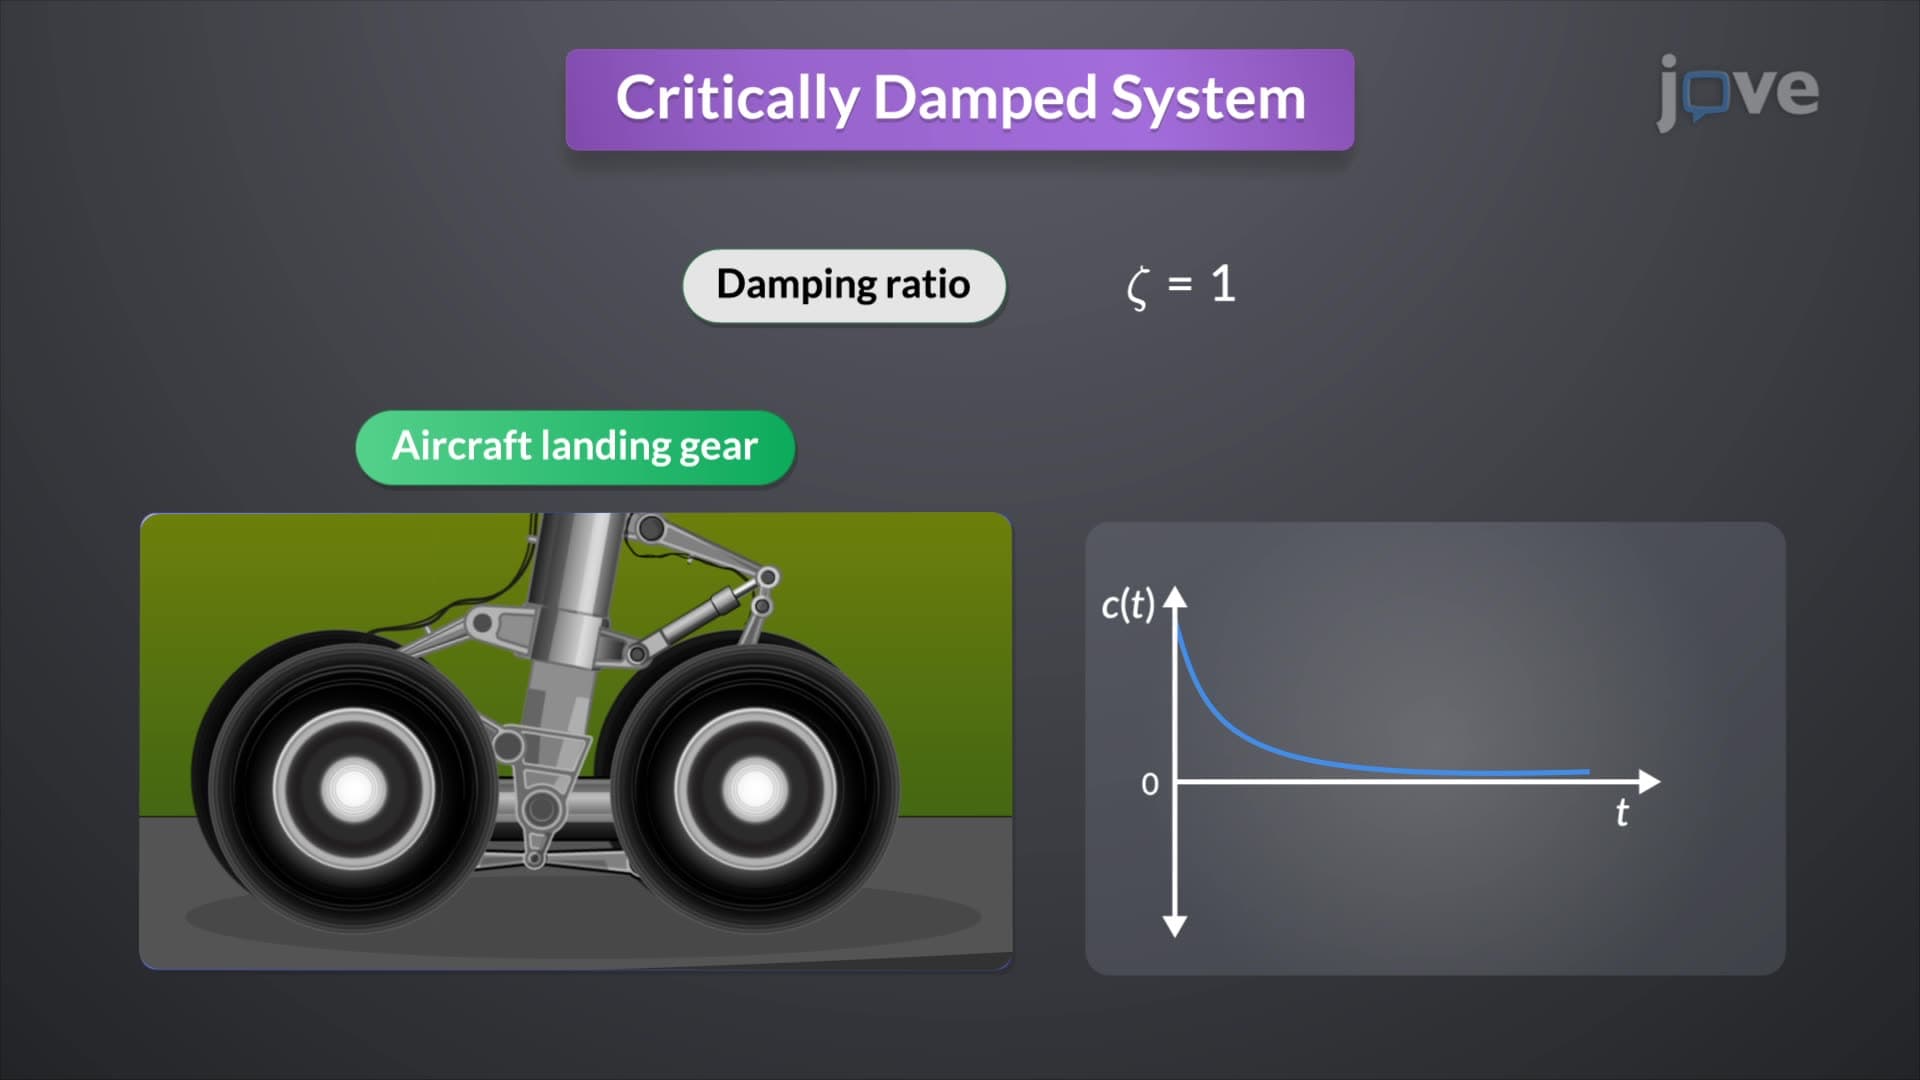 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...