CART-based wide-area damping controller for inter-area oscillations in bulk power system consisting of WAMS data
Related Experiment Video
Updated: Jun 18, 2025

Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
1Department of Electrical Engineering, Velayat University, Iranshahr 99111-31311, Iran; School of Electronic and Electrical Engineering, University of Leeds, Leeds LS2 9JT, United Kingdom.

Abstract:
The paper proposes a WADC approach using CART technique to dampen inter-area oscillations (IAOs) in bulk power systems. In this case, PMU data are filtered to estimate inter-area dynamics in which using pade approximation, a pole-zero IAO compensation block is designed. An online random decrement technique is also developed to identify the coherent groups and damping ratios to activate the WADC for oscillation damping. An offline process is provided to identify 200 critical IAO contingencies and tunes WADC gains using PSO for training CARTs via a set of 200 input inter-area signals and assigning output controlling gains pre-trained data and evaluating the CART estimations through online operation. The WADC approach is validated for oscillation damping on a 39-bus system and a realistic 561-generator Iranian grid. Simulations show 98 % accuracy in achieving sufficient damping ratios (>0.6) across various operating conditions.
More Related Videos
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:28
Load-frequency control
 01:07
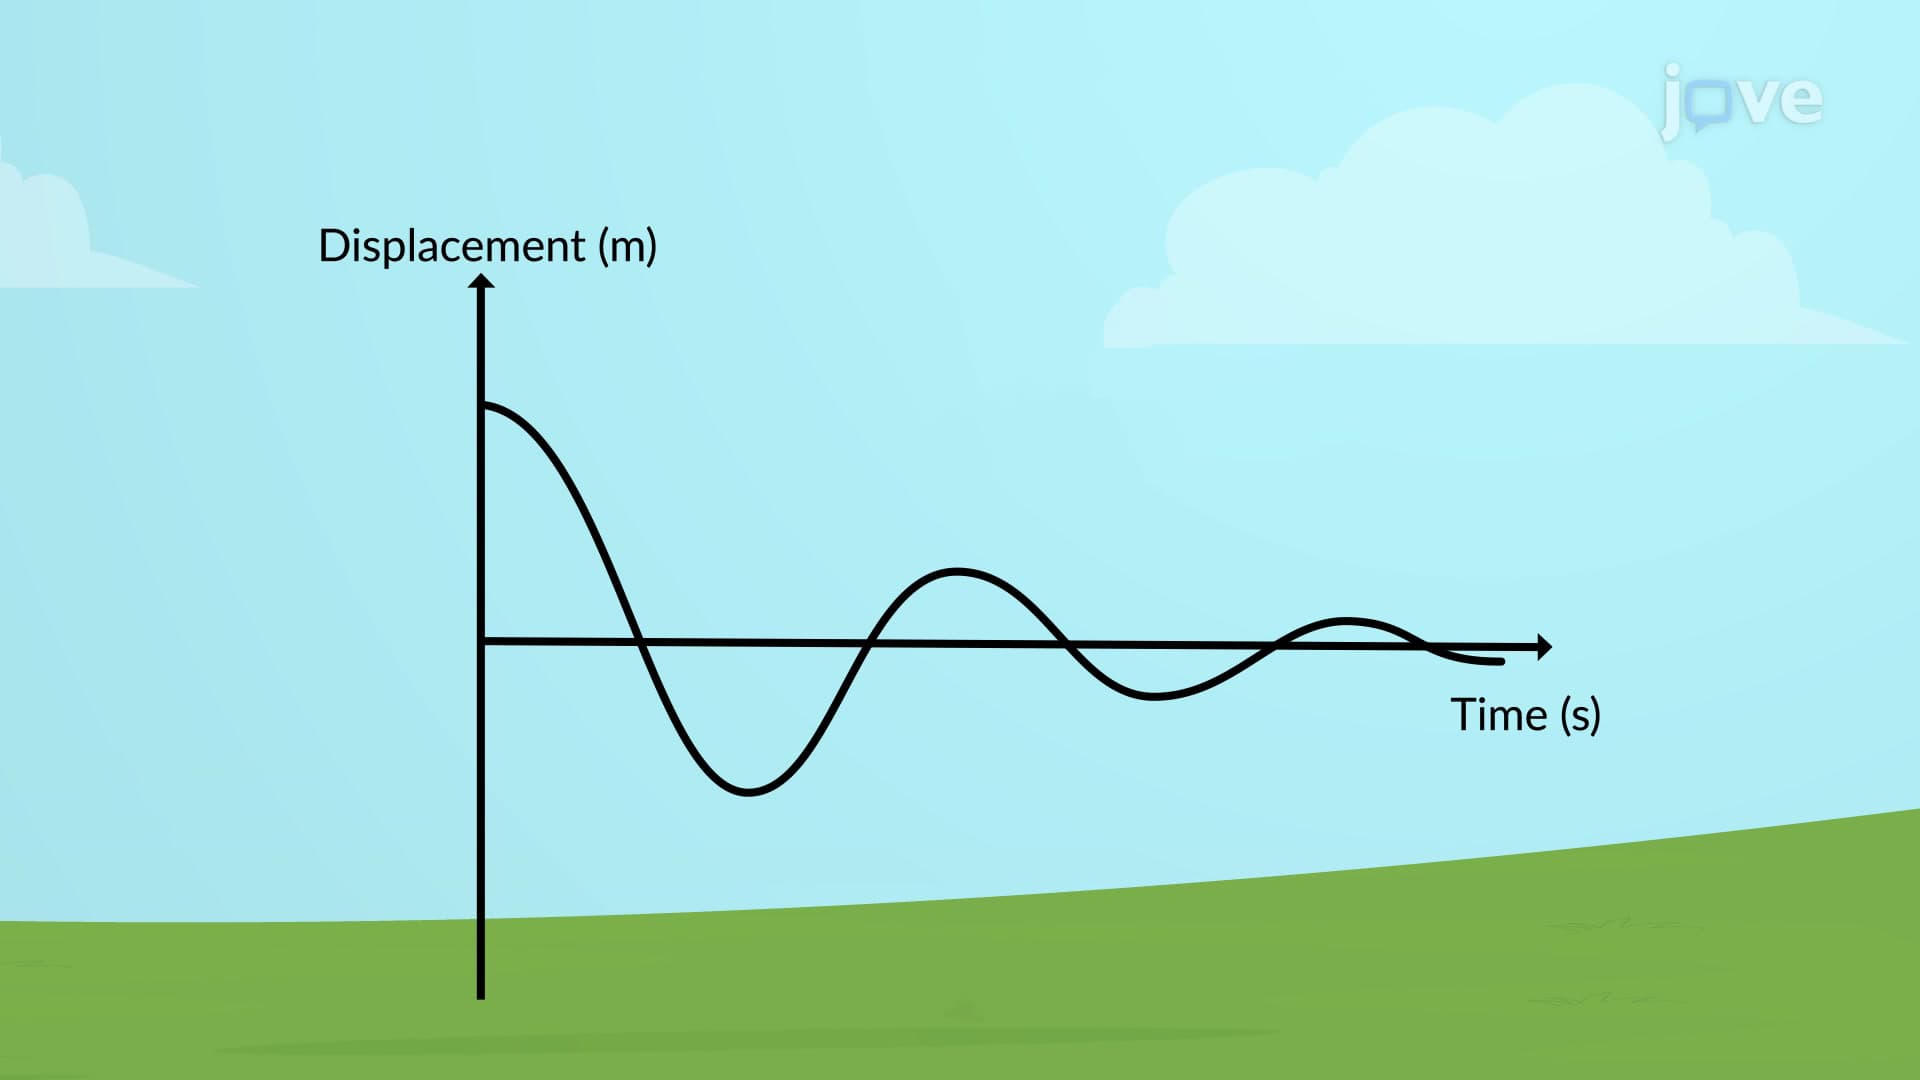
Damped Oscillations
Although friction and other non-conservative...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:20
Types of Damping