Related Experiment Video
Updated: Jun 15, 2025
Robotic Sensing and Stimuli Provision for Guided Plant Growth
Published on: July 1, 2019
Apple-Harvesting Robot Based on the YOLOv5-RACF Model
Fengwu Zhu1, Weijian Zhang1, Suyu Wang1
1College of Engineering and Technology, Jilin Agricultural University, Changchun 130118, China.

Abstract:
To address the issue of automated apple harvesting in orchards, we propose a YOLOv5-RACF algorithm for identifying apples and calculating apple diameters. This algorithm employs the robot operating dystem (ROS) to control the robot's locomotion system, Lidar mapping, and navigation, as well as the robotic arm's posture and grasping operations, achieving automated apple harvesting and placement. The tests were conducted in an actual orchard environment. The algorithm model achieved an average apple detection accuracy (mAP@0.5) of 98.748% and a (mAP@0.5:0.95) of 90.02%. The time to calculate the diameter of one apple was 0.13 s, with a measurement accuracy within an error range of 1-3 mm. The robot takes an average of 9 s to pick an apple and return to the initial pose. These results demonstrate the system's efficiency and reliability in real agricultural environments.
More Related Videos

Related Concept Videos
 00:48
Optimal Foraging
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:30
Machines: Problem Solving II
 01:19
Machines
A free-body diagram of the...
 01:14
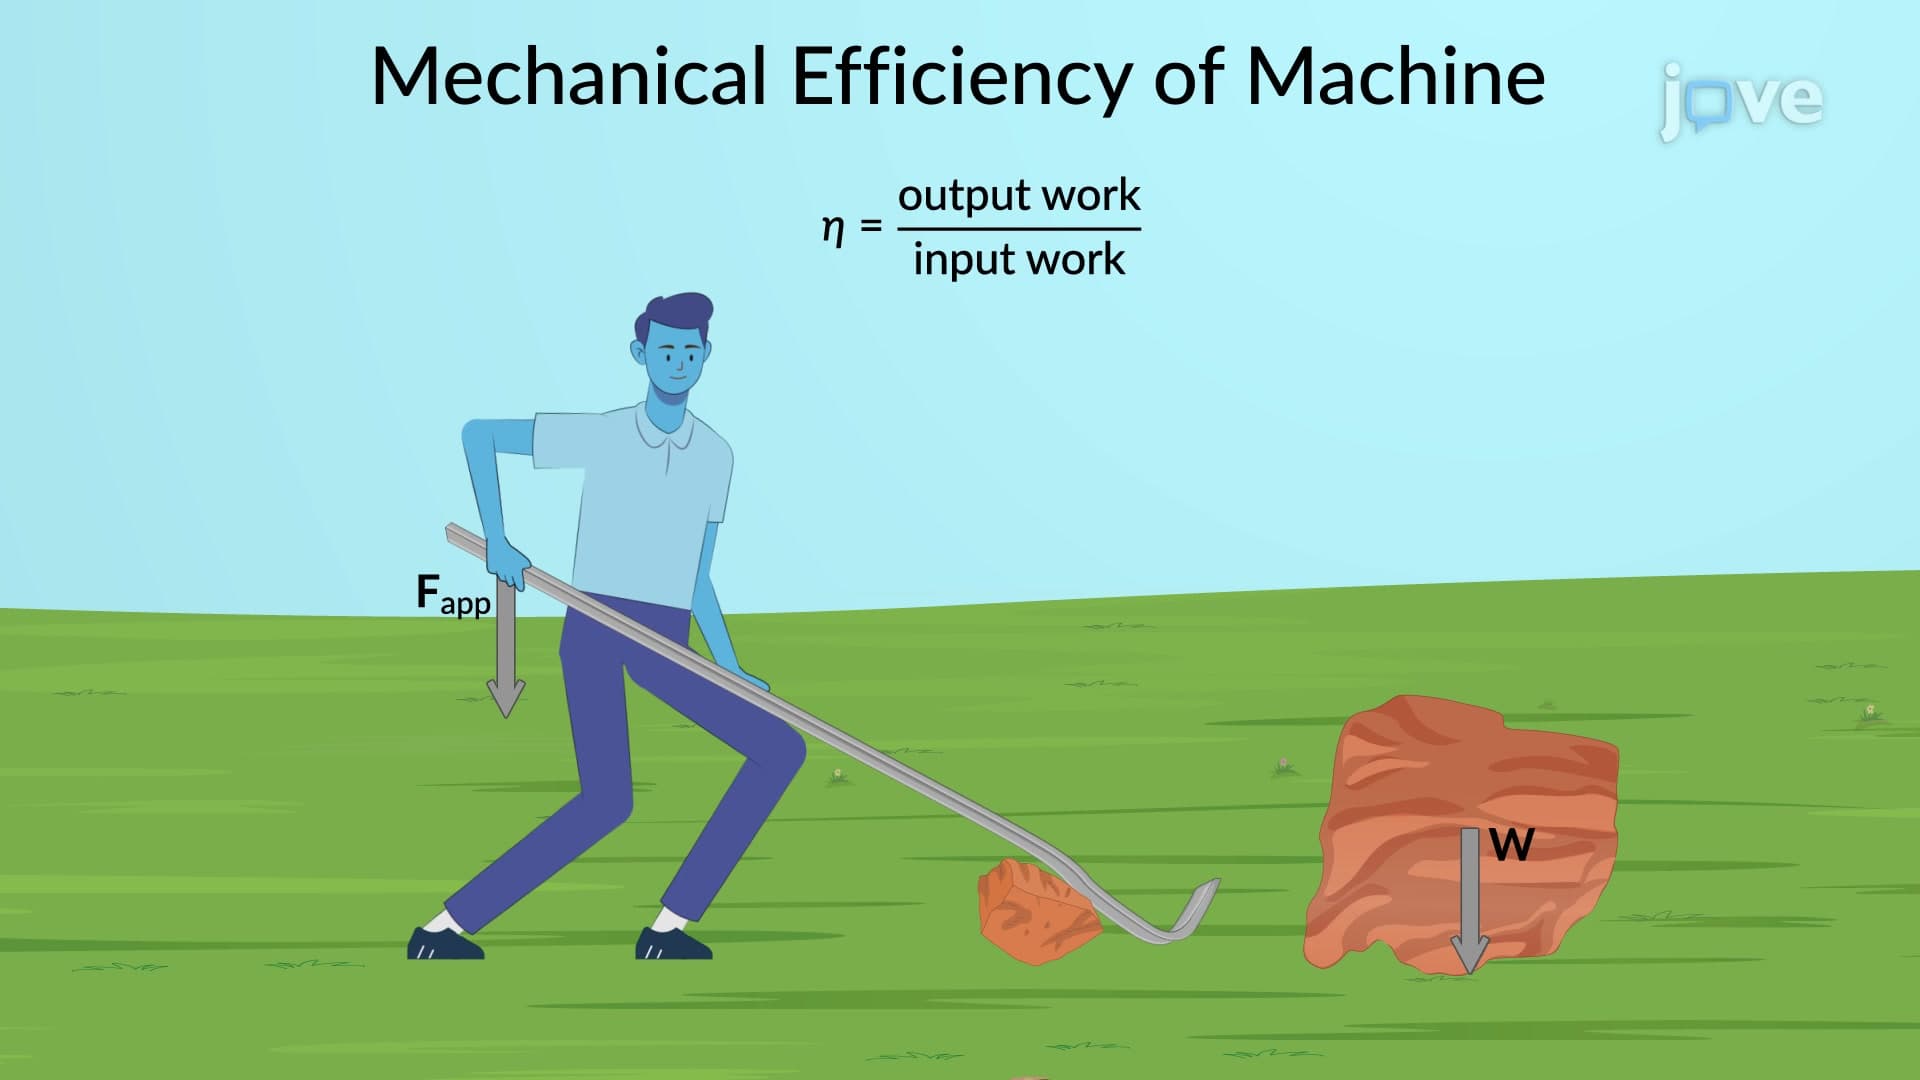
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...