Related Experiment Video
Updated: Jun 12, 2025


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Stealthy Measurement-Aided Pole-Dynamics Attacks With Nominal Models

Abstract:
When traditional pole-dynamics attacks (TPDAs) are implemented with nominal models, model mismatch between exact and nominal models often affects their stealthiness, or even makes the stealthiness lost. To solve this problem, this article presents a novel stealthy measurement-aided pole-dynamics attacks (MAPDAs) method with model mismatch. First, the limitations of TPDAs using exact models are revealed. Second, to handle the limitations, the proposed MAPDAs method is designed by using an adaptive control strategy, which can keep the stealthiness. Moreover, it is easier to implement as only the measurements are needed in comparison with the existing methods requiring both measurements and control inputs. Third, the performance of the proposed MAPDAs method is explored using convergence of multivariate measurements, and MAPDAs with model mismatch have the same stealthiness and similar destructiveness as TPDAs. Finally, experimental results from a networked inverted pendulum system confirm the feasibility and effectiveness of the proposed method.
More Related Videos
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:19
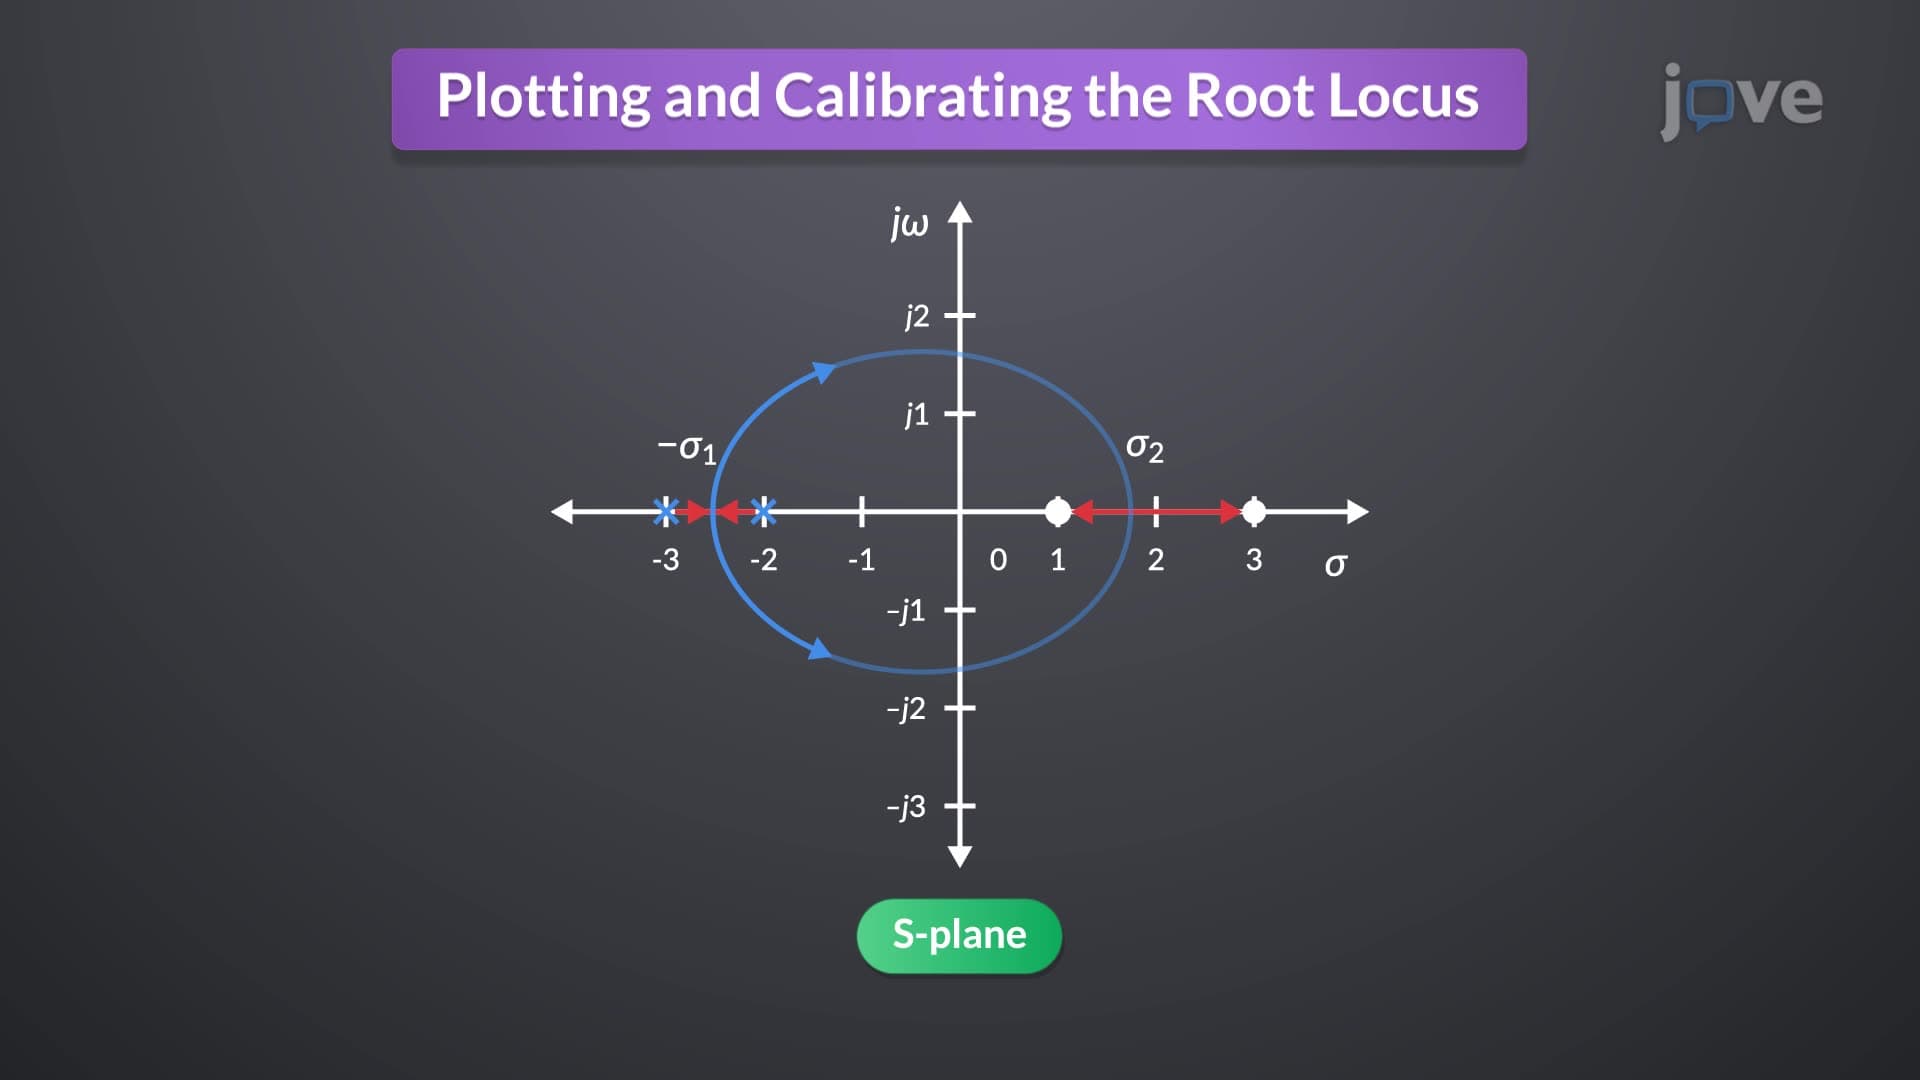
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:30
Typical Model Studies