Related Experiment Video
Updated: Jun 8, 2025
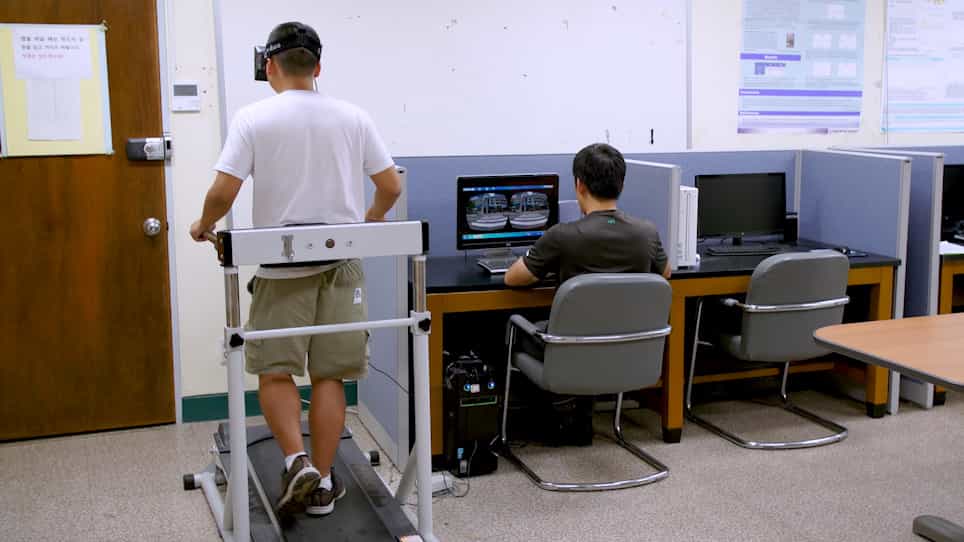

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Pedestrians' intent to cross in a fully autonomous vehicle environment; looking at crossing opportunity, eHMI message
Michal Hochman1, Yisrael Parmet1, Tal Oron-Gilad1
1Department of Industrial Engineering and Management, Ben-Gurion University of the Negev, Beer-Sheva, Israel.

Objectives:
Currently, pedestrians' road-crossing decisions depend on the traffic at the crossing point, crossing opportunities, and circumstantial elements. Longer wait times on the curb and time pressure raise the number of traffic violations among pedestrians. The era of fully autonomous vehicles (FAVs) promises new interactions. External Human-Machine Interfaces (eHMIs) aim to increase the understanding of FAVs' intentions and will influence pedestrians' intent to cross. Yet, how pedestrian behaviors will change in the FAV era remains unclear. Further, there are no good metrics for evaluating the intricate interaction of crossing-related factors.
Methods:
In a laboratory study, sixty participants observed crossing scenarios of a typical one-lane road with 10-12 FAVs driving along, two possible eHMI messages ("Cross!"/"Stop!"), and varying crossing opportunities (safe, risky, and unsafe). Participants had to indicate when they intended to cross the road using a designated button. Half of the participants were induced to feel time pressure. We developed index scores to convey the complexity of such crossing situations from the perspective of a pedestrian and used them to analyze the experimental data.
Results:
In total, 48% of participants' indications were to cross in safe crossing opportunities, 34% risky, and 18% unsafe; 69% were made when the eHMI proposition was "Cross!" and 31% for "Stop!". High, significant, and negative correlations were found for compatible responses, e.g., with a safe crossing gap and an eHMI sign to "Cross!". The opposite was true for incompatibility, e.g., a safe crossing gap and an eHMI sign to "Stop!" or an unsafe crossing gap and an eHMI sign to "Cross!". The time pressure group's median times to cross were shorter, making riskier decisions.
Conclusion:
Our findings reflect a tendency to comply with the eHMI. In more complex scenarios where the crossing opportunity was uncertain or waiting times were longer, we observed that pedestrians were more inclined to follow the eHMI's guidance to cross. These findings suggest that pedestrians may be more likely to follow the eHMI's suggestion to cross than their self-skill, especially under time pressure. Our indices and metrics reflect the intricate interaction aspects of pedestrian behavior with eHMIs.


Related Concept Videos
 01:42
Schemas
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:41
Social Traps