Related Experiment Video
Updated: Jun 4, 2025

Experiments on Ultrasonic Lubrication Using a Piezoelectrically-assisted Tribometer and Optical Profilometer
Published on: September 28, 2015
Identification of Intrinsic Friction and Torque Ripple for a Robotic Joint with Integrated Torque Sensors with
Sri Harsha Turlapati1, Van Pho Nguyen1,2, Juhi Gurnani1
1School of Mechanical and Aerospace Engineering, Nanyang Technological University, Singapore 639798, Singapore.

Abstract:
Although integrated joint torque sensors in robots dispel the need for external force/torque sensors at the wrist to measure interactions, an inherent challenge is that they also measure the robot's intrinsic dynamics. This is especially problematic for delicate robot manipulation tasks, where interaction forces may be comparable to the robot intrinsic dynamics. Therefore, the intrinsic dynamics must first be experimentally estimated under no-load conditions, when the measurement only consists of torques due to the transmission of the robot actuator, before external interactions may be measured. In this work, we propose an approach for identifying and predicting the intrinsic dynamics using linear regression with non-linear radial basis functions. Then, we validate this regression on a wheel-bearing turning task, in which its friction is a measure of quality, and thus must be accurately measured. The results showed that the bearing torque measured by the joint 7 torque sensor was within an RMS error of 11% of the torque measured by the external force/torque sensor. This error is much lower than that before our proposed model in compensating the intrinsic dynamics of the robot arm.
Related Concept Videos
 01:23
Journal Bearings
To better understand the concept of journal bearings, consider a rope winch with dry or...
 01:24
Bearings: Problem Solving
 01:05
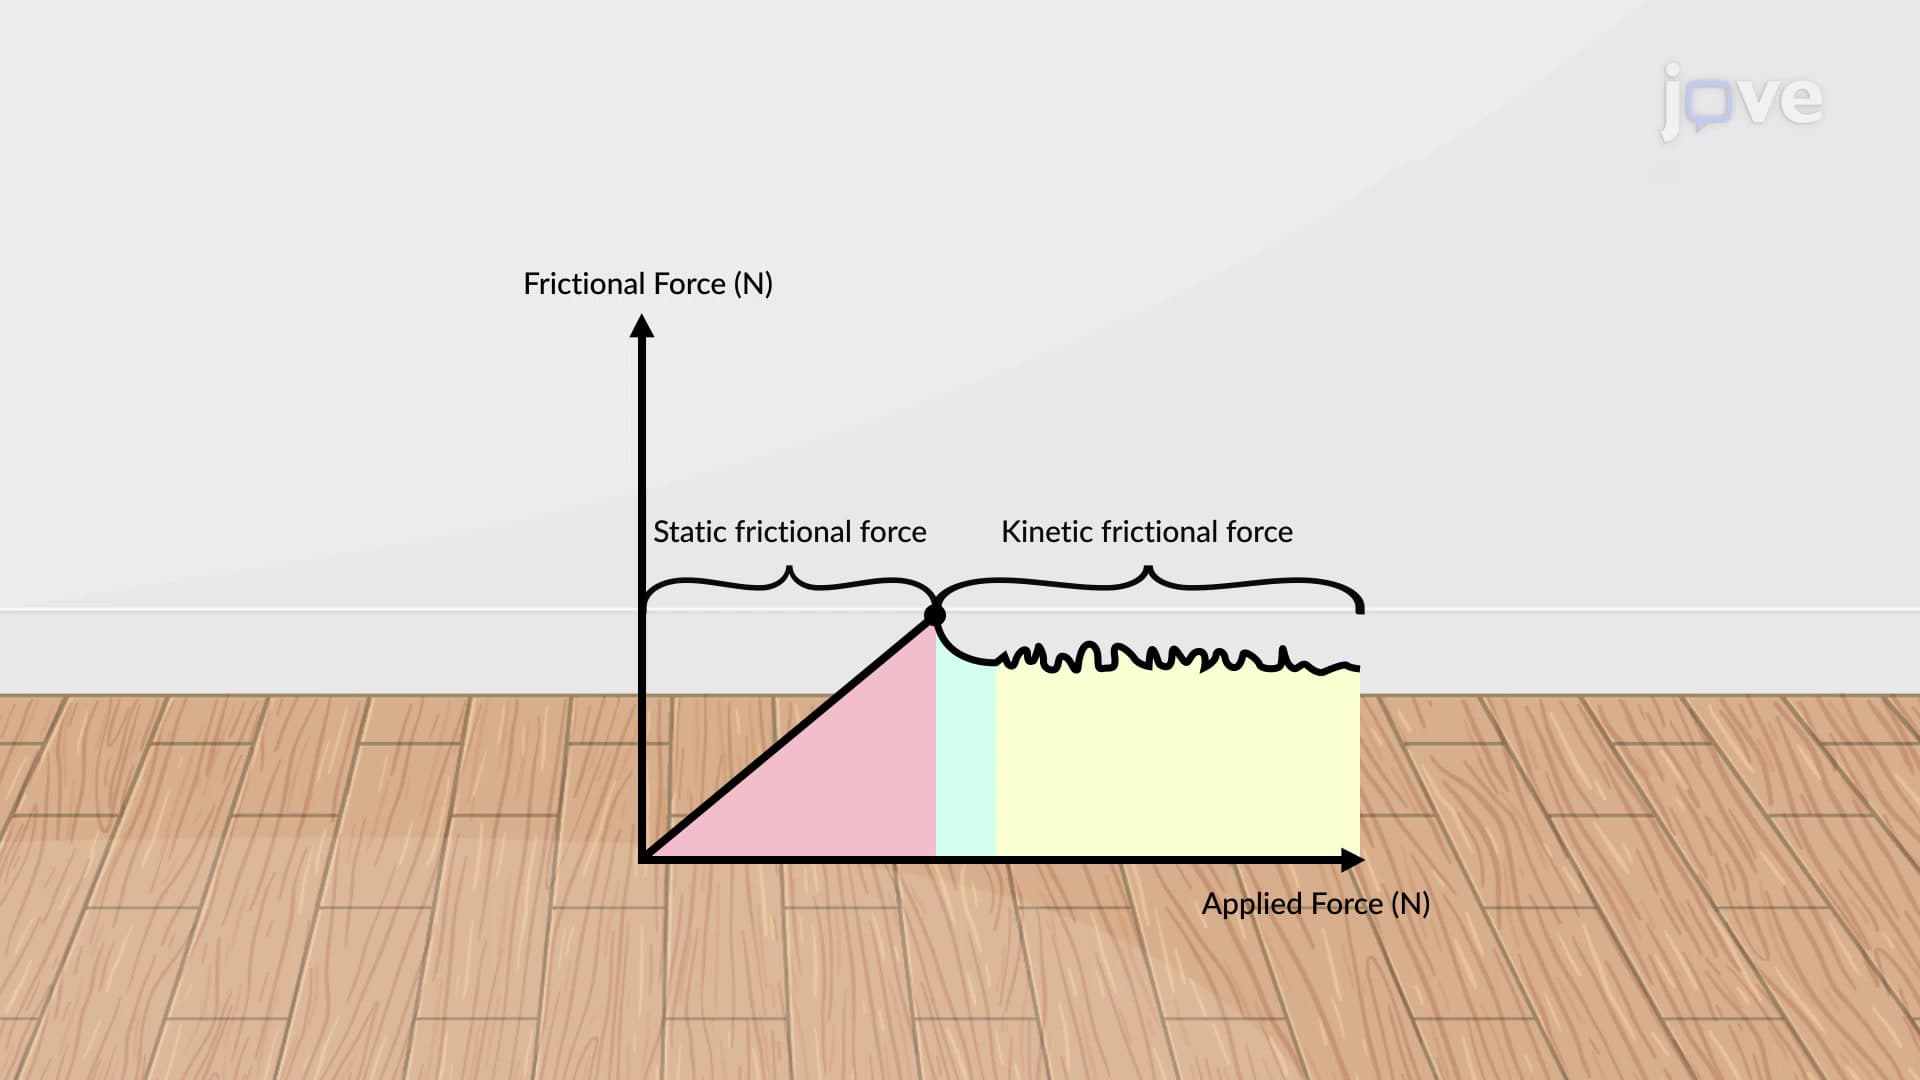
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:15
Torque Free Motion
 01:10
Residual Stresses in Circular Shafts
 01:21
Screw: Problem Solving
To evaluate the...