Related Experiment Video
Updated: Jun 4, 2025
The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
Cooperative regulation based on virtual vector triangles asymptotically compressed in multidimensional space for
1College of Information Science and Engineering, and the National Frontiers Science Center for Industrial Intelligence and Systems Optimization, Northeastern University, Shenyang 110819, China.

Abstract:
This study constructs virtual vector triangles in multidimensional space to address cooperative control issue in time-varying nonlinear multi-agent systems. The distributed adaptive virtual point and its dynamic equations are designed, with this virtual point, the leader, and the follower being respectively defined as the vertices of the virtual vector triangle. The virtual vector edges, decomposed by vectors into coordinate axis components, are organized to form a closed virtual vector triangle by connecting the three vertices with directed vector arrows that are oriented from the tail to the head. Specifically, these virtual vector edges are fictitious vector line segments connecting two vertices and used to compute the relative Euclidean distances between each vertex in multidimensional space. Based on the established virtual vector triangles, which are placed in multidimensional space, and the novel spatial coordinate transformation method, the cooperative regulation problem of the time-varying nonlinear multi-agent system is transformed into a mathematical problem of compressing the virtual vector triangles with exponential magnitude. The created distributed compression control protocol asymptotically shrinks the magnitude of the virtual vector triangles by exponential oscillatory decay towards the same dynamic point aligned with the motion trajectory of the leader or the leader, where the states of the time-varying nonlinear multi-agent systems achieve asymptotic convergence consensus. The reliable stability of the asymptotic compression convergence process of the virtual vector triangles was verified by establishing a Lyapunov function and relying on the Lyapunov stability theory. Finally, the example of time-varying nonlinear multi-agent systems are presented for simulation experiments to further validate the effectiveness and feasibility of the proposed control protocol in addressing the cooperative regulation issue.

Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:09
Turbulent Flow: Problem Solving
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures...
 01:23
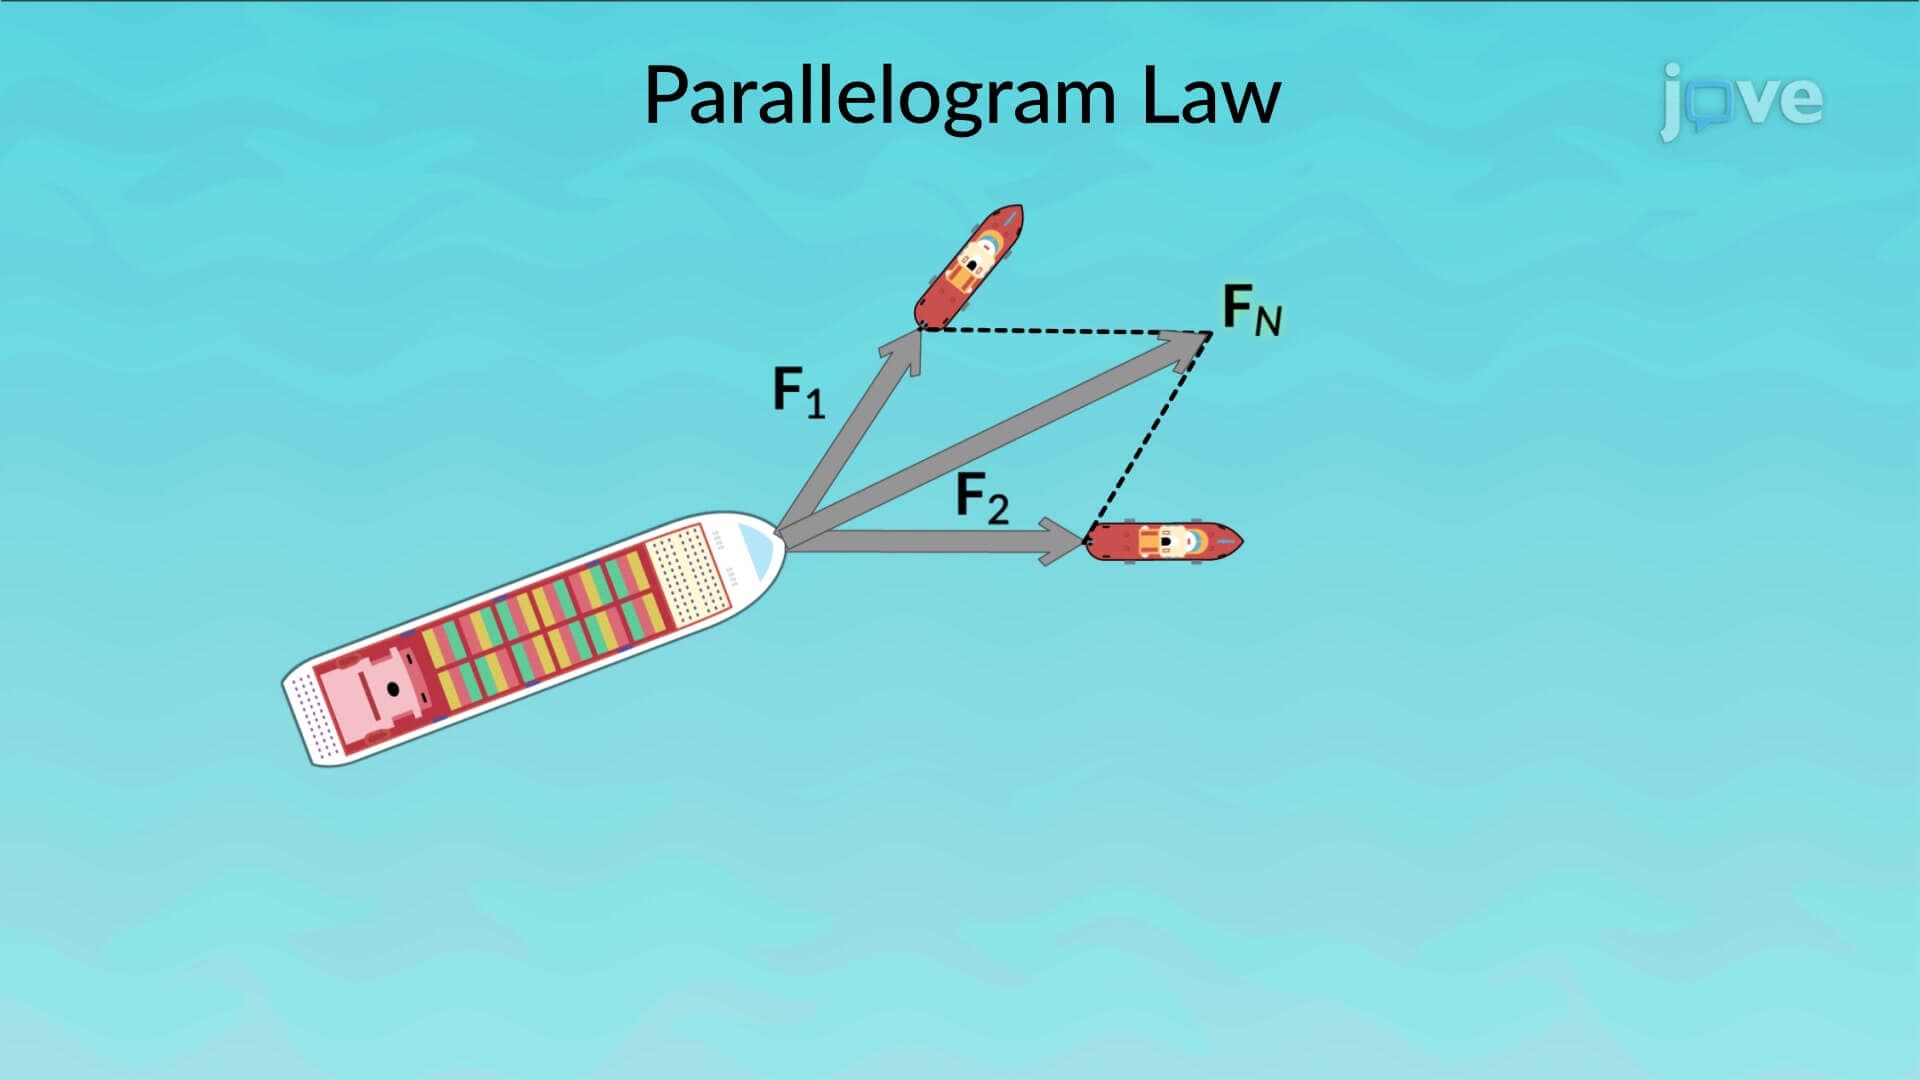
Vector Addition of Forces
To understand the concept of vector addition, consider the scenario of a ship being pulled by two small tugboats. The two forces, F1 and F2, act concurrently on the ship in different directions. The parallelogram law can be used to calculate the net force...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...