Related Experiment Video
Updated: Jun 4, 2025
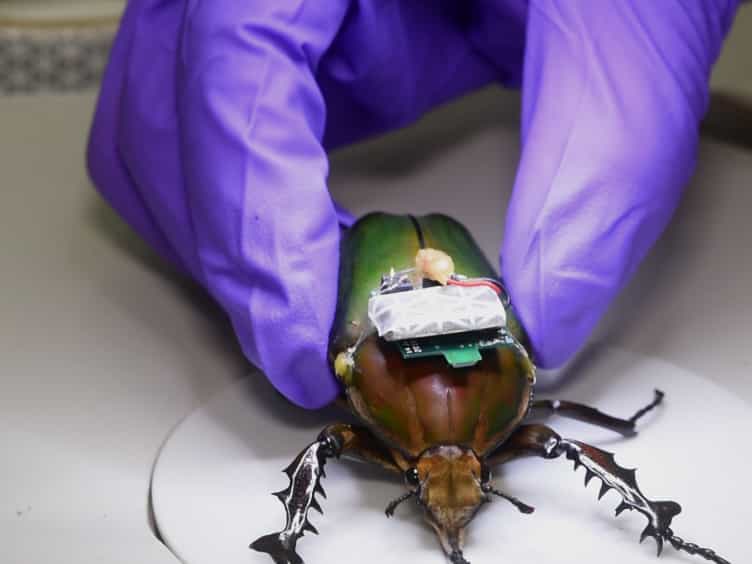
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Visualized neural network-based vibration control for pigeon-like flexible flapping wings
Hejia Gao1, Jinxiang Zhu2, Changyin Sun3
1School of Artificial Intelligence, Anhui University, Hefei 230601, China; Anhui Provincial Key Laboratory of Security Artificial Intelligence, Anhui University, Anhui 230601, China; Engineering Research Center of Autonomous Unmanned System Technology, Ministry of Education, Anhui 230601, China.

Abstract:
This study investigates pigeon-like flexible flapping wings, which are known for their low energy consumption, high flexibility, and lightweight design. However, such flexible flapping wing systems are prone to deformation and vibration during flight, leading to performance degradation. It is thus necessary to design a control method to effectively manage the vibration of flexible wings. This paper proposes an improved rigid finite element method (IRFE) to develop a dynamic visualization model of flexible flapping wings. Subsequently, an adaptive vibration controller was designed based on non-singular terminal sliding mode (NTSM) control and fuzzy neural network (FNN) in order to effectively solve the problems of system uncertainty and actuator failure. With the proposed control, stability of the closed loop system is achieved in the context of Lyapunov's stability theory. At last, a joint simulation using MapleSim and MATLAB/Simulink was conducted to verify the effectiveness and robustness of the proposed controller in terms of trajectory tracking and vibration suppression. The obtained results have demonstrated great practical value of the proposed method in both military (low-altitude reconnaissance, urban operations, and accurate delivery, etc.) and civil (field research, monitoring, and relief for disasters, etc.) applications.
Related Concept Videos
 01:19
PID Controller
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...