Bipedal static postural stability in children with achondroplasia compared to typically developed children in the age range of 9-12 years - A pilot study
Related Experiment Video
Updated: May 6, 2026
Computerized Dynamic Posturography for Postural Control Assessment in Patients with Intermittent Claudication
Published on: December 11, 2013
M Hergenröther1, K Palm2, K Mohnike2
1Sports Engineering / Movement Science Departement, Faculty for Human Sciences, Otto-von-Guericke University, Magdeburg, Germany.

Background:
Postural stability is a key factor in maintaining an upright standing position. Children with average height (CAH) have elaborate general postural stability up to the age of seven years. Children with achondroplasia (ACH) face body disproportions like shorter arms and legs, bowing of the legs as well as hyperlordosis and hypokyphosis in the spine. These misalignments might affect the postural stability of children with achondroplasia. Therefore, this study aims to investigate if there are differences between children with ACH and CAH in four different bipedal static balance tasks.
Methods:
23 children (11 ACH & 12 CAH) participated in this study. Every subject performed four static balance tasks: bipedal standing on the ground (eyes open/closed) and bipedal standing on a foam pad (eyes open/closed). All trials were recorded on a force plate (AMTI) with 1000 Hz and a duration of 30 seconds for each condition. Parameters of interest are the length of CoP (mm), surface area 95 (mm2) as well as three defined ranges of frequency (low: 0.02 - 0.1 Hz, medium: 0.1 - 1 Hz, and high: 1 - 10 Hz) for anterior-posterior (AP) and mediolateral direction (ML). A Mann-Whitney U test was used to investigate the parameters length of CoP (AP & ML) and surface area 95 %. One-way ANOVA was used for the area under the curve parameter for each frequency range.
Results:
Nonsignificant differences were found for all parameters. However, non-significant medium and strong effect sizes were detected for certain parameters of the frequency analysis.
Significance:
Understanding strategies to maintain postural stability for ACH and CAH during a bipedal stance at a deeper level using frequency analysis helps to detect in which way disturbances might occur and how both cohorts react to those. Knowing the challenges of maintaining postural stability can help to develop therapeutic interventions to reduce disturbances.
More Related Videos
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
 07:52
Evaluating Postural Control and Lower-extremity Muscle Activation in Individuals with Chronic Ankle Instability
Published on: September 18, 2020
Related Concept Videos
 01:05
Static Equilibrium - I
 01:21
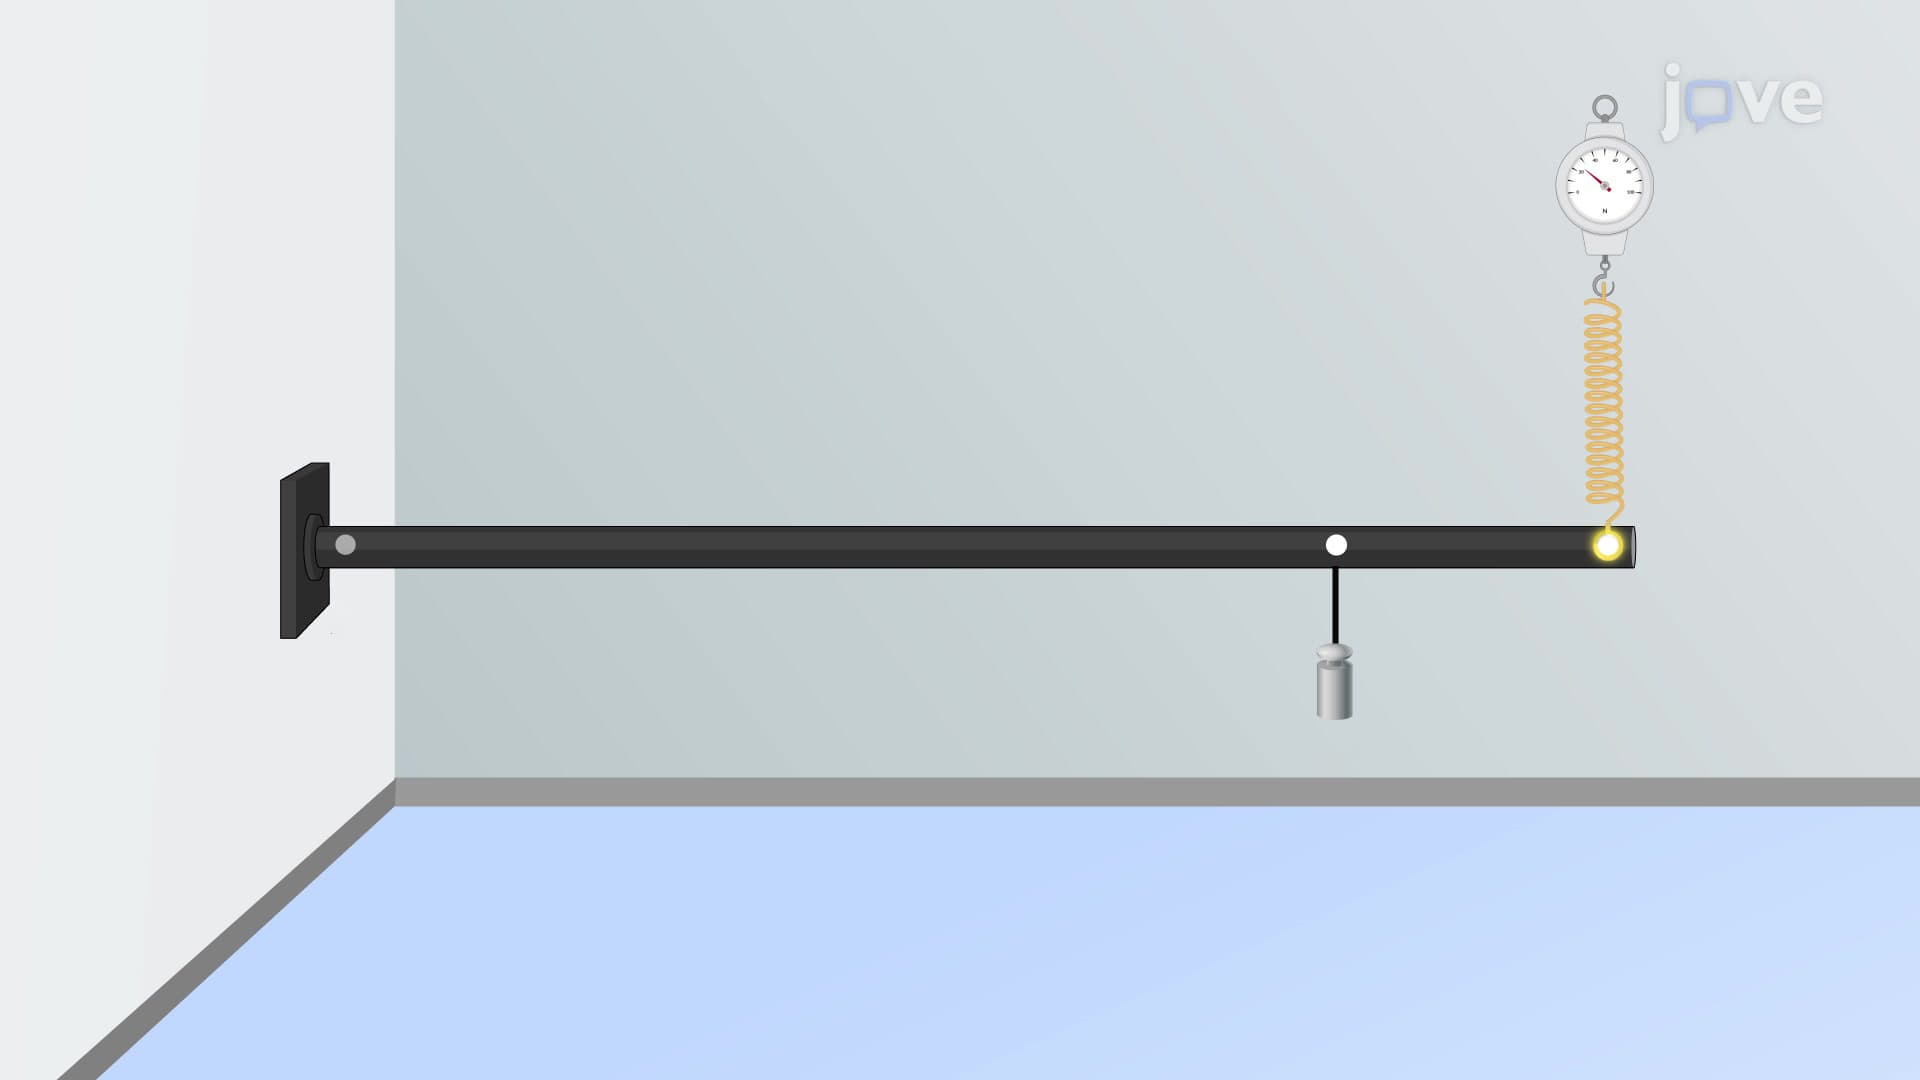
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:28
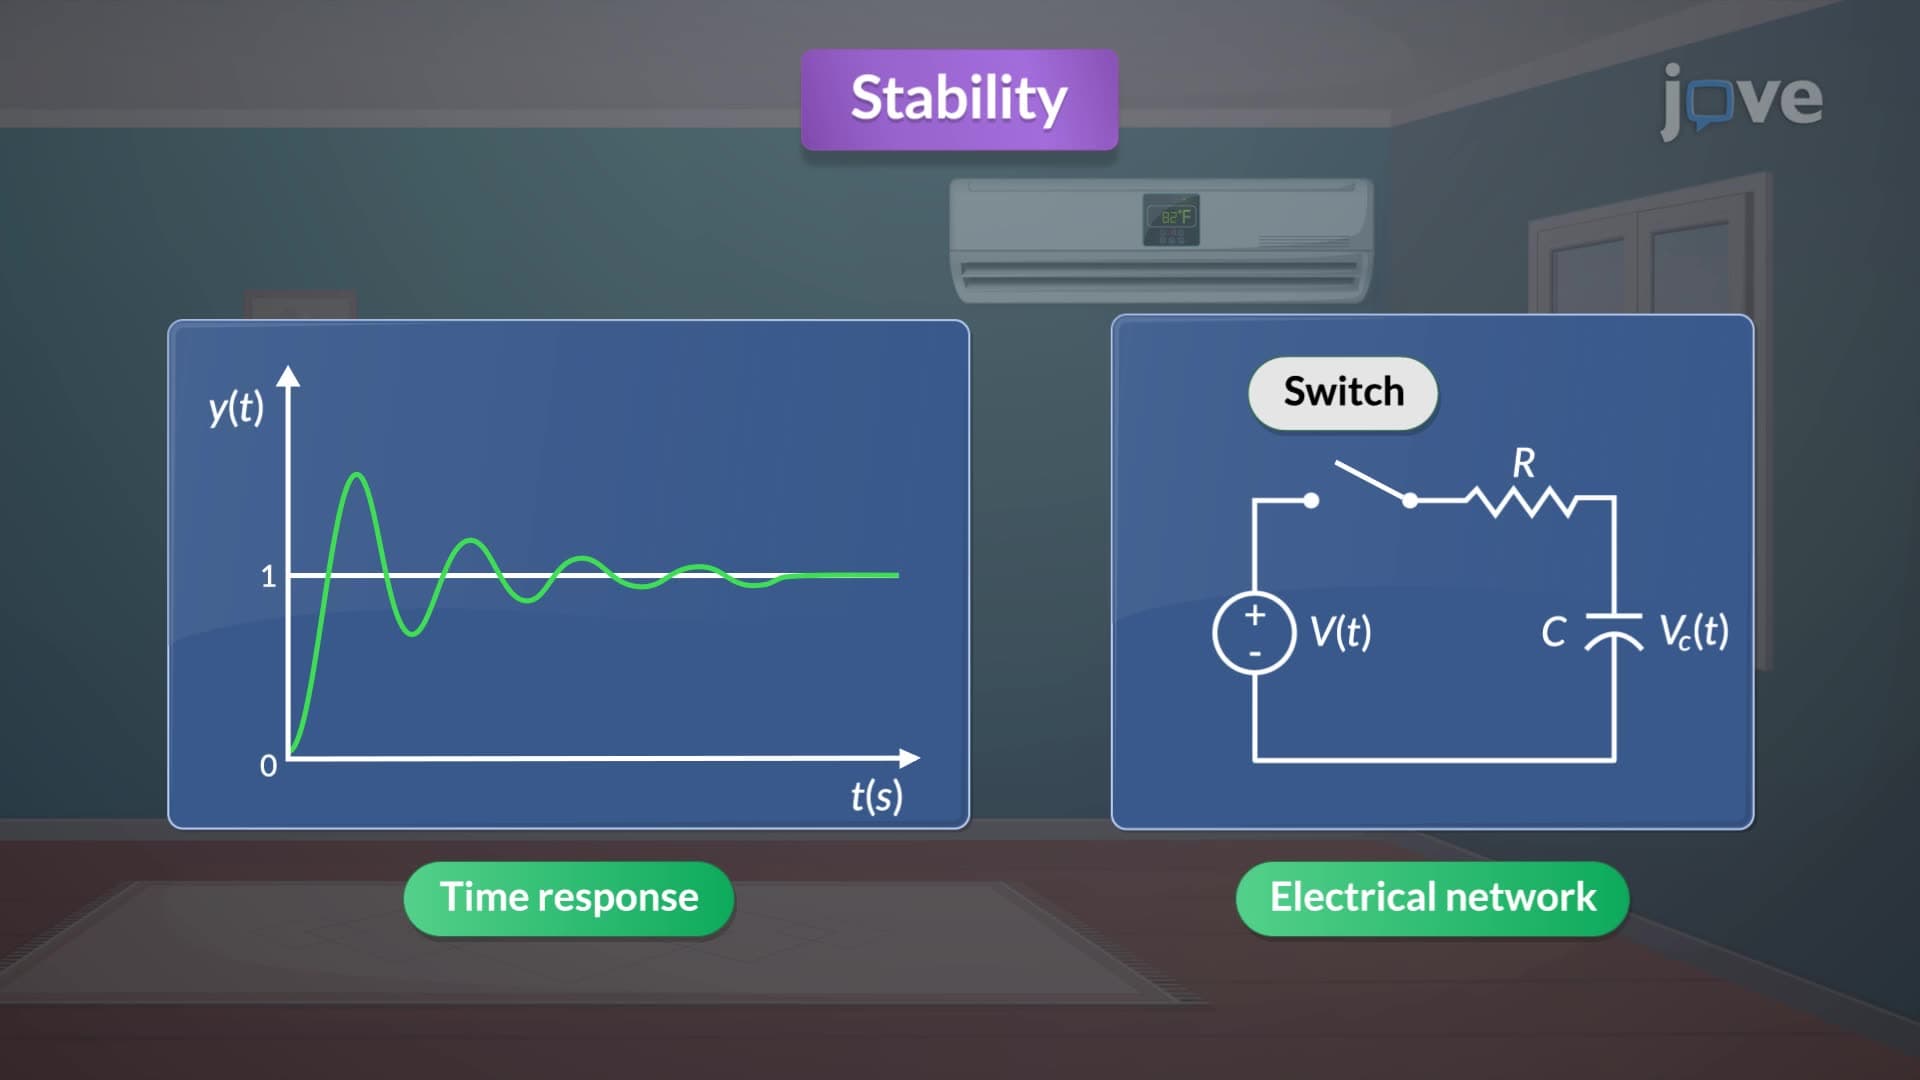
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...