Related Experiment Video
Updated: May 28, 2025
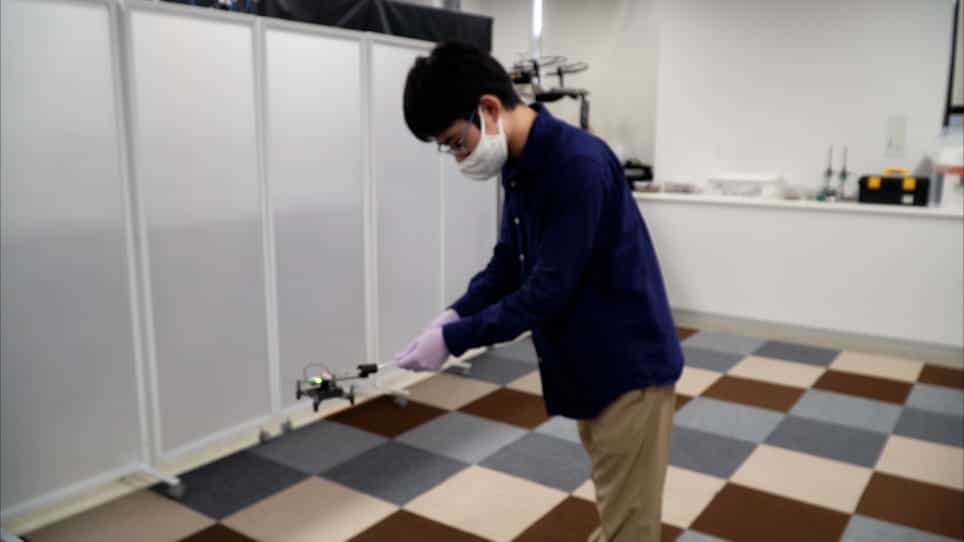
Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
Performance analysis of hybrid optimization approach for UAV path planning control using FOPID-TID controller and
Noorulden Basil1, Abdullah Fadhil Mohammed2, Bayan Mahdi Sabbar3
1Department of Electrical Engineering, College of Engineering, Mustansiriyah University, Baghdad, Iraq. noorulden@uomustansiriyah.edu.iq.

Abstract:
In this study, we present a comparative analysis of various trajectory optimization algorithms for Unmanned Aerial Vehicles (UAVs) navigating complex environments. The performance of the proposed FOPID-TID based HAOAROA (Hybrid Archimedes Optimization Algorithm-Rider Optimization Algorithm) is evaluated against traditional methods such as A*, JPS, Bezier, and L-BSGF algorithms. The FOPID-TID based HAOAROA approach integrates the advantages of fractional-order control with hybrid optimization techniques to improve UAV trajectory planning. Simulation results indicate that the proposed method carries significantly better performance than the traditional algorithms with respect to trajectory length, smoothness, and overall stability. Remarkably, the FOPID-TID based HAOAROA yields a 10% reduced trajectory length that is smoother than traditional methods while also being more computationally efficient. By using fractional-order parameters, the dynamic response becomes better and better in more challenging environments. This shows that disturbance rejection and control precision using the FOPID-TID based HAOAROA are much superior to the original two subroutines. The applications presented in this study allow future growth in UAV control system improvements and provide proof of concept of hybrid optimization in improving the performance of UAVs in dynamic, complex environments.


Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...