Virtual torque control combining with modal decoupling research for hydraulic-driven lower limb exoskeleton robot
Related Experiment Video
Updated: May 27, 2025
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Jinsong Zhao1, Huidong Hou2, Xianwei Niu2
1School of Mechanical Engineering, Yanshan University, Qinhuangdao, 066004, China; Hebei Provincial Key Laboratory of Heavy Machinery Fluid Power Transmission and Control, Yanshan University, Qinhuangdao, 066004, China; Key Laboratory of Advanced Forging & Stamping Technology and Science (Yanshan University), Ministry of Education of China, Qinhuangdao, 066004, China; State Key Laboratory of Crane Technology, Yanshan University, Qinhuangdao, 066004, China.

Abstract:
The hydraulic-driven lower limb exoskeleton robot (HDLLER) can provide excellent assistance during human walking. However, complex torque coupling disturbances exist between each joint, negatively impacting the precise torque tracking of each joint channel of the robot. To address the coupling force disturbances between HDLLER joints and the human-robot interactions, this paper proposes a virtual torque control (VTC) strategy based on modal decoupling. Specifically, a human-robot coupled dynamic model of the HDLLER considering human motion disturbances is first established. Then, based on vibration theory, a modal space decoupling approach is proposed to transform the system's mass and stiffness matrices into diagonal matrices, creating two independent control channels. Furthermore, a VTC strategy is introduced to compensate for disturbances caused by human motion and the residual terms after modal decoupling, thereby enhancing the HDLLER's performance. Finally, to handle parameter variations during modal decoupling and inaccuracies in model identification, the H∞ theory is introduced to optimize the proposed VTC, effectively reducing the control strategy's dependence on model accuracy and improving system robustness. The effectiveness of the proposed method is verified through a series of comparative experiments.

Related Concept Videos
 01:15
Torque Free Motion
 01:19
Net Torque Calculations
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:13
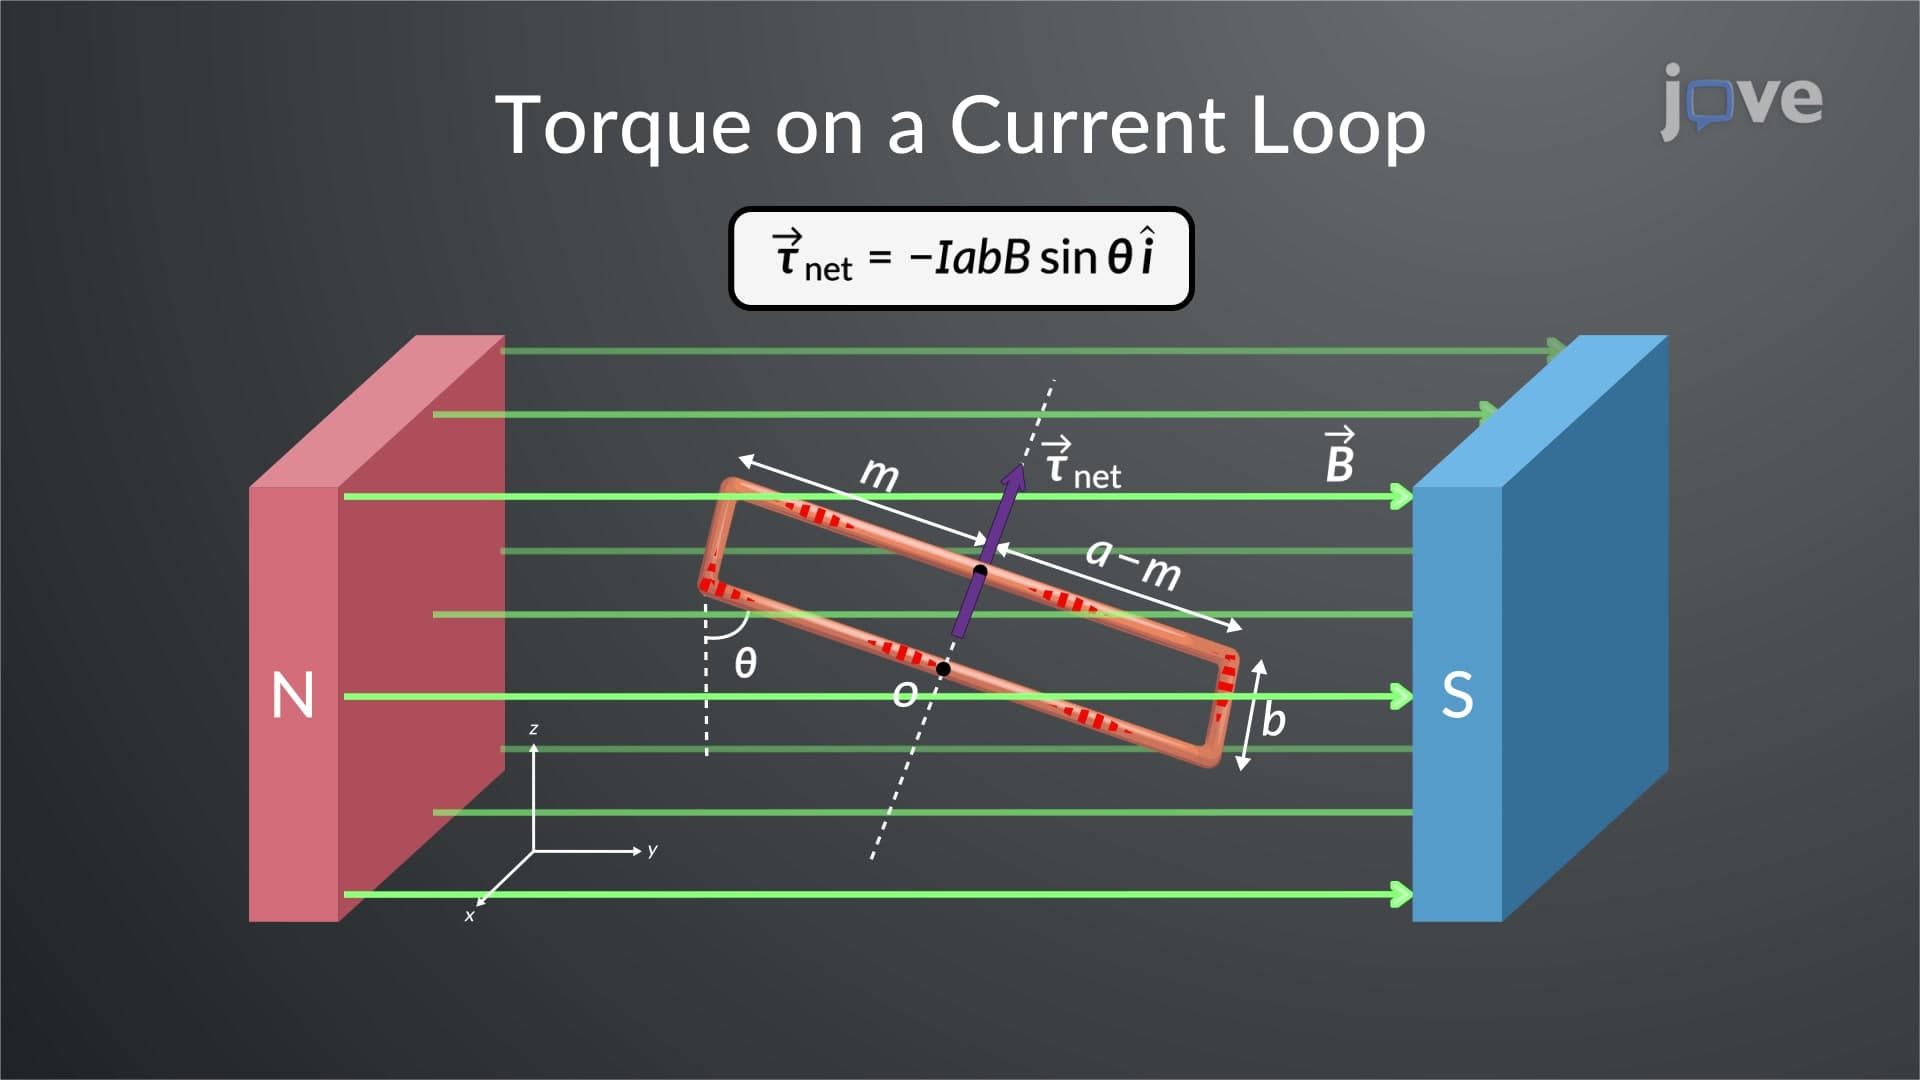
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 00:46
Motor Units