Admissible consensus tracking control for nonlinear singular multi-agent systems via sampled-data event-triggered mechanisms
Related Experiment Video
Updated: May 26, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
1Automation Division, School of Optical-Electrical and Computer Engineering, University of Shanghai for Science and Technology, Shanghai 200093, China.

Abstract:
This paper discusses the admissible consensus tracking problem for nonlinear singular multi-agent systems under sampled-data event-triggered mechanisms, where the nonlinear dynamics are unknown. In the sampled-data framework, both static and dynamic event-triggered mechanisms are designed based on the observers, and the dynamic event-triggered mechanism has superior performance. Moreover, in order to eliminate the effect of bounded consensus caused by the double estimation problem, this study proposes a distributed adaptive event-triggered control protocol. This protocol is designed to establish sufficient conditions for achieving admissible consensus tracking of singular multi-agent systems. Finally, the theoretical results are verified by three numerical examples.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:10
Control Systems
At the heart...
 01:11
Sampling Continuous Time Signal
In the...
 01:13
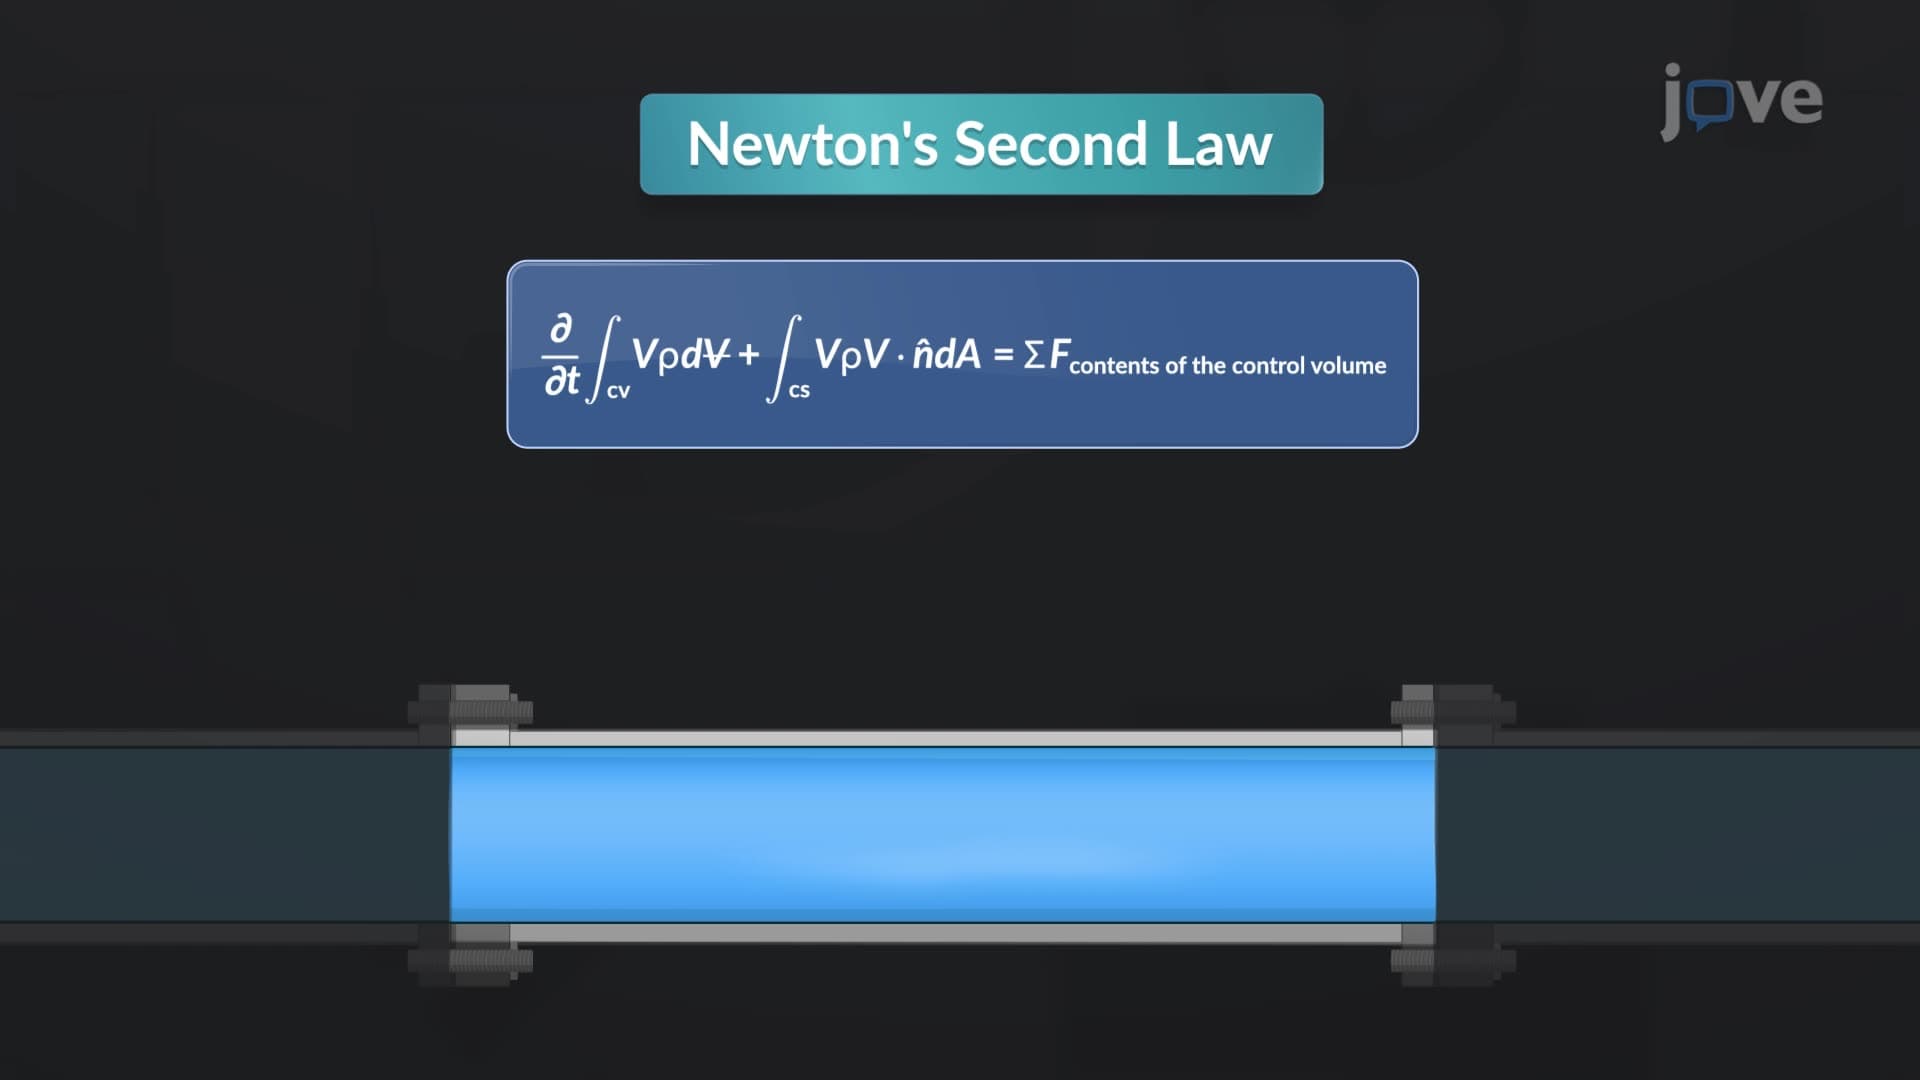
Linear Momentum in Control Volume
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...