Switching dynamic event-triggered disturbance rejection control for uncertain Lipschitz nonlinear system using recursive observers

1Key Laboratory of Smart Manufacturing in Energy Chemical Process (Ministry of Education), East China University of Science and Technology, Shanghai 200237, China.

Abstract:
This paper investigates the event-triggered disturbance rejection control problem for a class of uncertain Lipschitz nonlinear systems with time-varying disturbances. The design process to address this problem involves the construction of a state and disturbance joint observer, along with the design of an event-triggered controller that incorporates a designable minimum inter-event time. To design the joint observer, time-varying disturbances are initially transformed into multiple intermediate variables by employing a linear combination of system states and disturbance derivatives. Subsequently, the recursive observers are constructed to obtain intermediate variable estimations, while the recursive mechanism is utilized to compensate for the extra derivative term arising from disturbance transformation. Then, states and disturbance estimations are used to develop the event-triggered disturbance rejection controller. The event-triggered protocol includes a mandatory resting interval and a dynamic trigger variable that monotonically increases during the resting interval, ensuring a guaranteed minimum inter-event time while also decreasing the trigger frequency. Finally, we provide numerical examples to showcase the effectiveness of the proposed method. Simulation results show that the proposed method is able to reduce the steady-state error by 59.6% and extend the minimum trigger interval by at least 2.44 times compared to existing methods.


Related Concept Videos
 01:18
Second Order systems II
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
First Order Systems
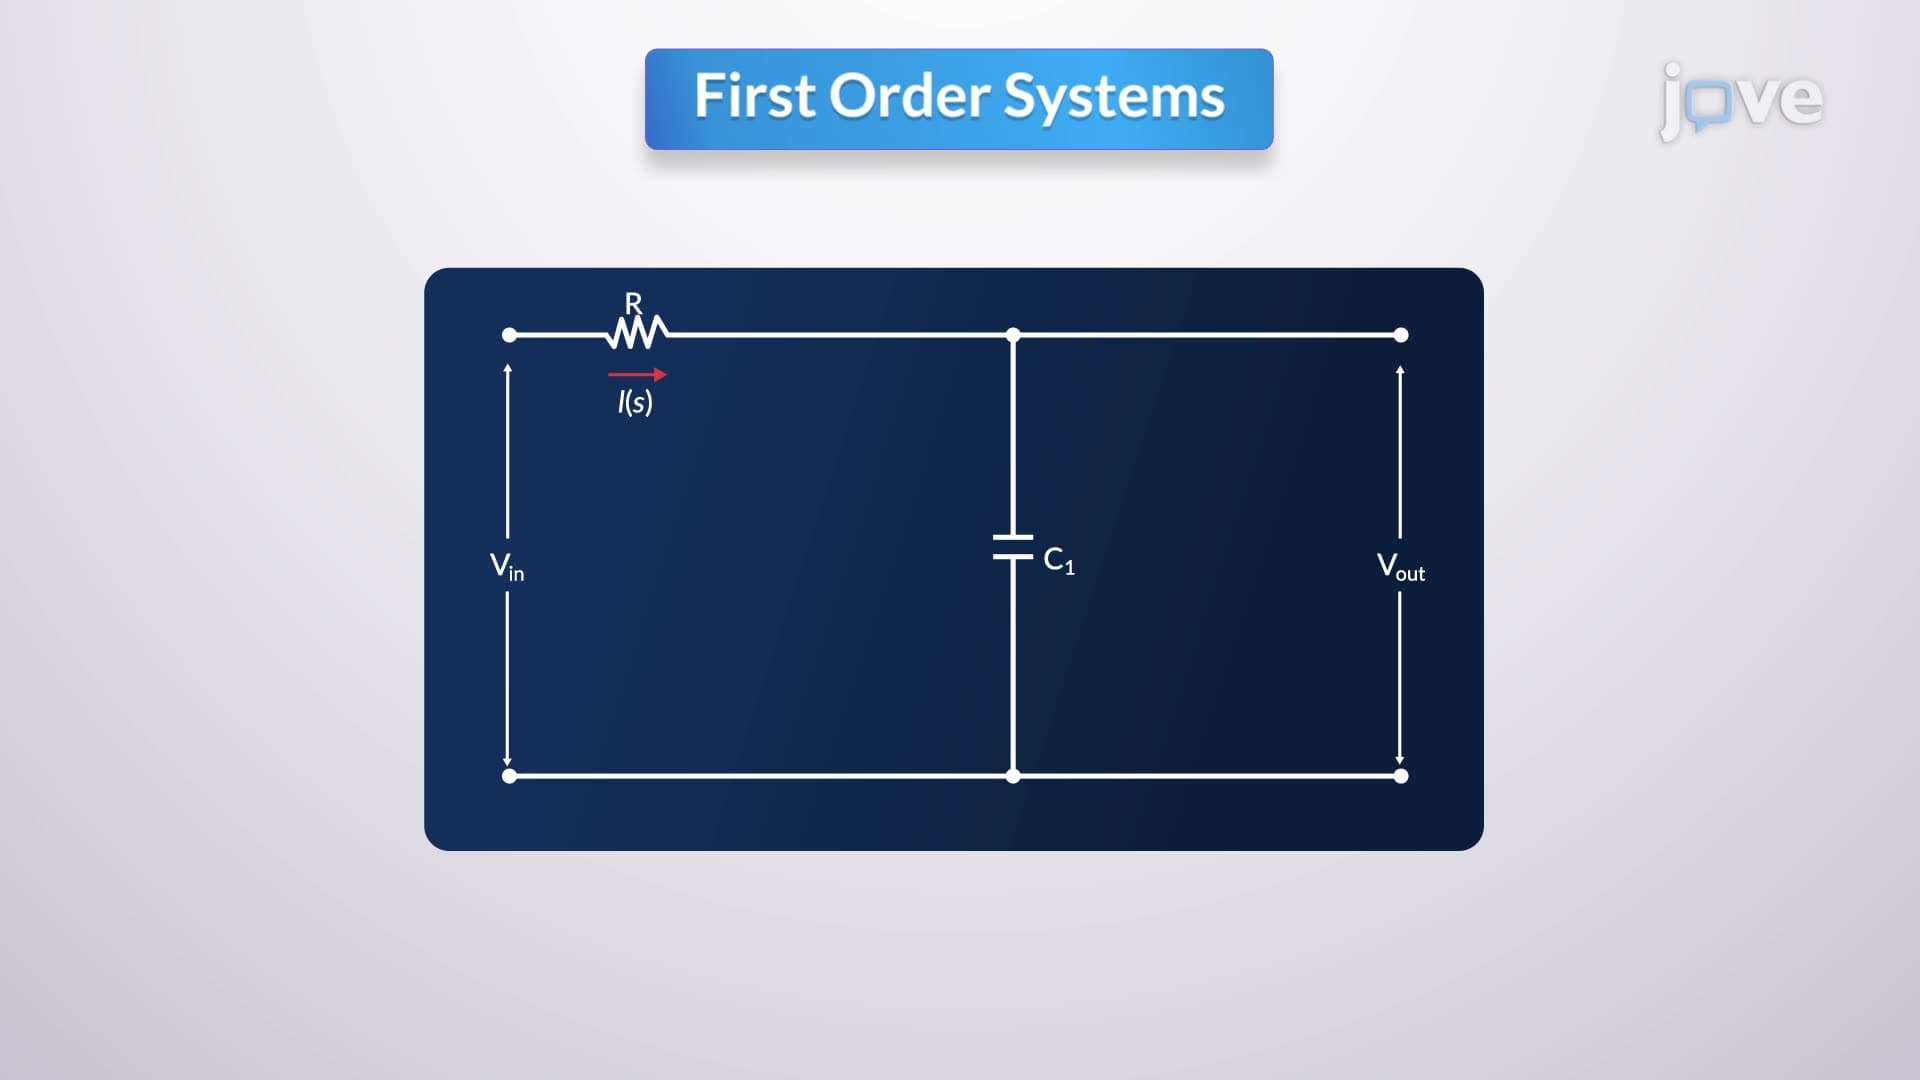
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...