Related Experiment Video
Updated: May 2, 2026
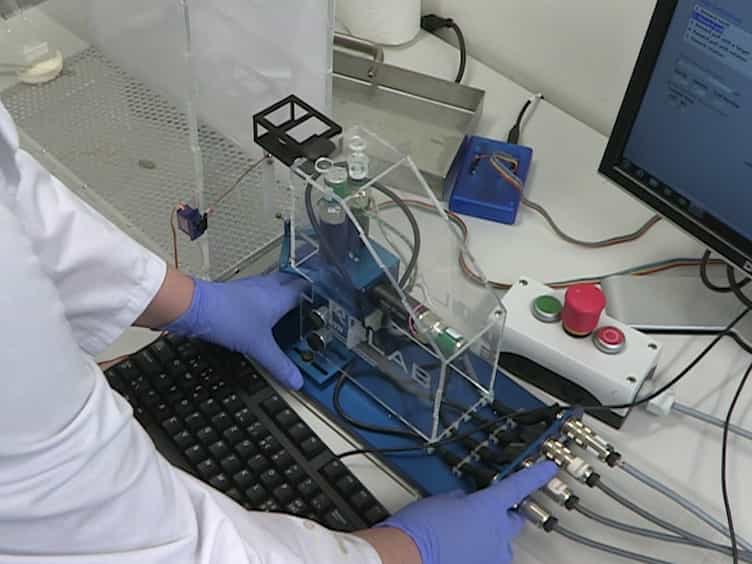
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
A mini-review on mobile manipulators with Variable Autonomy
Cesar Alan Contreras1, Alireza Rastegarpanah1,2, Manolis Chiou3
1School of Metallurgy and Materials, The University of Birmingham, Birmingham, United Kingdom.

Abstract:
This paper presents a mini-review of the current state of research in mobile manipulators with variable levels of autonomy, emphasizing their associated challenges and application environments. The need for mobile manipulators in different environments, especially hazardous ones such as decommissioning and search and rescue, is evident due to the unique challenges and risks each presents. Many systems deployed in these environments are not fully autonomous, requiring human-robot teaming to ensure safe and reliable operations under uncertainties. Through this analysis, we identify gaps and challenges in the literature on Variable Autonomy, including cognitive workload and communication delays, and propose future directions, including whole-body Variable Autonomy for mobile manipulators, virtual reality frameworks, and large language models to reduce operators' complexity and cognitive load in some challenging and uncertain scenarios.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:18
Hierarchy of Motor Control
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...