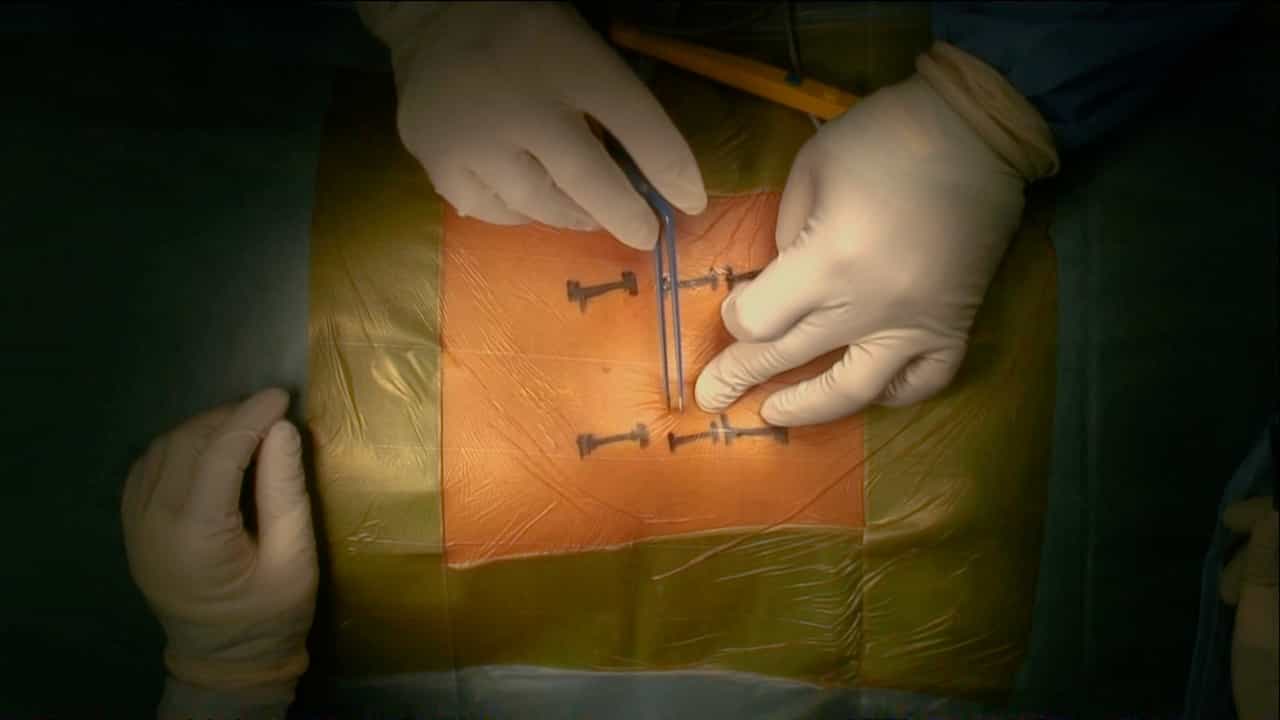
Related Experiment Video
Updated: May 15, 2025
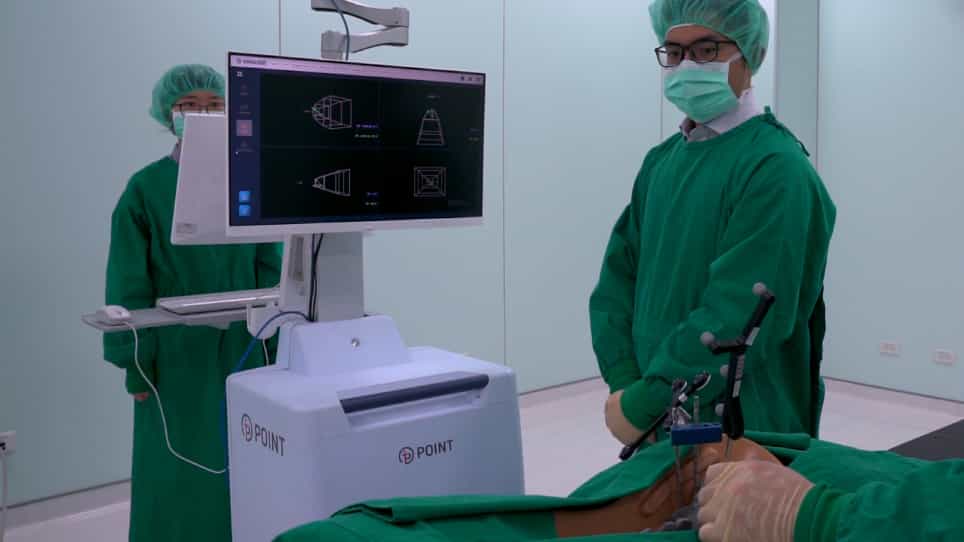
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
The Role of Robot-Assisted Technique in Treating Adult Degenerative Scoliosis with Circumferential Minimal Invasive
Qiang Zhang1, Zhe Chen1, Yazhou Lin1
1Department of Orthopedics, Ruijin Hospital, Shanghai Jiaotong University School of Medicine, Shanghai, 200025, People's Republic of China.

Study Design:
Retrospective chart review.
Objective:
This study aims to investigate the application of robots in treating adult degenerative scoliosis (ADS) with circumferential minimal invasive surgery (cMIS).
Background:
The cMIS is useful but faces a lot of challenges in correcting ADS. One of the most important challenges is the difficulty in screw placement. Robot-assisted technique demonstrates lots of advantages but the data about its application in treating ADS is limited in literatures.
Methods:
A total of 51 cases diagnosed with ADS were retrospectively analyzed. All patients underwent cMIS technique with staged surgeries (OLIF and PPS fixation). Group A enrolled 21 patients and performed robot-assisted technique. Group B enrolled 30 patients and performed fluoroscopy guided technique. Clinical outcomes like the operation time, radiation exposure, pressure curve and post-operation VAS score were recorded. 3D-CT scan was also performed to evaluate the accuracy of the screws.
Results:
The average preparation time were much higher in group A (23.4 ± 2.8 vs 3.1 ± 1.0 min, p < 0.0001). But the total operation time was similar (62.7 ± 12.5 vs 55.7 ± 20.6 min, p = 0.174). The average fluoroscopic scan number were 9.4 ± 1.7 in group A, much lower than that of group A (27.7 ±5.9, p < 0.001). No statistical difference was found with the VAS scale between the groups (p = 0.631). No matter considers only screws of grade A as perfect screws (81.5% vs 73.8%) or considers both grade A and B as acceptable screws (93.8% vs 87.7%), group A demonstrated significant higher screw accuracy (p = 0.038, p = 0.018, respectively). Also, the robots demonstrated significant less facet joint violence (p < 0.0001), larger inward tilt angle (p < 0.0001), and longer screw length (p = 0.0008).
Conclusion:
The robot-assisted technique demonstrated significant advantages like higher pedicle screw accuracy, better trajectory, less radiation exposure, but similar operation time compared with fluoroscopy guided technique in treating ADS with CMIS.