An active resisting disturbance control method for high-speed maglev train with weak model dependence
Related Experiment Video
Updated: Jun 27, 2026

Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 16, 2014
Yang Yang1, Huang Cuicui1, Dai Chunhui1
1College of Intelligence Science and Technology, National University of Defense Technology, Changsha, 410073, China.

Abstract:
With the speed of high-speed maglev increasing, external disturbances will be further aggravated, leading to a deterioration in the stability and dynamic performance of the electromagnetic levitation (EML) system. Improving the disturbance rejection capability of EML systems is crucial for ensuring safe and stable train operation. To address this challenge, this paper proposes an active resisting disturbance control method with weak model dependence, combining model reference adaptive control (MRAC) and active disturbance rejection control (ADRC). First, MRAC is used to approximate the plant to the reference model to avoid problems caused by model uncertainty. Then, a linear extended state observer (LESO) is constructed based on nominal model parameters to estimate and compensate for disturbances. Additionally, a tracking differentiator (TD) is incorporated to extract system states for constructing the MRAC law. The Lyapunov stability theory is used to prove that the EML system can achieve stability under the proposed control law. Finally, the simulation experiment and physical verification experiment are designed. The experimental results show that the proposed control method outperforms PID, SMC, and ADRC in disturbance rejection and its control performance is insensitive to the changes in model parameters and equilibrium point.
More Related Videos
 10:52
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:25
Magnetic Force On A Current-Carrying Conductor
Consider a compass placed near a current-carrying wire. The wire experiences a force that aligns the needle of the compass tangentially around the wire. Thus, the current-carrying wire produces concentric circular loops of magnetic field. The magnetic field generated by a wire can be...
 01:23
Magnetic Field due to Moving Charges
Consider a point charge moving with a constant velocity. Like the electric field, the magnetic field at any point is directly proportional to the magnitude of the charge and inversely proportional to the square of the distance between the source point and the field point. However, unlike the electric field, the magnetic field is always perpendicular to the plane containing the line...
 01:24
Potential Due to a Magnetized Object
The vector...
 01:28
Magnetostatic Boundary Conditions
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:30
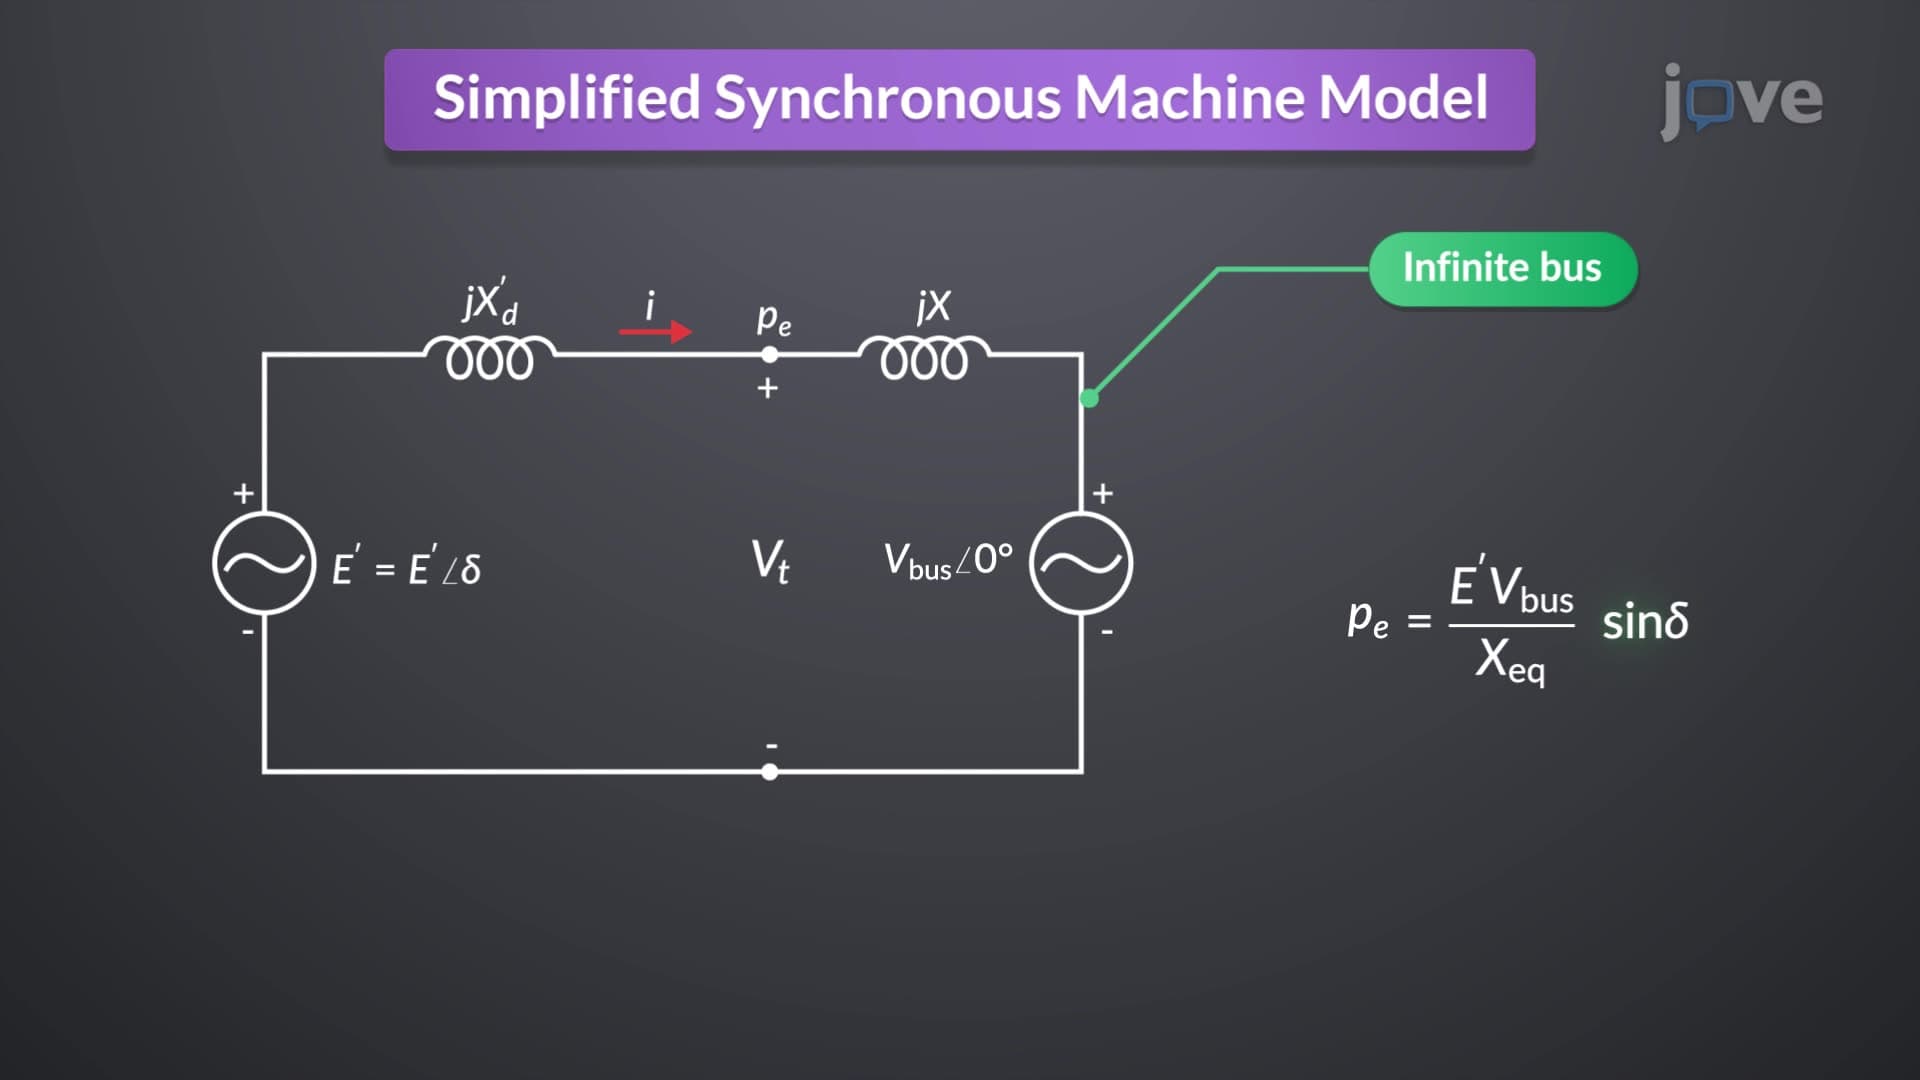
Simplified Synchronous Machine Model
In this model, each generator is connected to a...