Related Experiment Video
Updated: Sep 20, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Inverse reinforcement learning for discrete-time linear systems based on inverse optimal control
Jiashun Huang1, Dengguo Xu1, Yahui Li1
1School of Automation, Guangxi University of Science and Technology, Liuzhou 54500, China.

Abstract:
This paper mainly deals with inverse reinforcement learning (IRL) for discrete-time linear time-invariant systems. Based on input and state measurement data from expert agent, several algorithms are proposed to reconstruct cost function in optimal control problem. The algorithms mainly consist of three steps, namely updating control gain via algebraic Riccati equation (ARE), gradient descent to correct cost matrix, and updating weight matrix based on inverse optimal control (IOC). First, by reformulating gain formula of optimal control in the learner system, we present a model-based IRL algorithm. When the system model is fully known, the cost function can be iteratively computed. Then, we develop a partially model-free IRL framework for reconstructing the cost function by introducing auxiliary control inputs and decomposing the algorithm into outer and inner loop. Therefore, in the case where the input matrix is unknown, weight matrix in the cost function is reconstructed. Moreover, the convergence of the algorithms and the stability of corresponding closed-loop system have been demonstrated. Finally, simulations verify the effectiveness of the proposed IRL algorithms.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
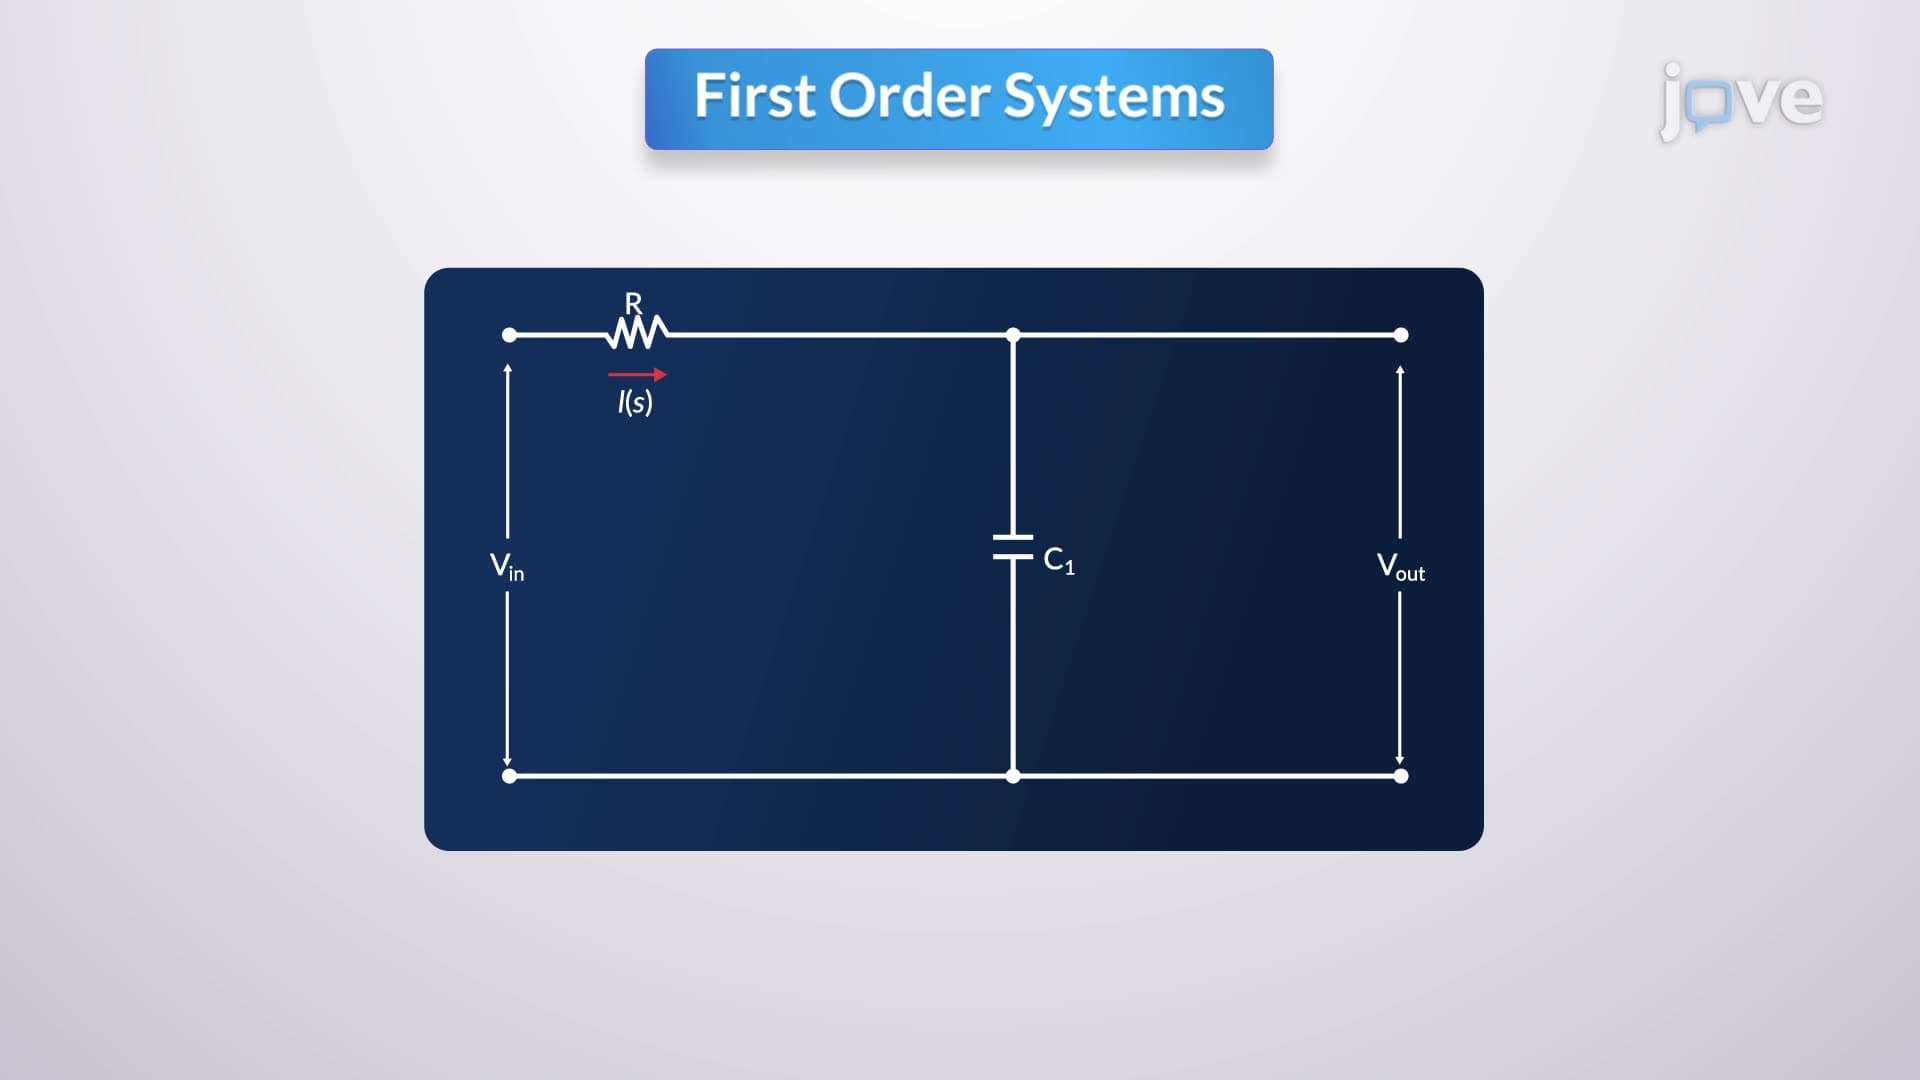
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
PI Controller: Design