Related Experiment Video
Updated: Sep 18, 2025


Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
PolarFusion: A multi-modal fusion algorithm for 3D object detection based on polar coordinates
Peicheng Shi1, Runshuai Ge1, Xinlong Dong1
1School of Mechanical and Automotive Engineering, Anhui Polytechnic University, Wuhu, 241000, Anhui, China.

Abstract:
Existing 3D object detection algorithms that fuse multi-modal sensor information typically operate in Cartesian coordinates, which can lead to asymmetrical feature information and uneven attention across multiple views. To address this, we propose PolarFusion, the first multi-modal fusion BEV object detection algorithm based on polar coordinates. We designed three specialized modules for this approach: the Polar Region Candidates Generation Module, the Polar Region Query Generation Module, and the Polar Region Information Fusion Module. In the Polar Region Candidates Generation Module, we use a region proposal-based segmentation method to remove irrelevant areas from images, enhancing PolarFusion's information processing efficiency. These segmented image regions are then integrated into the point cloud segmentation task, addressing feature misalignment during fusion. The Polar Region Query Generation Module leverages prior information to generate high-quality target queries, reducing the time spent learning from initialization. For the Polar Region Information Fusion Module, PolarFusion employs a simple yet efficient self-attention to merge internal information from images and point clouds. This captures long-range dependencies in image texture information while preserving the precise positional data from point clouds, enabling more accurate BEV object detection. We conducted extensive experiments on challenging BEV object detection datasets. Both qualitative and quantitative results demonstrate that PolarFusion achieves an NDS of 76.1% and mAP of 74.5% on the nuScenes test set, significantly outperforming Cartesian-based methods. This advancement enhances the environmental perception capabilities of autonomous vehicles and contributes to the development of future intelligent transportation systems. The code will be released at https://github.com/RunshuaiGe/PolarFusion.git.
More Related Videos
 07:13
Author Spotlight: An Efficient and Robust Software for Automated Fusion of Multiple Preclinical Imaging Modalities
Published on: October 27, 2023
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
Related Concept Videos
 01:22
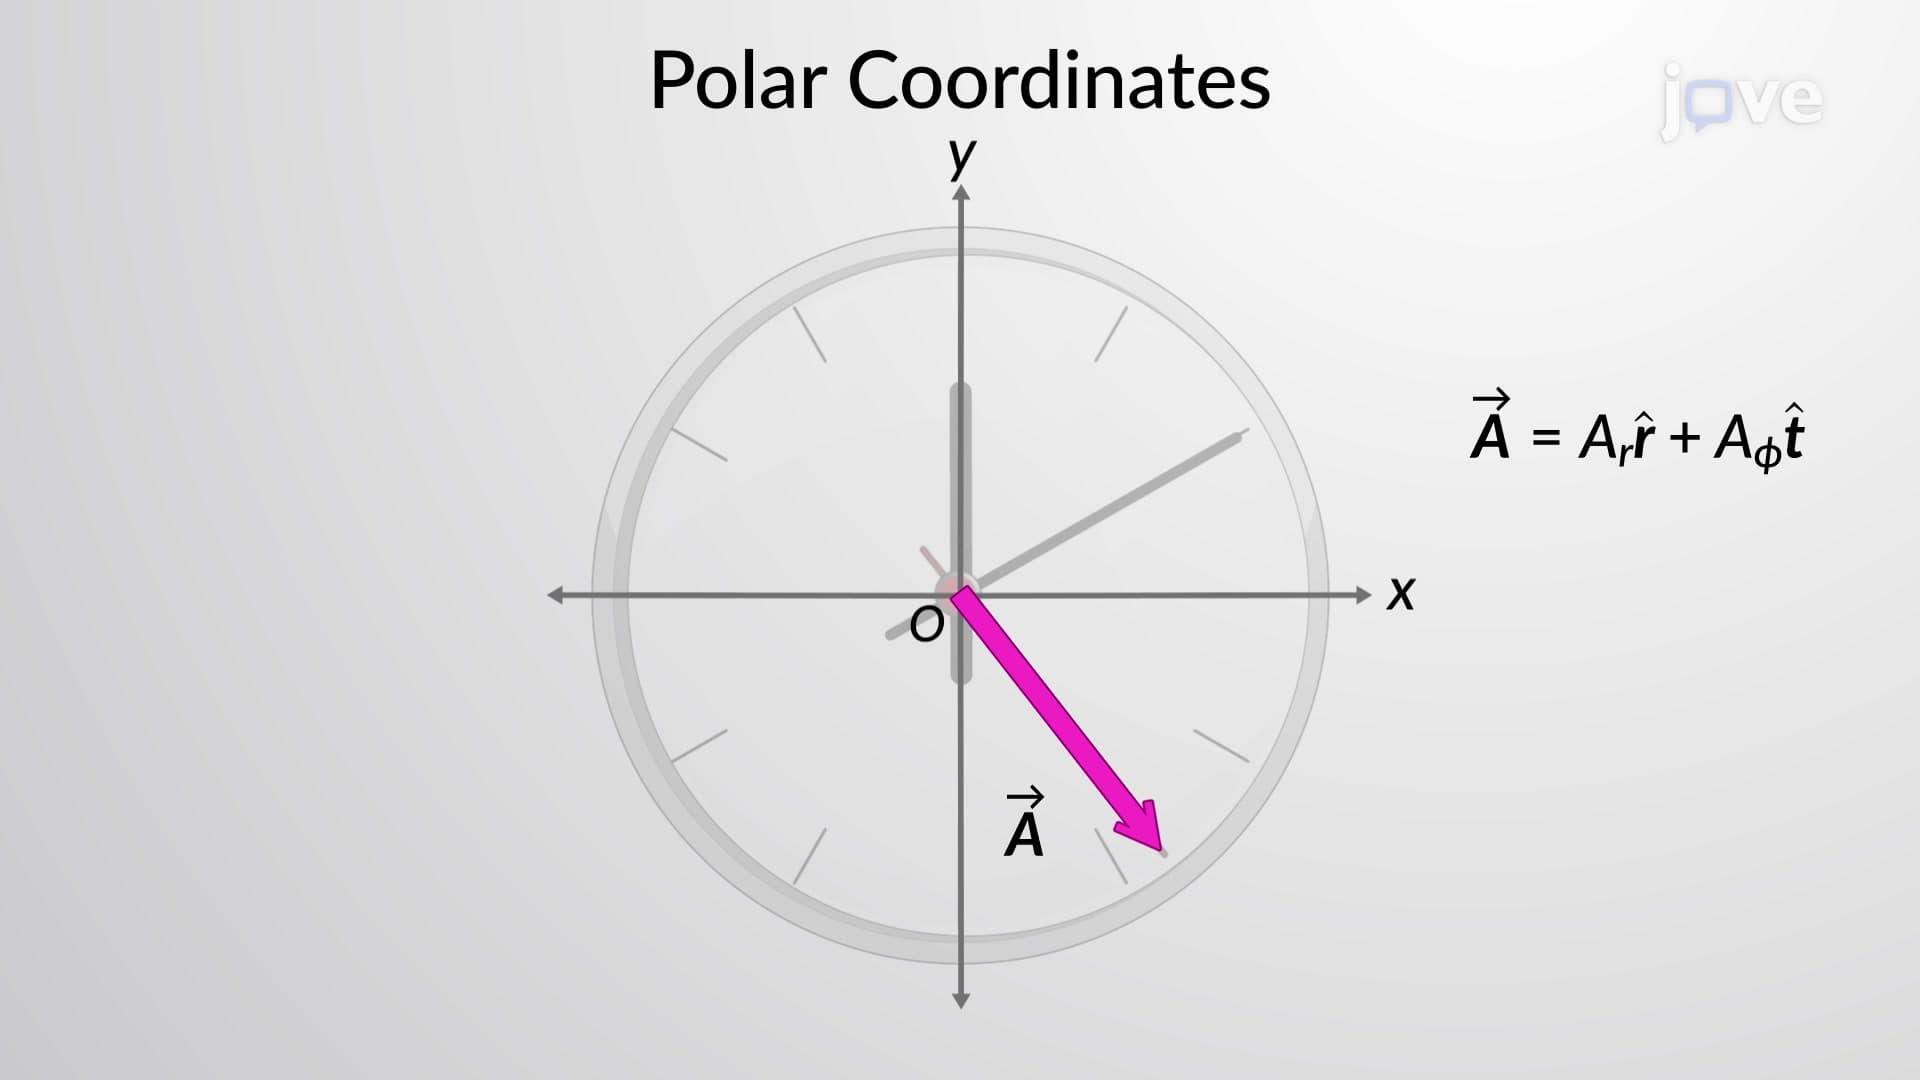
Polar and Cylindrical Coordinates
 01:27
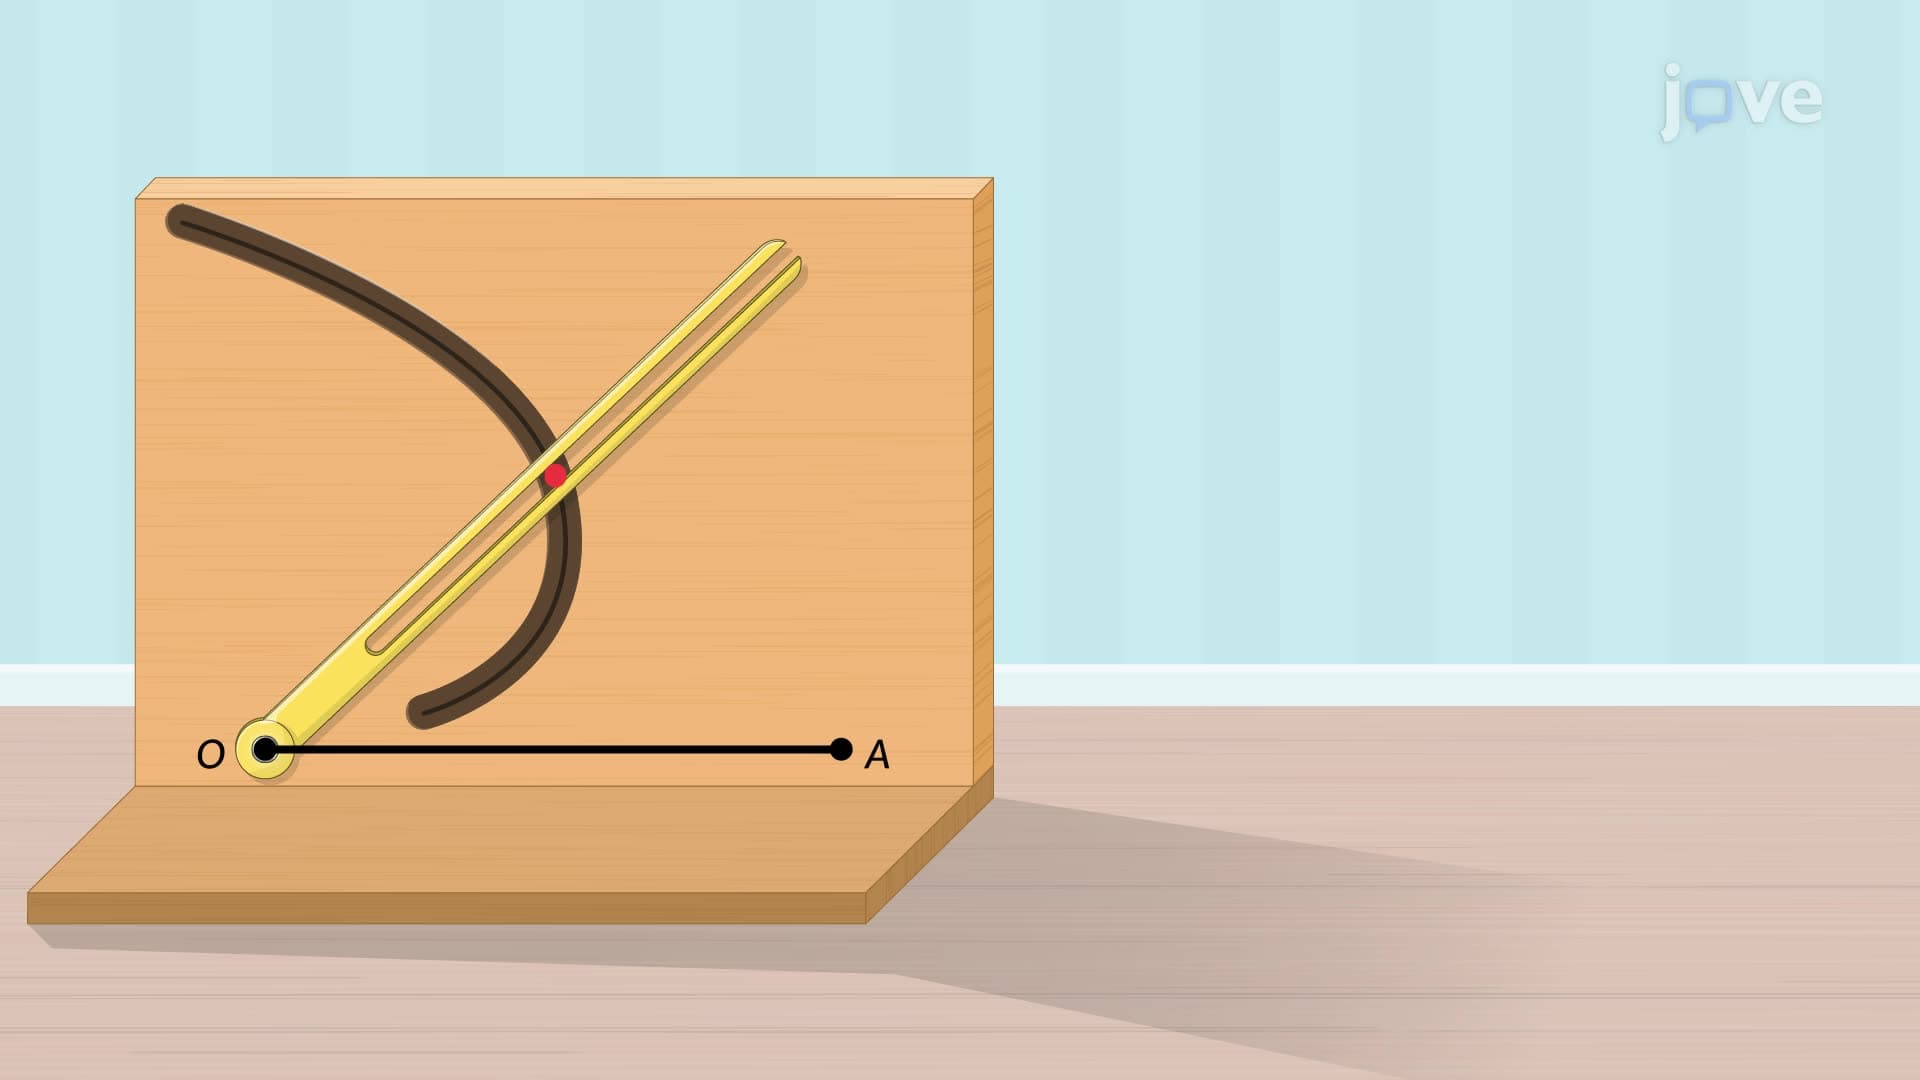
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
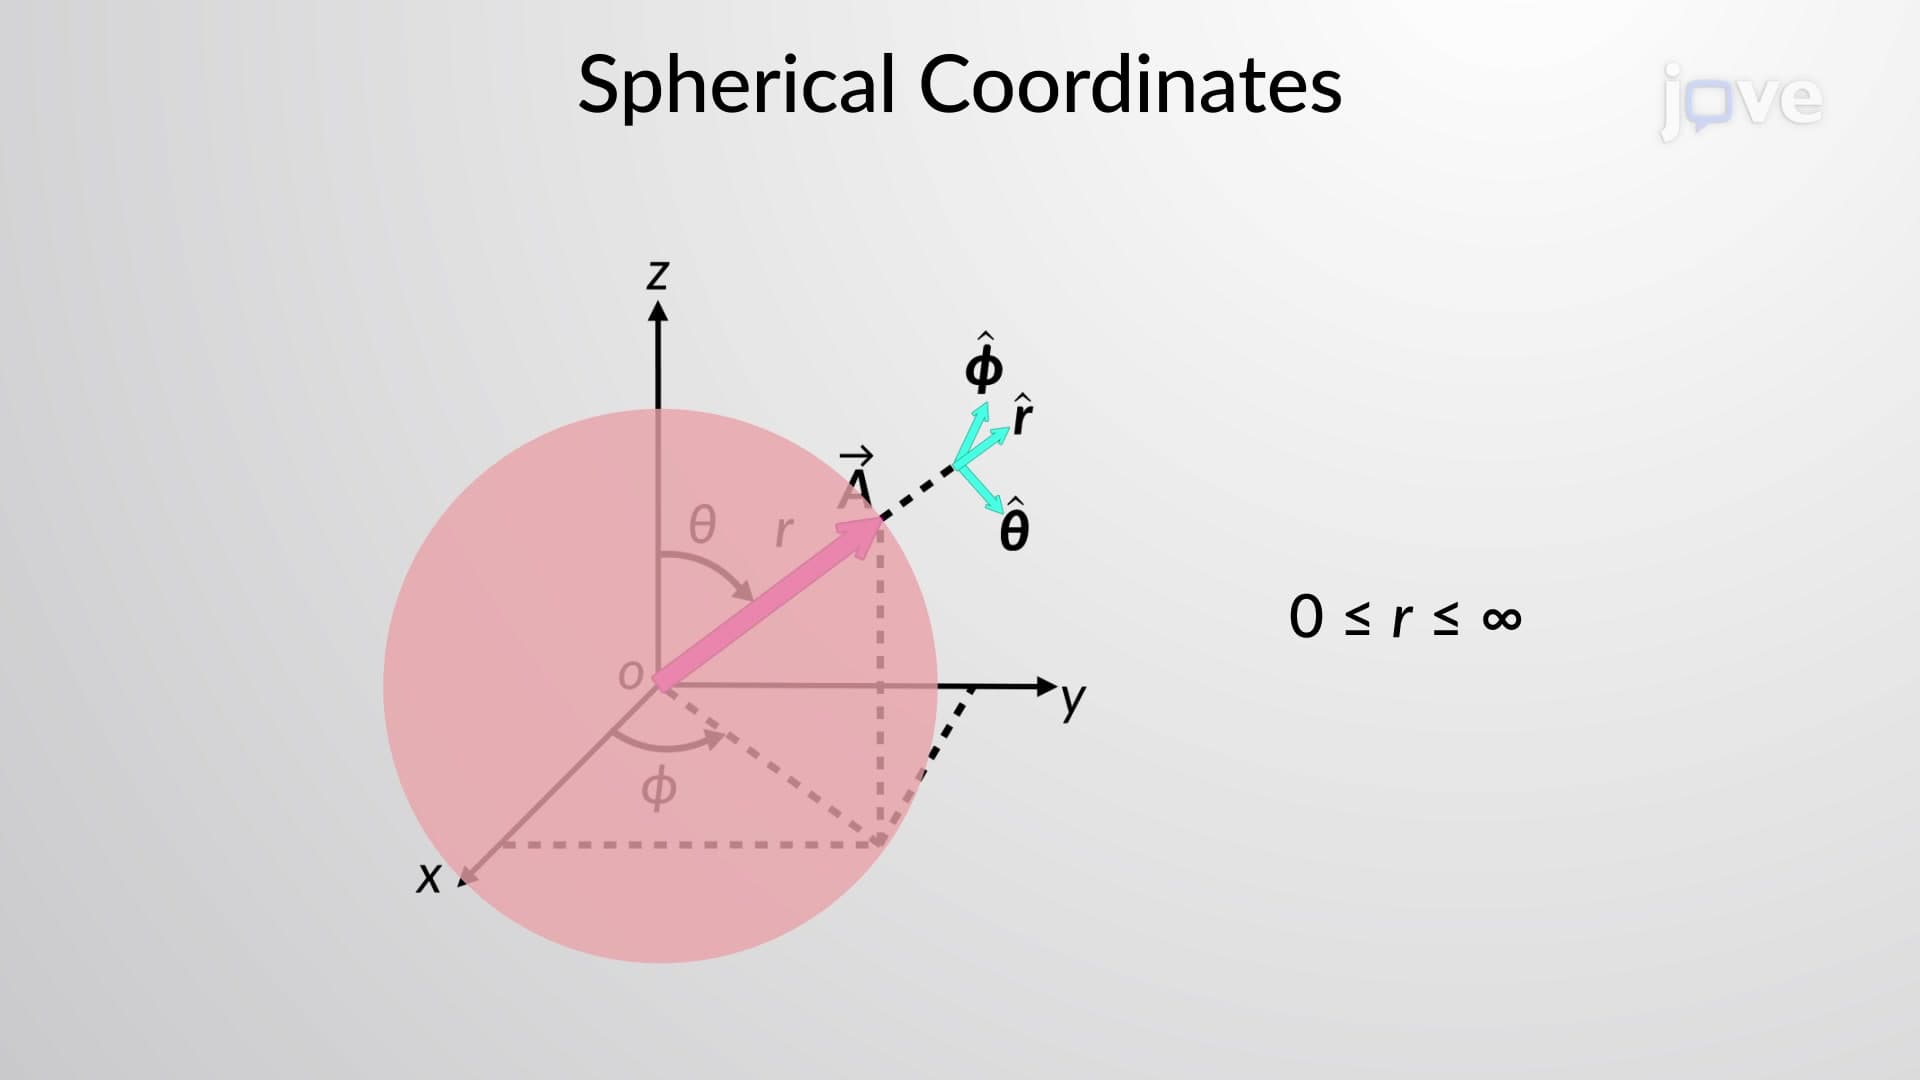
Spherical Coordinates
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...