A pivot joint steering mechanism for tip-everting soft growing robots
Related Experiment Video
Updated: Sep 13, 2025

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Tianchen Ji1, Zheyuan Bi1, Lin Cao1
1School of Electrical and Electronic Engineering, The University of Sheffield, Sheffield, United Kingdom.

Abstract:
Soft growing robots (SGRs) navigate confined environments by everting material from the tip while keeping the rest of the body stationary, enabling frictionless navigation. This opens up huge potential for inspection, search, and rescue tasks. However, controlling the direction of tip growth is still a challenge because of the ever-changing tip of the robot during tip growth. This study presents a compact steering mechanism that integrates a tendon-driven pivot joint with a pressure-tunable internal bladder. By modulating friction between the pivot joint and the inner material, the mechanism switches between two states: decoupled (stationary for bending) and coupled (move forward together with robot's inner material). This enables the robot to bend locally and then continue growing in the new direction, without using complex full-body actuation or external mechanisms. A robotic platform was developed to implement this mechanism, and its performance was characterized and validated through modeling and experiments. Experimental results confirm that the mechanism achieves reliable tip steering, closely matches kinematics models, and interacts gently with the environment. The proposed design offers a scalable and structurally simple solution for long-range navigation in soft growing robots.


Related Concept Videos
 01:23
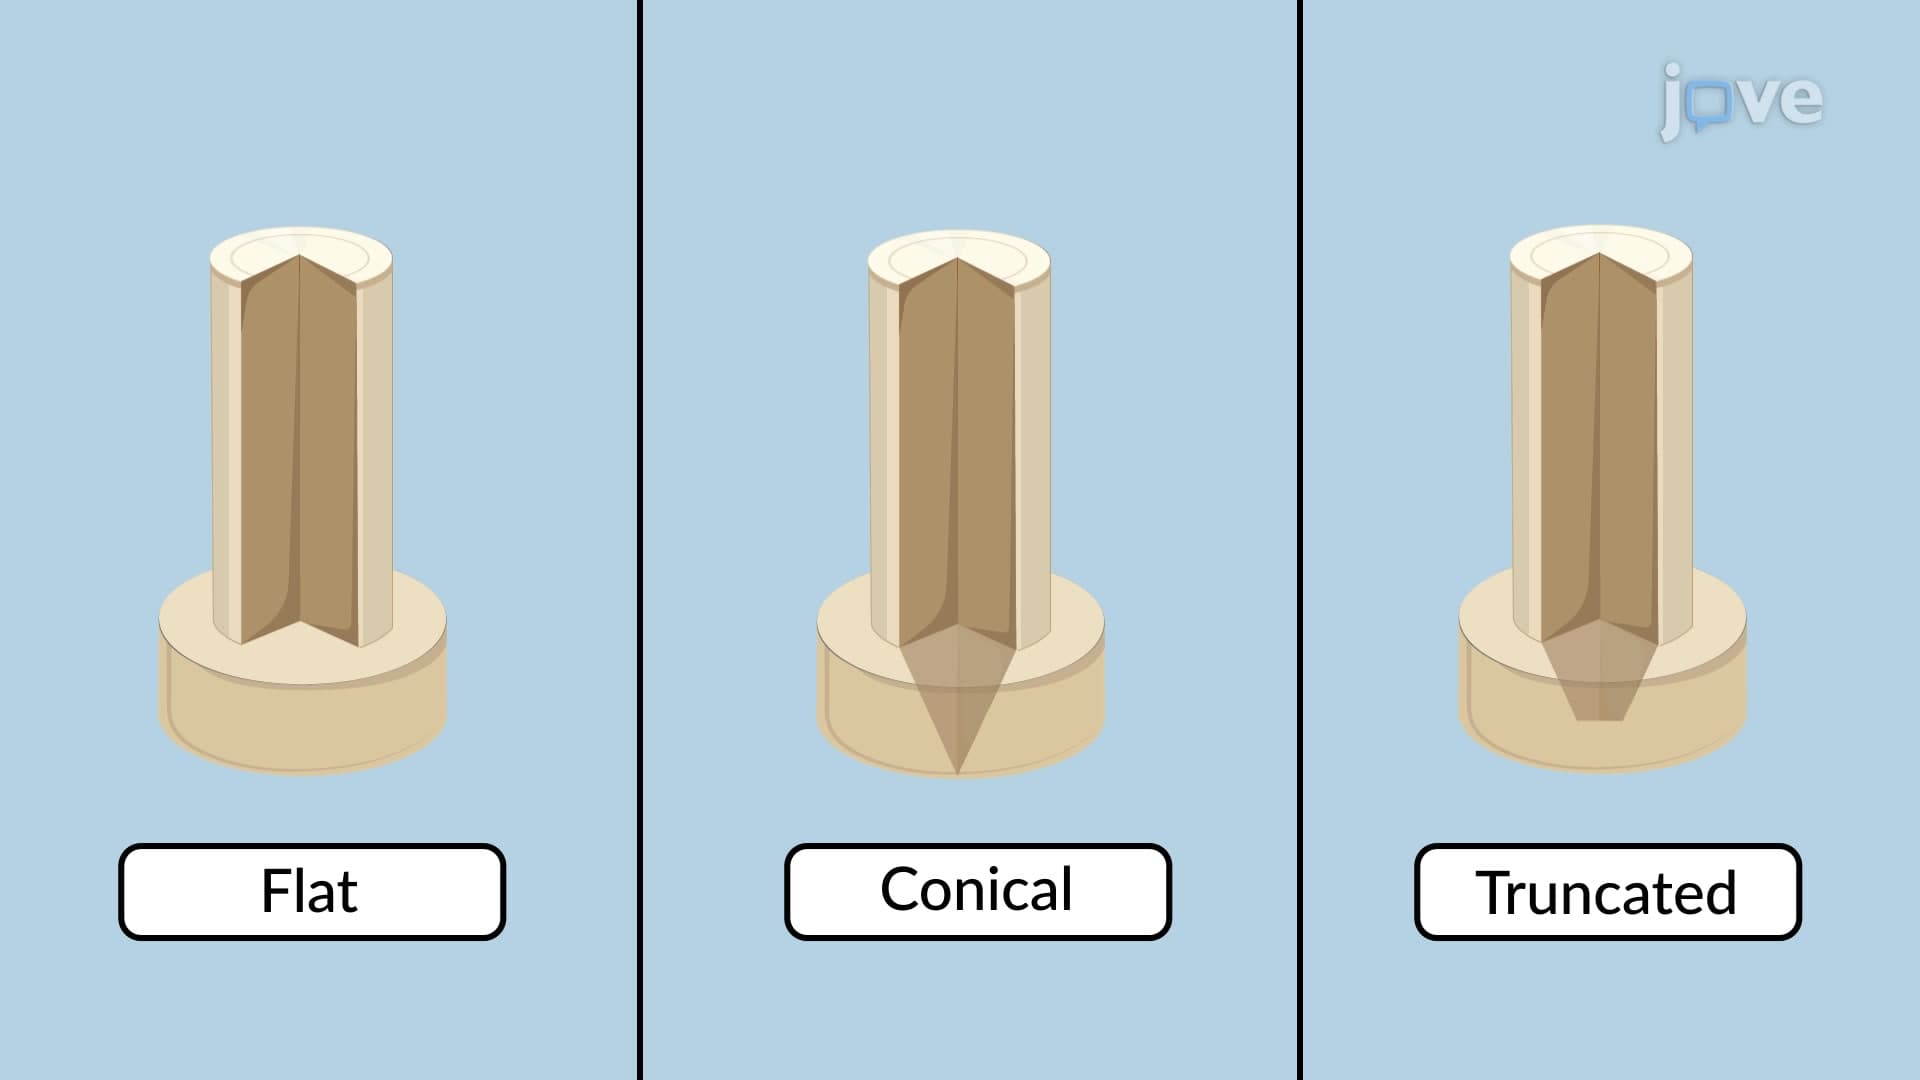
Pivot Bearings
A pivot bearing is a specialized type of bearing designed to support axial loads on a rotating shaft. The bearing surface, or the pivot, is positioned at the end of a shaft to support the axial thrust. The pivot may...
 01:20
Plastic Deformation in Circular Shafts
 01:13
Angle of Twist: Problem Solving
 01:26
Rotational Motion about a Fixed Axis
 01:15
Torque Free Motion
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...