Related Experiment Video
Updated: Aug 7, 2026
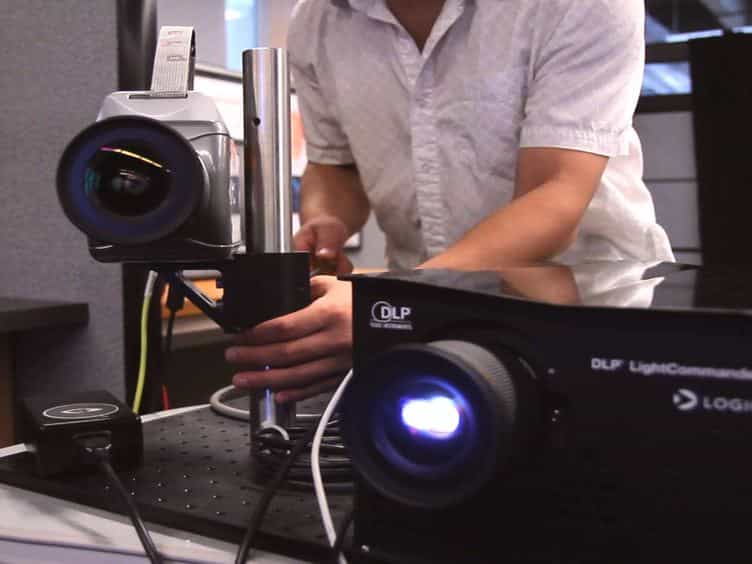

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
Ghost imaging video algorithm based on the multidimensional vector matrix Walsh transform of bidirectional N-aligned

Abstract:
In the ghost imaging system based on the multidimensional vector matrix Walsh transform, the Walsh speckle pattern is used to continuously sample the moving target object, so there is a certain correlation and complementary detail information between multiple frames in the ghost imaging video. In our previous research, we broke through the inherent limitations of the digital micromirror device refresh rate on ghost imaging systems, allowing us to reconstruct more detailed frames. Therefore, by utilizing the correlation between these detailed frames in the time and space domains, we can improve the comfort of ghost imaging videos from the perspective of improving the single-frame quality of ghost imaging videos. To further improve multi-frame quality by utilizing more detailed frames in ghost imaging videos, this paper proposes a ghost imaging video algorithm based on the multidimensional vector matrix Walsh transform of bidirectional N-aligned fusion frames. Combining deep learning with computational ghost imaging, utilizing a bidirectional N-alignment algorithm and a deep learning neural network framework for target frame integration. The ghost imaging videos obtained from previous research can be improved in terms of noise, motion blur, and single-frame detail richness to enhance the imaging quality of the target frame. This paper constructs an encoding module and a corresponding feature fusion module suitable for multidimensional vector Walsh transform ghost imaging from the perspective of network width and feature multi-branch extraction based on GoogleNet Inception V3. A loss function suitable for four-dimensional vector matrix Walsh transform ghost imaging has been defined, which can better eliminate the noise and distortion caused by Walsh speckle sampling. After comparing the experimental results of moving objects, the results show that the algorithm proposed in this paper has significantly improved structural similarity, blur index, noise index, and other aspects compared to existing ghost imaging video optimization methods. The similarity angle of the NRSS structure has increased by 18.58% compared to the original reconstructed image, the blur parameter has increased by 31.9%, and the noise parameter has risen by 9.22%.
Related Concept Videos
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:16
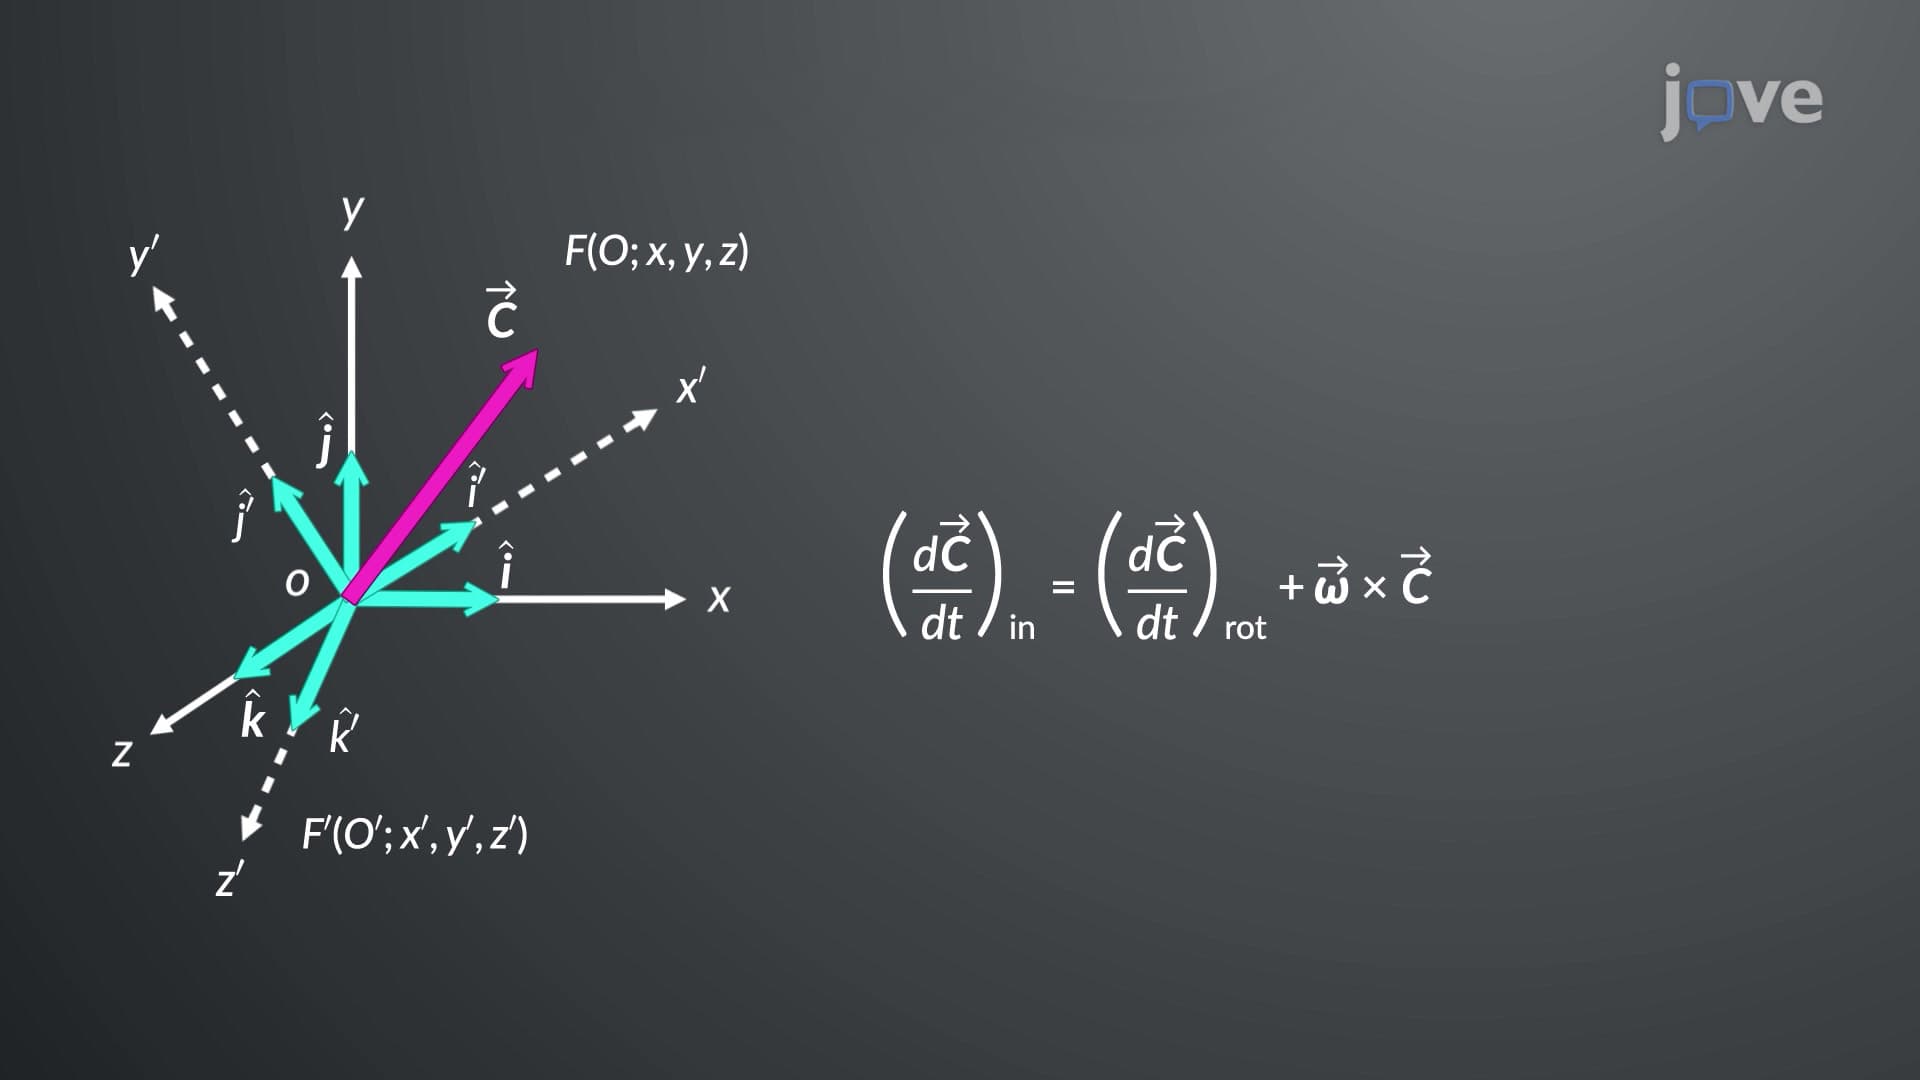
Vector Transformation in Rotating Coordinate Systems
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
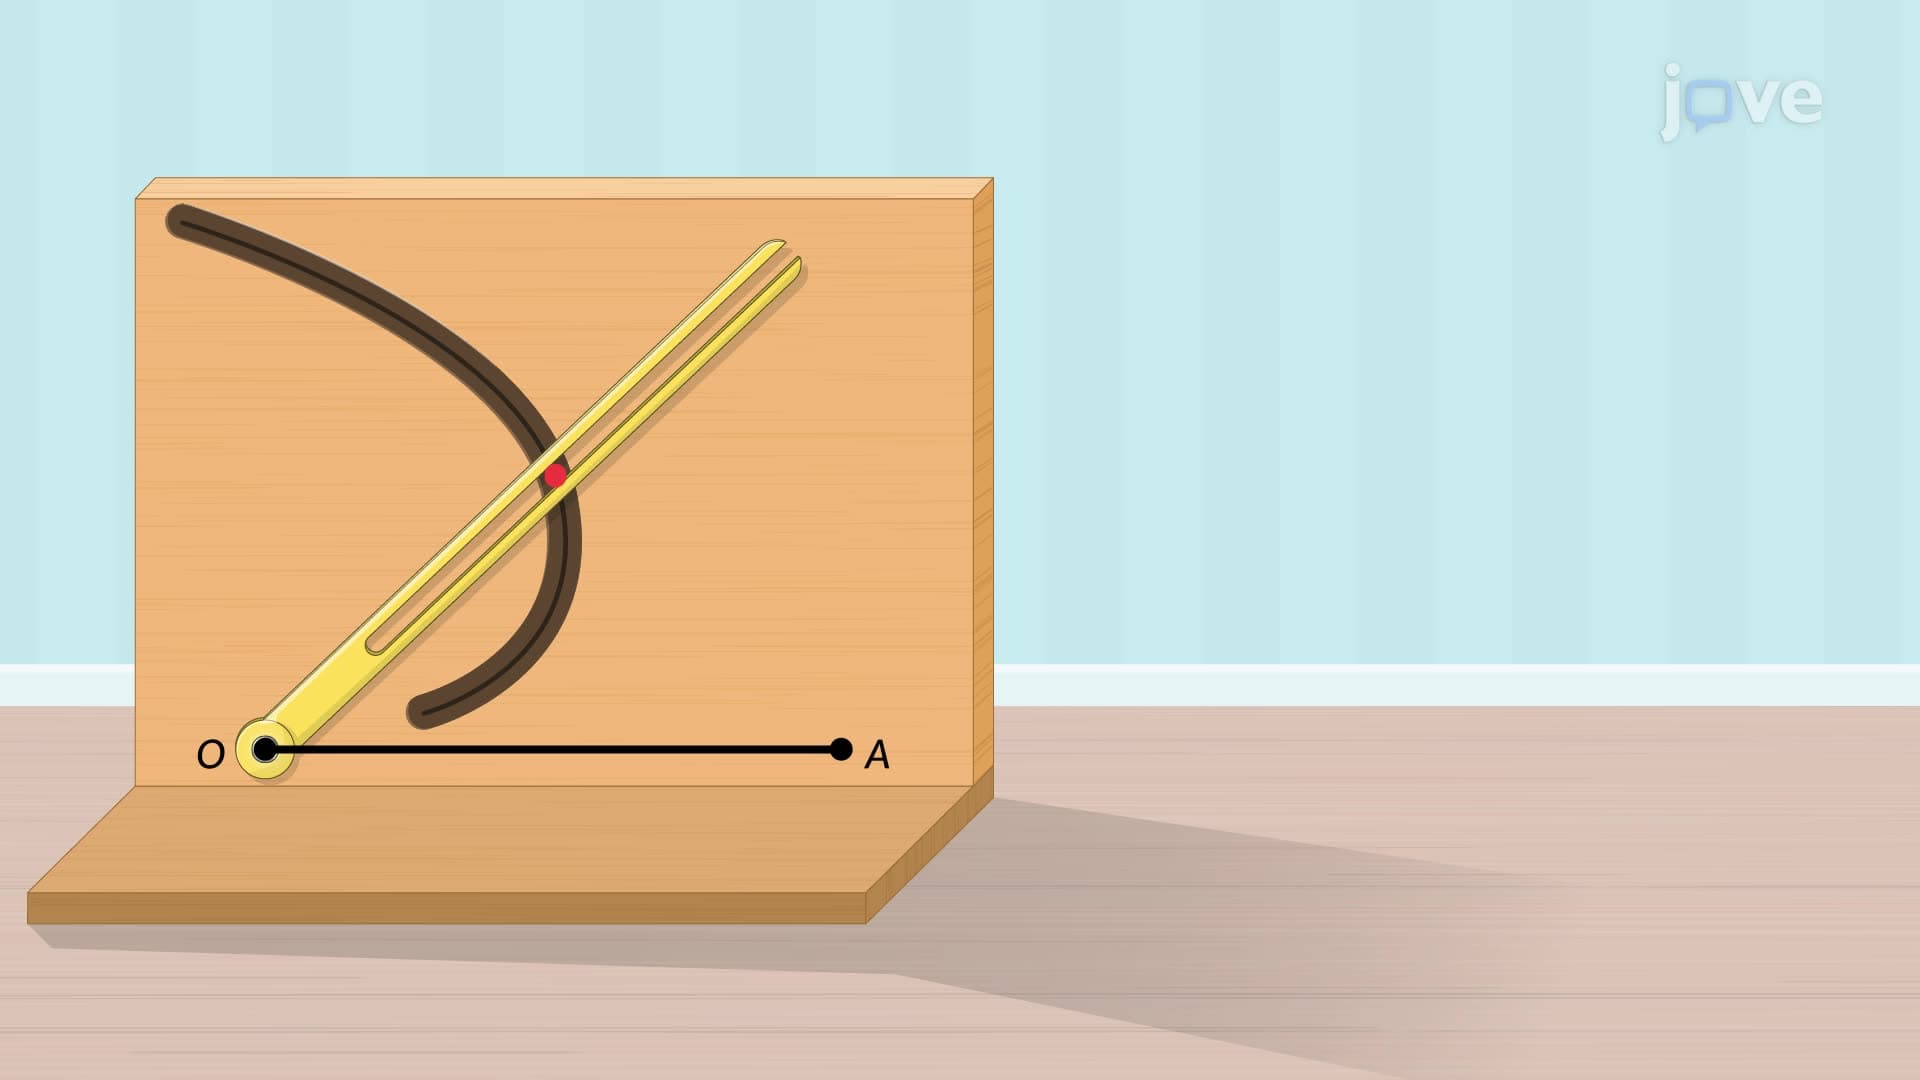 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:17
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...