Gentleflow: A time-synchronized optimization approach for online trajectory generation with gentle torque control for manipulators
Related Experiment Video
Updated: Jan 16, 2026

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Shize Zhao1, Tianjiao Zheng1, Chengzhi Wang1
1State Key Laboratory of Robotics and System, School of Mechatronics Engineering, Harbin Institute of Technology, Harbin 150001, China.

Abstract:
This paper proposes Gentleflow, a time-synchronized online trajectory generation (OTG) method for smooth torque control in multi-joint manipulators. The proposed method generates synchronized joint trajectories while satisfying velocity, acceleration, and jerk constraints. It can start from arbitrary initial states and efficiently guide the system toward the desired target state. Unlike traditional methods, Gentleflow not only explicitly incorporates jerk constraints into the synchronization process, but also proactively tightens the allowable jerk bounds below the original constraint values, in order to suppress torque rate variations and achieve smoother trajectory transitions. This refined jerk treatment significantly contributes to smoother motion profiles and improved compliance. Extensive experimental validation was conducted on a 6-DOF industrial robot to demonstrate the effectiveness of Gentleflow and the importance of jointly minimizing jerk and optimizing motor torque for time-synchronized multi-joint motion. The experiments included abrupt target-switching motions, multi-stage sequential assembly tasks, and repetitive long-distance movements. Performance was compared with Ruckig and the minimum-acceleration-peak synchronization method. Real-world end-effector vibration measurements show that Gentleflow substantially reduces vibrations during high-speed motions, resulting in smoother, more compliant, and repeatable trajectories, providing strong evidence of its practical advantages for complex robotic tasks.


Related Concept Videos
 01:15
Torque Free Motion
 01:26
Orthogonal Trajectories
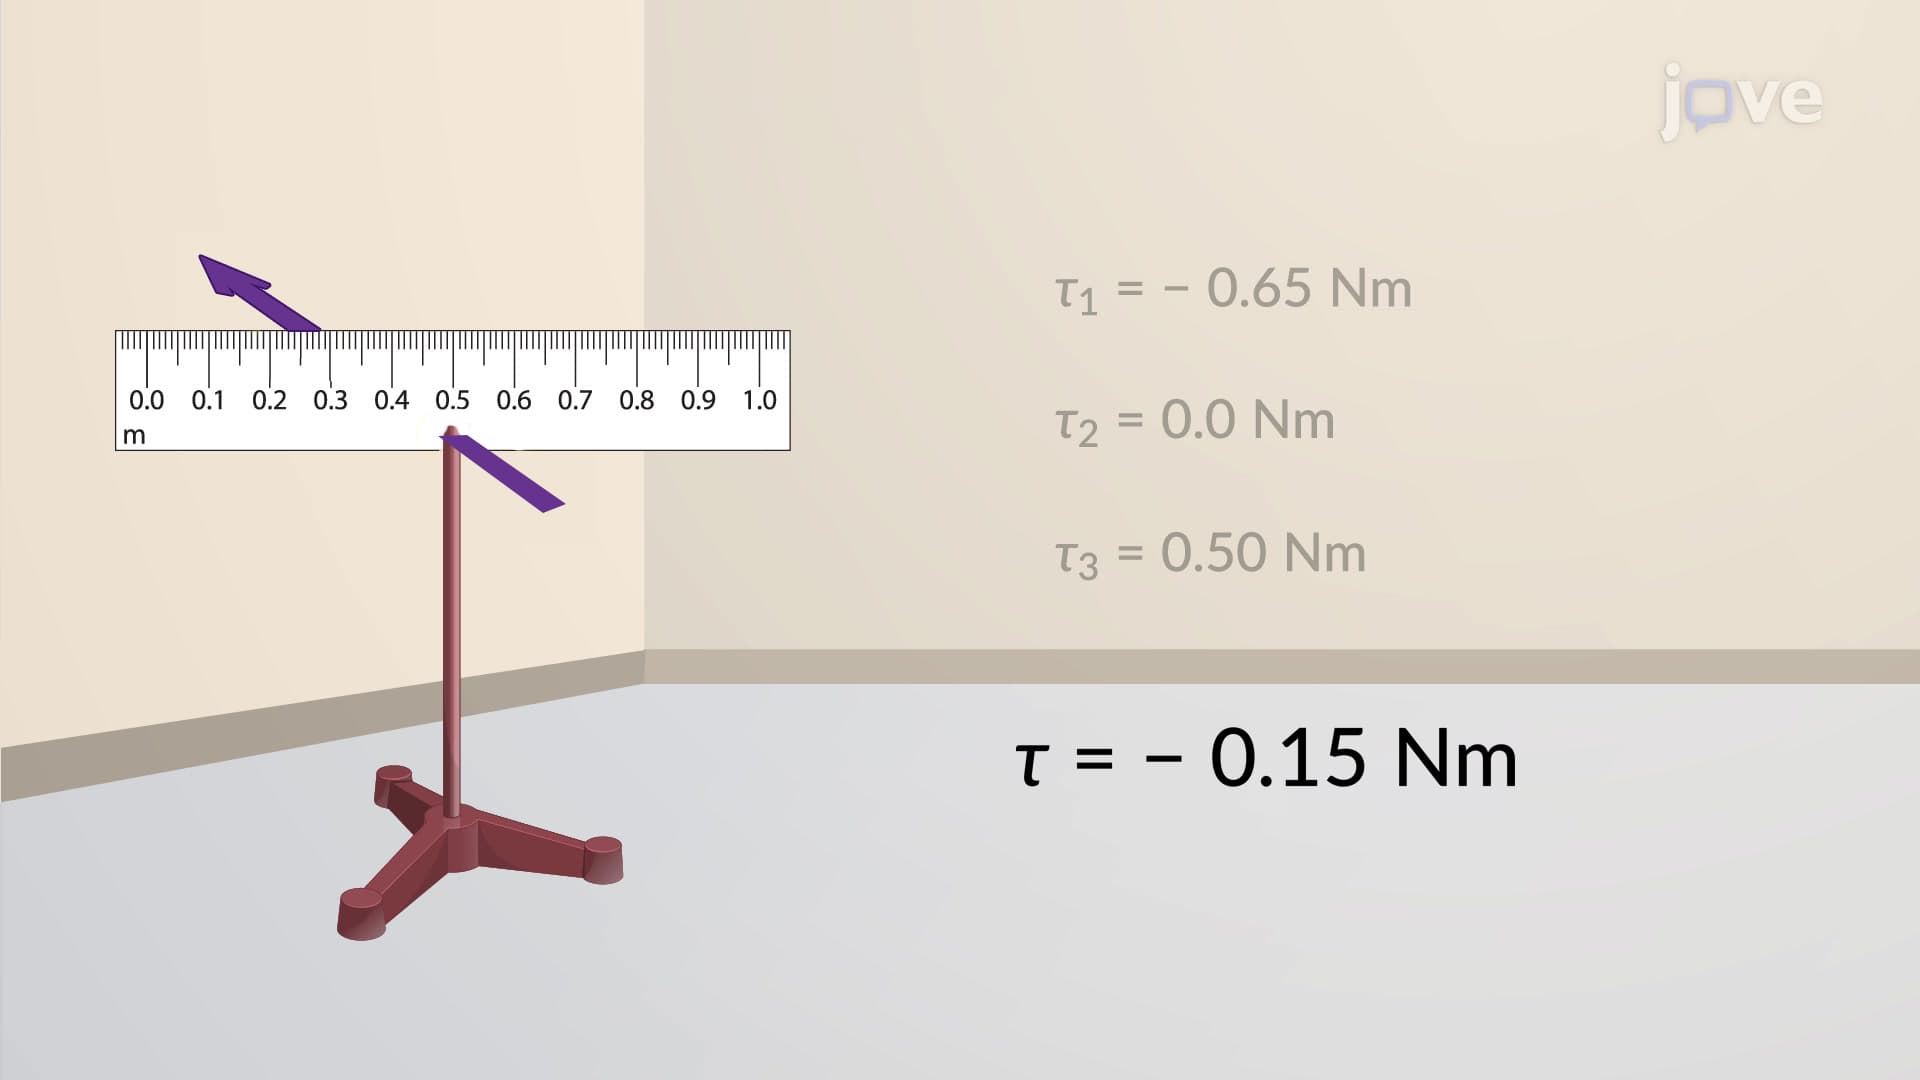 01:19
Net Torque Calculations
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...