Related Experiment Video
Updated: Jan 16, 2026
Author Spotlight: Bridging the Gap Between In Vivo and Ex Vivo Studies with the "Avatar" Technique to Advance Muscle Mechanics Research
Published on: August 18, 2023
Characterization of muscle synergy similarity and adaptation in hip exoskeleton-assisted locomotion
Ruiming Wang1, Dewei Liu2, Linfan Yu2
1Feinberg School of Medicine, Northwestern University, Chicago, IL, United States.

Abstract:
Recent advancements in robotic exoskeleton technology have demonstrated significant potential in reducing users' energy consumption and muscle activation. However, how users adjust muscle recruitment and coordination in expenditure and muscle activation levels. However, the mechanisms underlying users' adaptation of muscle recruitment and coordination patterns in response to external robotic assistance remain poorly understood. This study introduces a novel methodological framework for quantifying the impact of assistance on human muscle synergy patterns through similarity analysis, which incorporates a weighted summation of Pearson correlation coefficients between paired synergies. Eight healthy adult participats underwent treadmill walking trials under two conditions: with and without a portable hip exoskeleton. The experimental protocol consisted of two distinct sessions. In the first session, participants walked with varying assistive torque, enabling comparative analysis of muscle synergies across different conditions. The second session, involved a temporal adaptation assessment, where participants initially walked in a 2-min zero torque (ZT) mode, followed by a 10-min assistive mode, and concluded with another 2-min ZT mode. The analysis revealed that four primary synergies accounted for 92.73% ± 0.43% and 93.06% ± 0.64% of the variance in surface electromyography (sEMG) signals during exoskeleton-assisted and unassisted walking, respectively. The developed similarity indices proved effective in quantifying significance differences in muscle synergy patterns between assisted and unassisted conditions. These findings provide valuable insights into neuromuscular control mechanisms during exoskeleton-assisted locomotion, contributing to the optimization of robotic assistance strategies.
Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
 01:20
Excitation-Contraction Coupling in Skeletal Muscles
When an action...
 01:23
Muscles that Move the Leg
Anterior Compartment
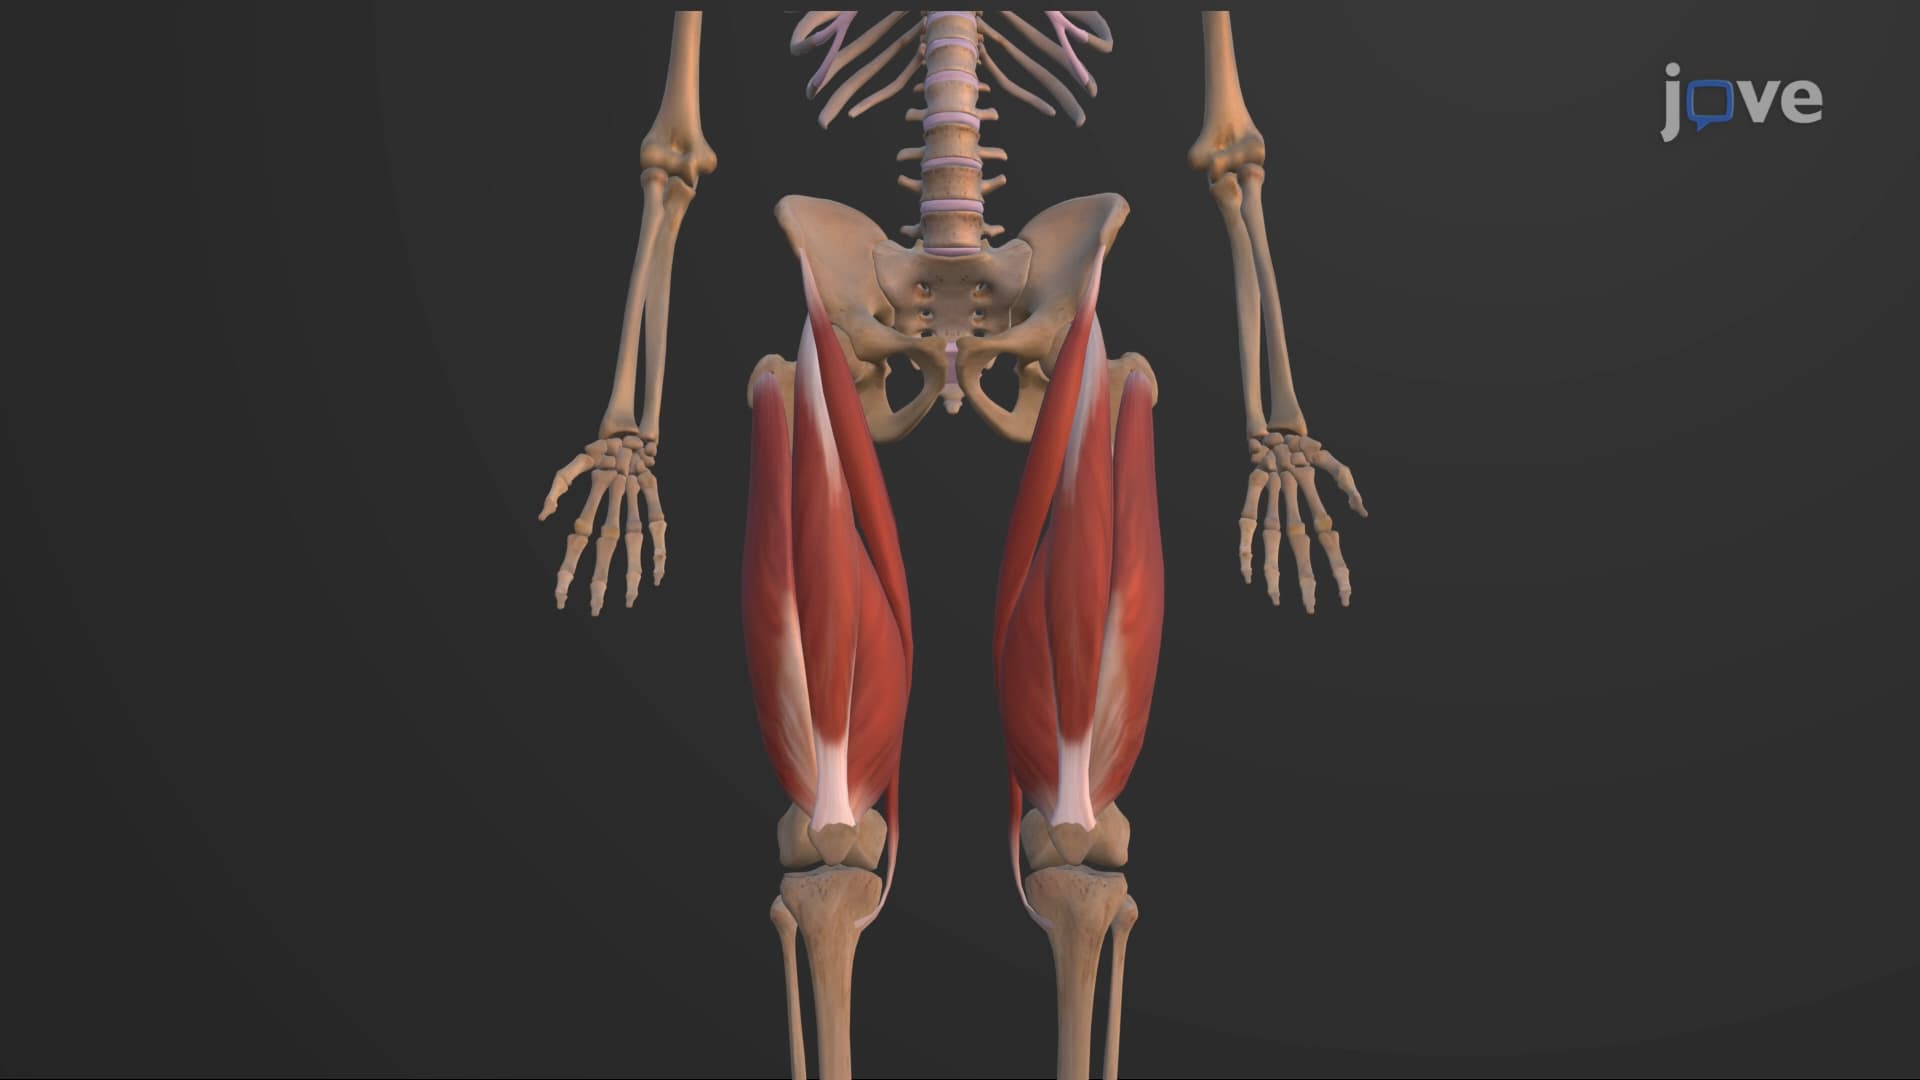
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:15
Overview of Skeletal Muscle
 01:18
Axial and Appendicular Muscles
Axial Muscles
Axial muscles, situated along the body's midline, are intricately connected to the axial skeleton, which includes the skull, spine, ribs, and sternum. These muscles facilitate facial expressions and...
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...