Related Experiment Video
Updated: Jan 15, 2026
SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Givenness hierarchy theoretic sequencing of robot task instructions
Zhao Han1, Daniel Hammer1, Kevin Spevak1
1Department of Computer Science, Colorado School of Mines, Golden, CO, United States.

Introduction:
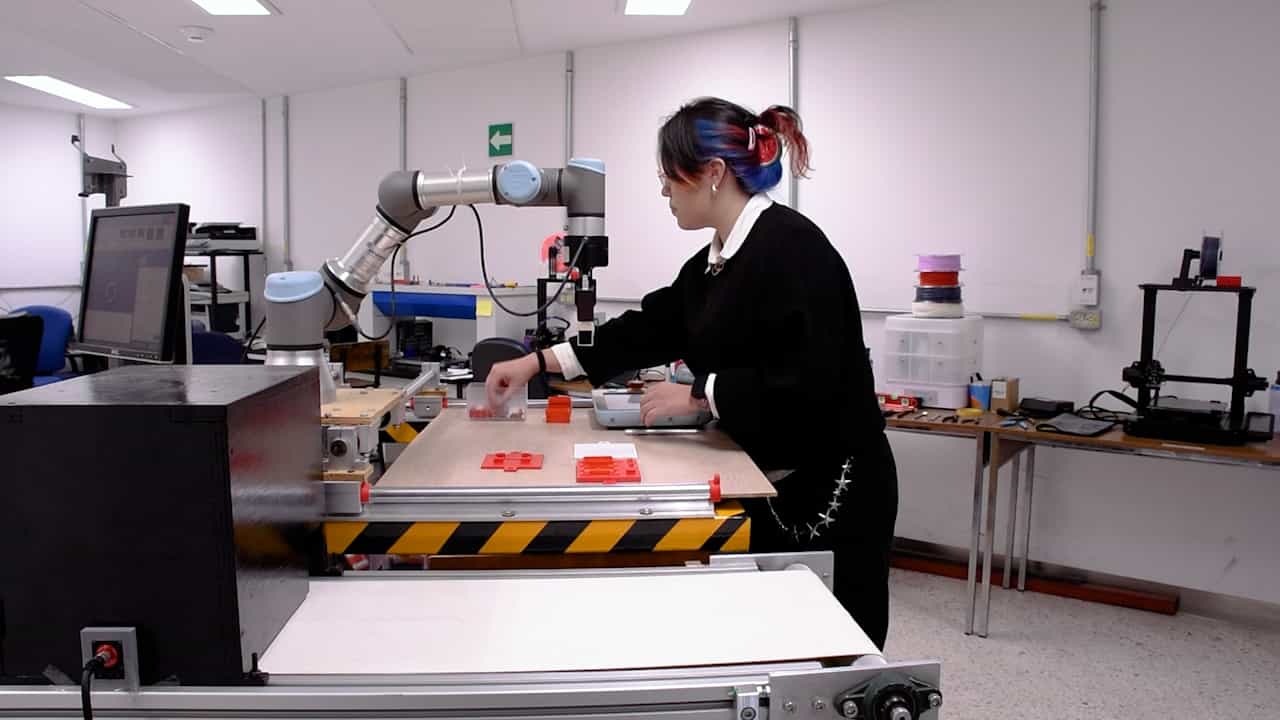
When collaborative robots teach human teammates new tasks, they must carefully determine the order to explain different parts of the task. In robotics, this problem is especially challenging, due to the situated and dynamic nature of robot task instruction.
Method:
In this work, we consider how robots can leverage the Givenness Hierarchy to "think ahead" about the objects they must refer to so that they can sequence object references to form a coherent, easy-to-follow series of instructions.
Results And Discussion:
Our experimental results (n = 82) show that robots using this GH-informed planner generate instructions that are more natural, fluent, understandable, and intelligent, less workload demanding, and that can be more efficiently completed.
More Related Videos
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:30
Machines: Problem Solving II
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:24
Reinforcement Schedules
Once a behavior is learned,...
 01:16
Statically Indeterminate Problem Solving