Related Experiment Video
Updated: Feb 13, 2026

Noninvasive Determination of Vortex Formation Time Using Transesophageal Echocardiography During Cardiac Surgery
Published on: November 28, 2018
Robotic transesophageal echocardiography: system design and deep learning-based kinematic modeling
Seyed MohammadReza Sajadi1, Abbas Tariverdi2, Henrik Brun3,4
1Department of Informatics, University of Oslo, Oslo, Norway.

Introduction:
This paper presents a robotic transesophageal echocardiography (TEE) system that replicates all essential degrees of freedom available in manual TEE procedures. The developed robotic system advances dual-subsystem architectures through enhanced mechanical design and deep learning-based kinematic modeling.
Methods:
Building upon previous designs that manipulate the TEE probe from both handle and gastroscope tube, our system integrates with a teleoperated UR5 manipulator to accommodate both supine and left lateral decubitus patient positions, addressing the full spectrum of clinical TEE procedures. The system features 6 DOF at the probe handle and 2 DOF at the gastroscope tube. Together, these create optimal gastroscope tube geometry, minimizing cable tension asymmetry and friction-induced nonlinearities inherent in cable-driven mechanisms. The primary contribution is a data-driven kinematic model using recurrent neural networks with LSTM units that overcomes fundamental limitations of analytical approaches for continuum manipulators. Trained on 42,000 synchronized pose-command pairs collected across three gastroscope tube configurations (0°, 45°, 90° bends), the model effectively captures dead zones, hysteresis, and coupling effects between steering mechanisms.
Results:
Experimental validation demonstrates strong position tracking across all three gastroscope tube configurations. The model achieves RMSE of 1.267 mm for the 0° configuration, 1.209 mm for the 45° configuration, and 1.194 mm for the 90° configuration. Mean orientation errors are 7.064° at 0°, 8.503° at 45°, and 4.947° at the clinically critical 90° configuration. The model exhibits coordinate frame independence with only 0.06 mm RMSE difference between original and rotated datasets. This confirms true kinematic learning rather than coordinate-specific patterns. With 1.8 ms inference time, the system achieves real-time performance essential for clinical deployment.
Discussion:
This integration of robotic system design with deep learning establishes a foundation for semi-autonomous TEE systems. The developed system can support both diagnostic TEE examinations and TEE-guided structural heart interventions.

Related Concept Videos
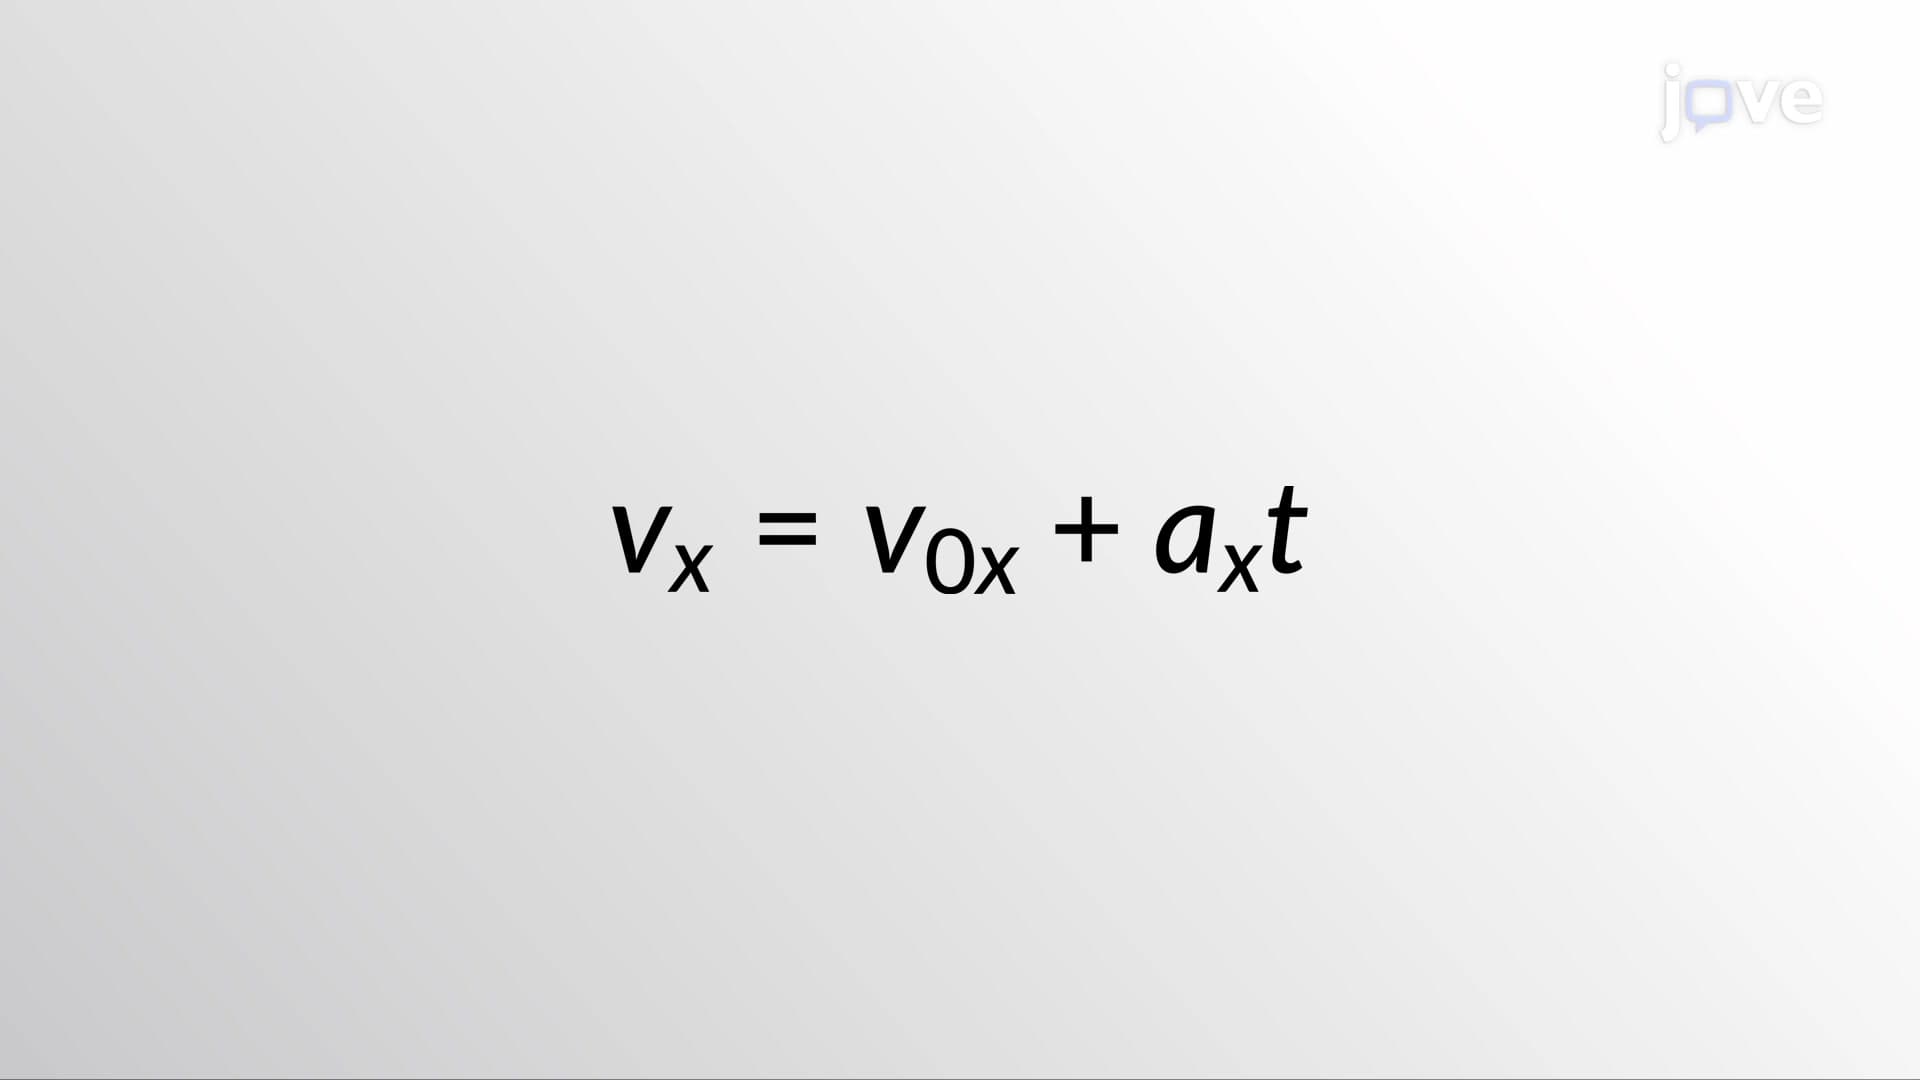 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 02:01
Group Design
 02:01
Factorial Design
 01:18
Kinematic Equations - III
Using the kinematic equations,...