Related Experiment Video
Updated: Feb 28, 2026

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
A Predefined-Time Robust Neural Dynamics Controller for Projective Synchronization of Second-Order Chaotic Systems

Abstract:
Given the high coupling of state variables in second-order chaotic systems, the projective synchronization control schemes for first- or fractional-order chaotic systems are not applicable in second-order chaotic systems. Also, the current control schemes on second-order chaotic systems are difficult to tradeoff between convergence and robustness. To address the above issues, this article develops a predefined-time robust neural dynamics controller (PTRNDC). First, a predefined-time nonsingular terminal sliding mode variable (PTNTSMV) is designed to control the coupling of errors in the projective synchronization of second-order chaotic systems, ensuring the nonsingularity and convergence. Hence, a predefined-time double-integral zeroing neural dynamics (ZNDs) design formula based on a time-base generator (TBG) is devised to ensure that the sliding mode variable attains the desired sliding mode surface swiftly and robustly. The theorems about the stability, convergence, and robustness of the projective synchronization under the PTRNDC are analyzed rigorously, and the comparative simulations further verify the effectiveness of the PTRNDC. In addition, the chaotic sequences generated by the projective synchronization between the second-order chaotic systems are successfully applied in the image encryption, making the original image possess excellent visual distortion.

Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:18
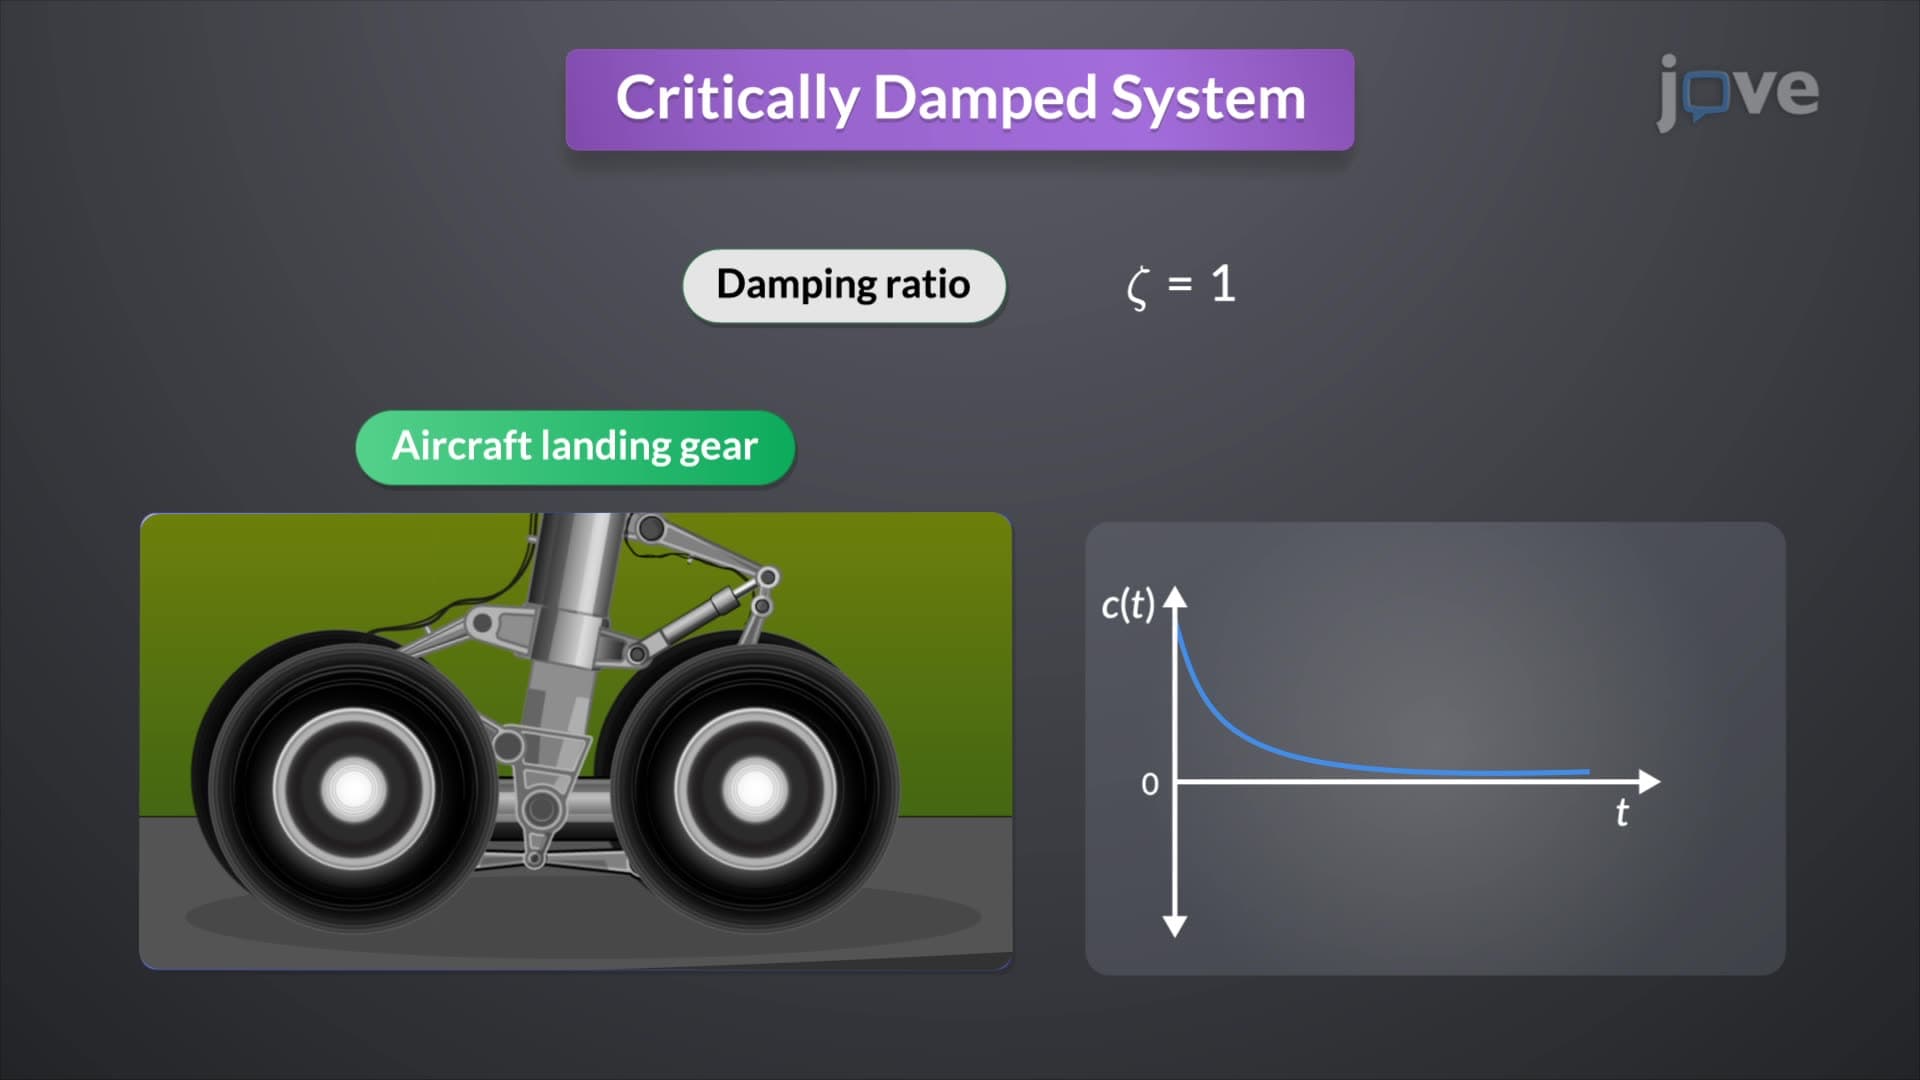
Second Order systems II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....