Multi-USV system for oil spill cleaning: Complete coverage path planning and path following
Related Experiment Video
Updated: Apr 1, 2026

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
1School of Future Technology, China University of Geosciences, Wuhan, Hubei 430074, China; School of Artificial Intelligence and Automation, China University of Geosciences, Wuhan, Hubei 430074, China; Hubei Key Laboratory of Advanced Control and Intelligent Automation for Complex Systems, Wuhan, 430074, China; Engineering Research Center of Intelligent Technology for Geo-Exploration, Ministry of Education, Wuhan, 430074, China.

Abstract:
This paper addresses the problem of oil spill cleanup using a multiple Unmanned Surface Vehicle (multi-USV) system, which is decomposed into two subproblems: complete coverage path planning and path following. In addressing the complete coverage path planning subproblem for an energy-constrained multi-USV system with a minimum turning radius, the problem is reformulated as a multi-USV Dubins coverage path planning problem, which is then solved using a simulated annealing algorithm for path generation. For the path following subproblem, considering the fact that the velocity state of underactuated USVs is subject to measurement noise, a finite-time observer combining an Extended State Observer (ESO) and a Kalman Filter (KF) is constructed to estimate both the velocity states and lumped disturbances. A finite-time Line-of-Sight (FTLOS) guidance law is designed based on the estimated velocity, and a finite-time feedback controller is constructed using both the estimated disturbance and velocity. Through the designed guidance and controller, each USV successfully tracks the planned path and navigates at the specified speed within a finite-time interval.
More Related Videos
Related Concept Videos
 01:26
Microbial Bioremediation of Hydrocarbons
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:25
Design Example: Flow of Oil Through Circular Pipes
 01:11
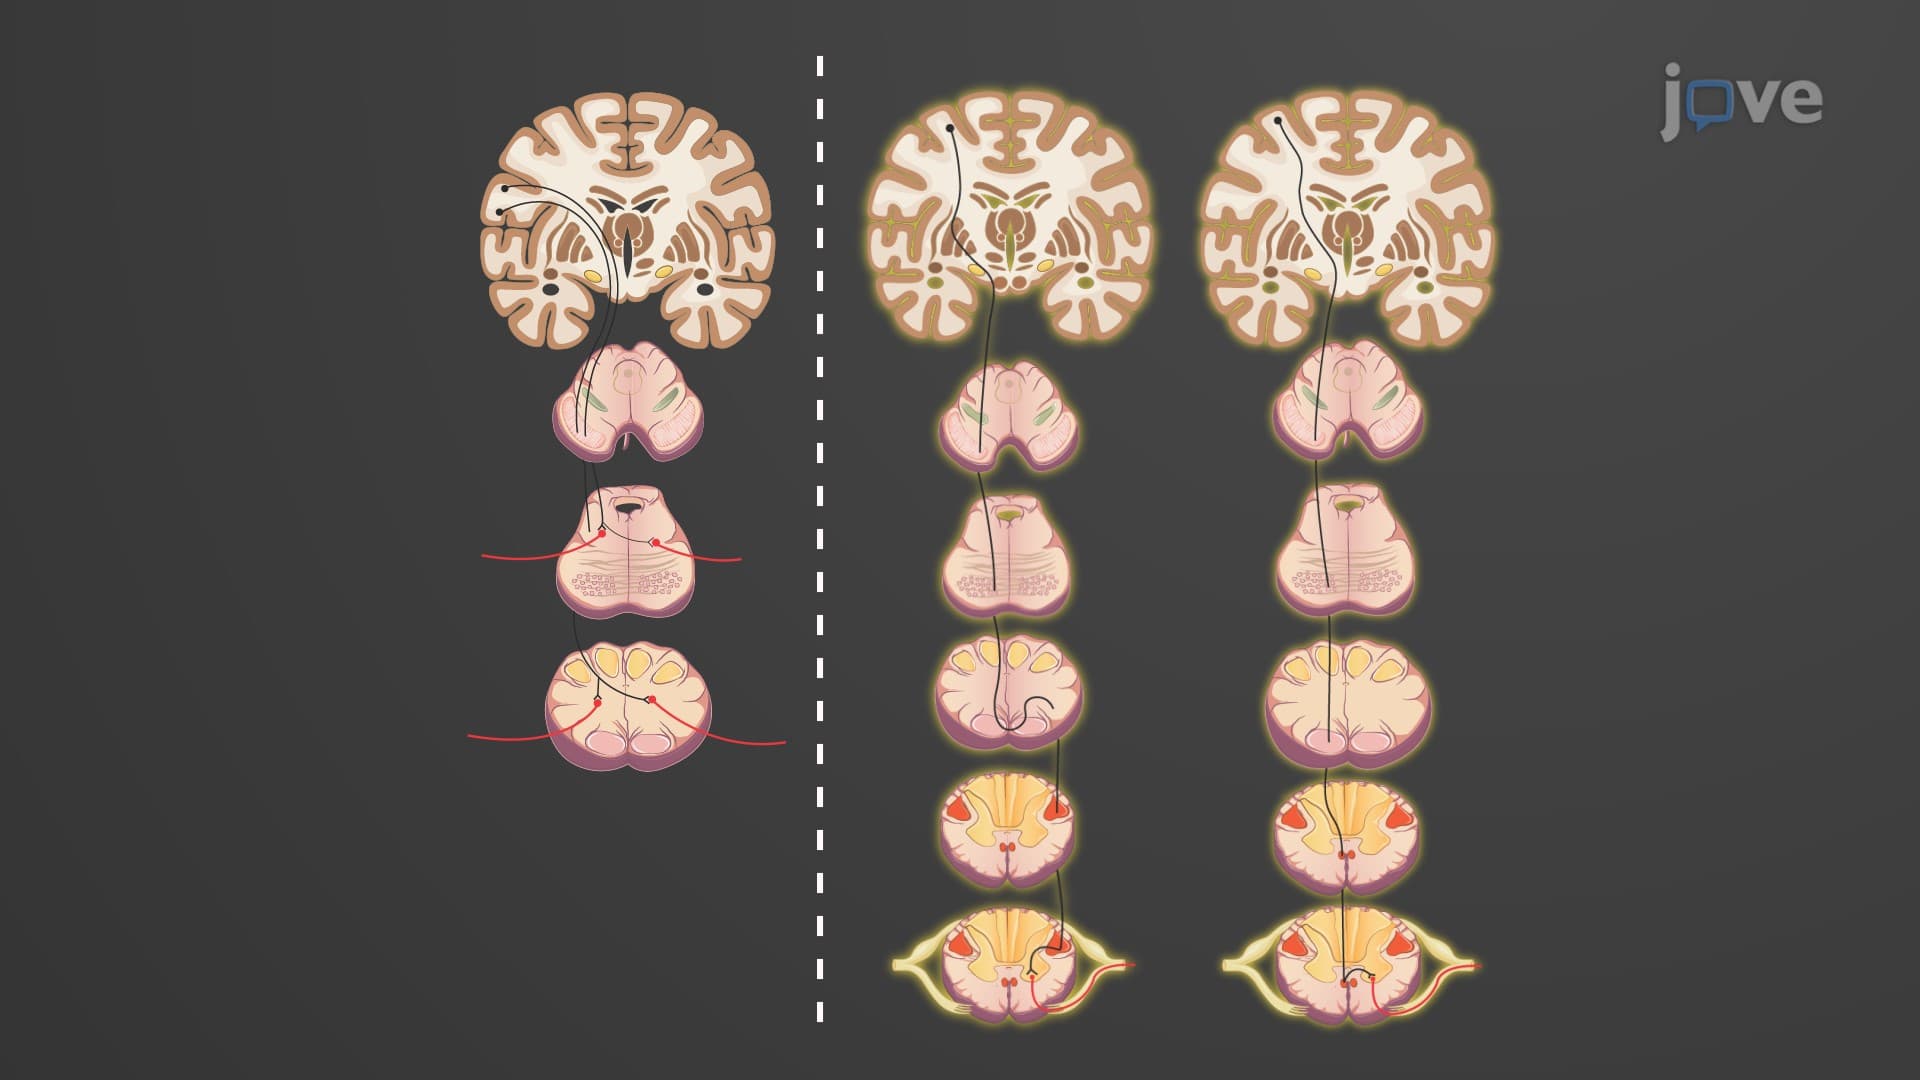
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...