H∞ Optimal Tracking Control for Two-Time-Scale Supply Chain Systems Subject to DoS Attack
Related Experiment Video
Updated: Apr 26, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020

Abstract:
This article investigates the $H_{\infty }$ optimal tracking control problem for supply chain systems characterized by two distinct time scales and vulnerability to denial-of-service (DoS) attacks. To reduce the computational complexity and eliminate the sensitivity to time-scale variations inherent in traditional lifting techniques, the system is decomposed into fast and slow subsystems using singular perturbation theory. A policy iteration (PI)-based $H_{\infty }$ optimal control scheme is proposed to attenuate the bullwhip effect in supply chain systems, namely, the amplification of customer demand uncertainty throughout the network. The control scheme allows inventory levels to accurately track desired targets even in the presence of perturbations. To address the information loss caused by DoS attacks, a nonlinear autoregressive (NAR) neural network-based predictor is designed to provide real-time state compensation. The method's effectiveness is validated through a case study of a potassium carbonate production process. Simulation results demonstrate that the proposed approach reduces the bullwhip effect by 63% and provides superior steady-state accuracy and dynamic performance compared with the existing integral sliding-mode and standard policy-iteration methods.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
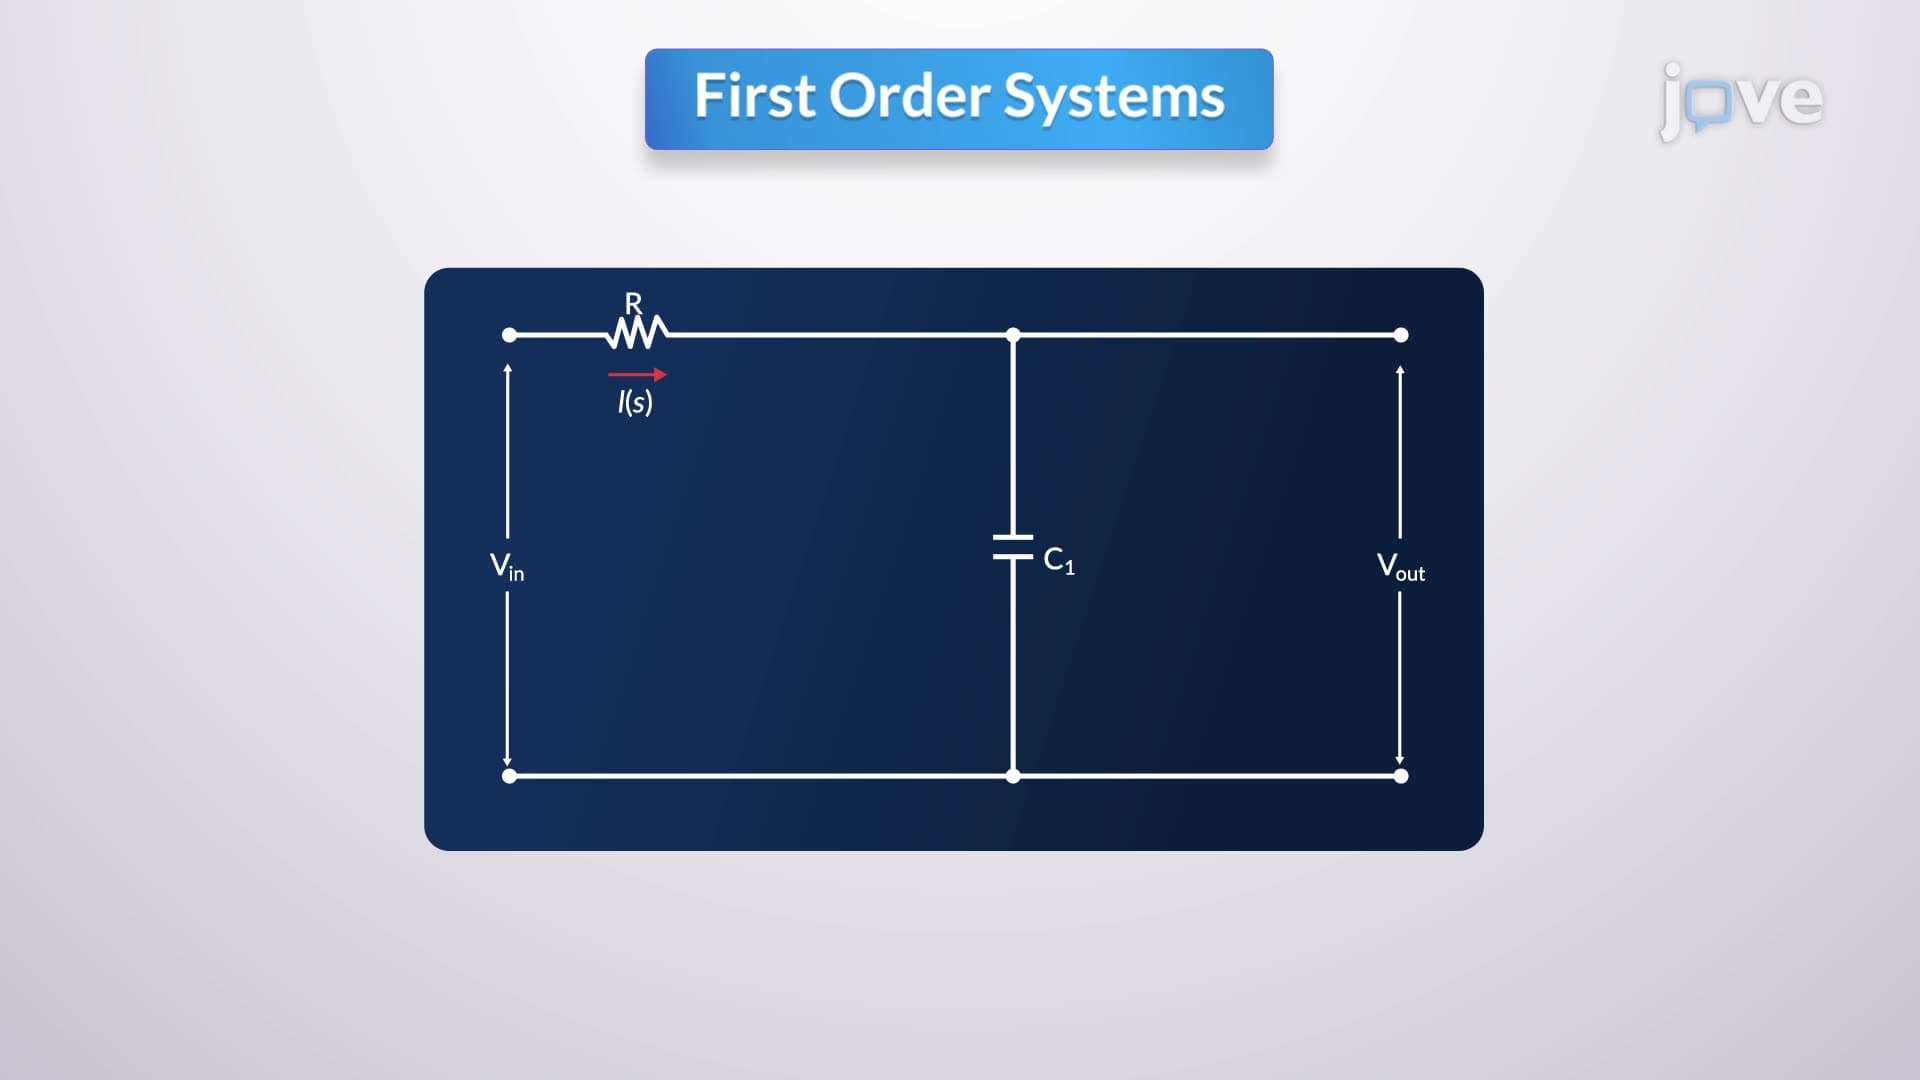
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:18
Second Order systems II
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:30
Derivatives of Inverse Trigonometric Functions