Related Experiment Video
Updated: Oct 28, 2026

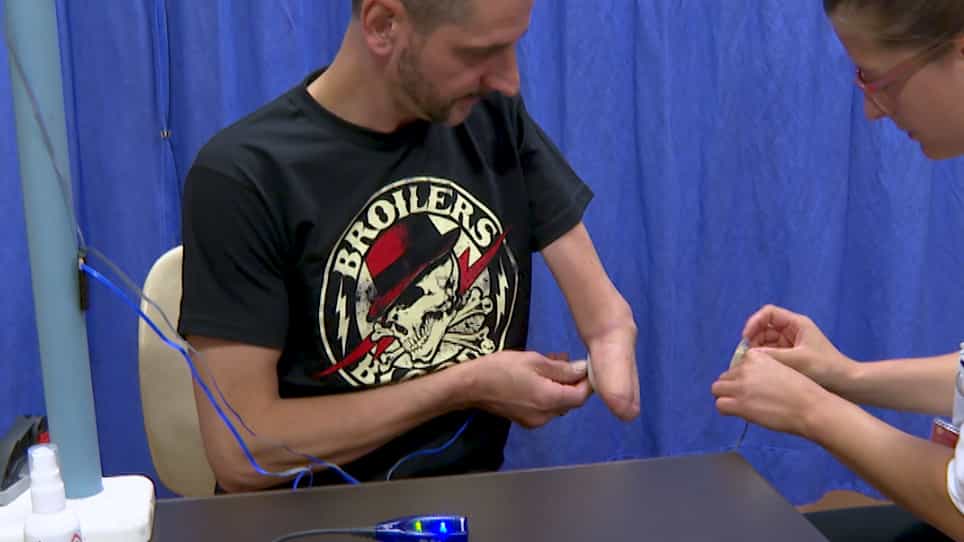
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Myoelectric Closed Loop Enables Unified Control Across Multiple Modalities of Hand Assistance Using Reconfigurable

Abstract:
Assistive technologies support individuals affected by physical, cognitive, or sensory impairments in performing daily tasks. Yet, most existing solutions remain constrained by task-specific designs and rigid control frameworks, limiting their scalability across users, configurations, and therapeutic goals. In contrast, reconfigurable soft robots enable adaptable physical embodiments, while surface electromyography (sEMG)-based control offers a transparent channel for measuring muscular effort. Together, they provide a foundation for advancing personalized, user-responsive assistive systems by enabling flexible, intuitive interactions between humans and robotic systems and enhancing engagement and adaptability during physical rehabilitation. In this work, we propose a unified control framework based on a human-in-the-loop (HITL) strategy that leverages sEMG to enable multiple hand assistance modalities deployable across robotic devices with reconfigurable kinematic structures. The controller closes the loop on sEMG-based forearm muscle activation to deliver repeatable, quantitative, and personalized hand rehabilitation tasks while dynamically adapting to user effort in accordance with the assistance-as-needed paradigm. We demonstrate the approach on two soft pneumatic devices based on the same modular haptic framework: TangiGlove, a glove-like wearable, and TangiBall, a spherical handheld interface. Experimental results confirm that the proposed framework generalizes across morphologies, delivers the desired levels of muscular assistance, and promotes active neuromotor engagement, showing that reconfigurable soft robots coupled with closed-loop sEMG-based control can provide scalable, user-centered, and effective hand assistance.
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:18
Hierarchy of Motor Control
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:22
Mechanical Systems