Related Experiment Video
Updated: May 19, 2026
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
A Lorenz-like system with an inversion symmetry: Topology of some of its attractors
1Physics Department, Université de Rouen Normandie, Avenue de l'Université, 76800 Saint-Etienne du Rouvray, France.

Abstract:
In a study devoted to discrete Lorenz systems, Gonchenko and co-workers [Chaos 32, 121107 (2022)] briefly mentioned a three-dimensional system that would be a Lorenz-like system if a quadratic monomial was not replaced with a cubic one. Such a modification introduces an inversion symmetry, rendering this system atypical and whose dynamics deserves to be investigated. This is here performed along a line of the parameter space in terms of the template for some of its attractors. There are similarities with the classical bifurcation diagram produced by the Lorenz system with R as the bifurcation parameter and some differences that are exhibited. In particular, it is shown that an attractor merging crisis with the saddle point located at the origin of the state space allows us to produce an attractor that is similar to the one observed in the Moore-Spiegel system long ago [Letellier, Ph.D. thesis, Paris vii University (1994)] and that is rarely observed in Lorenz-like systems. We also took the opportunity to show how it may be useful to investigate the structure of the dynamics that can be safely characterized with a first-return map built on {Δτn=τn-τn-1}, where τn is the duration of the return to a surface of section.
Related Concept Videos
 01:23
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:15
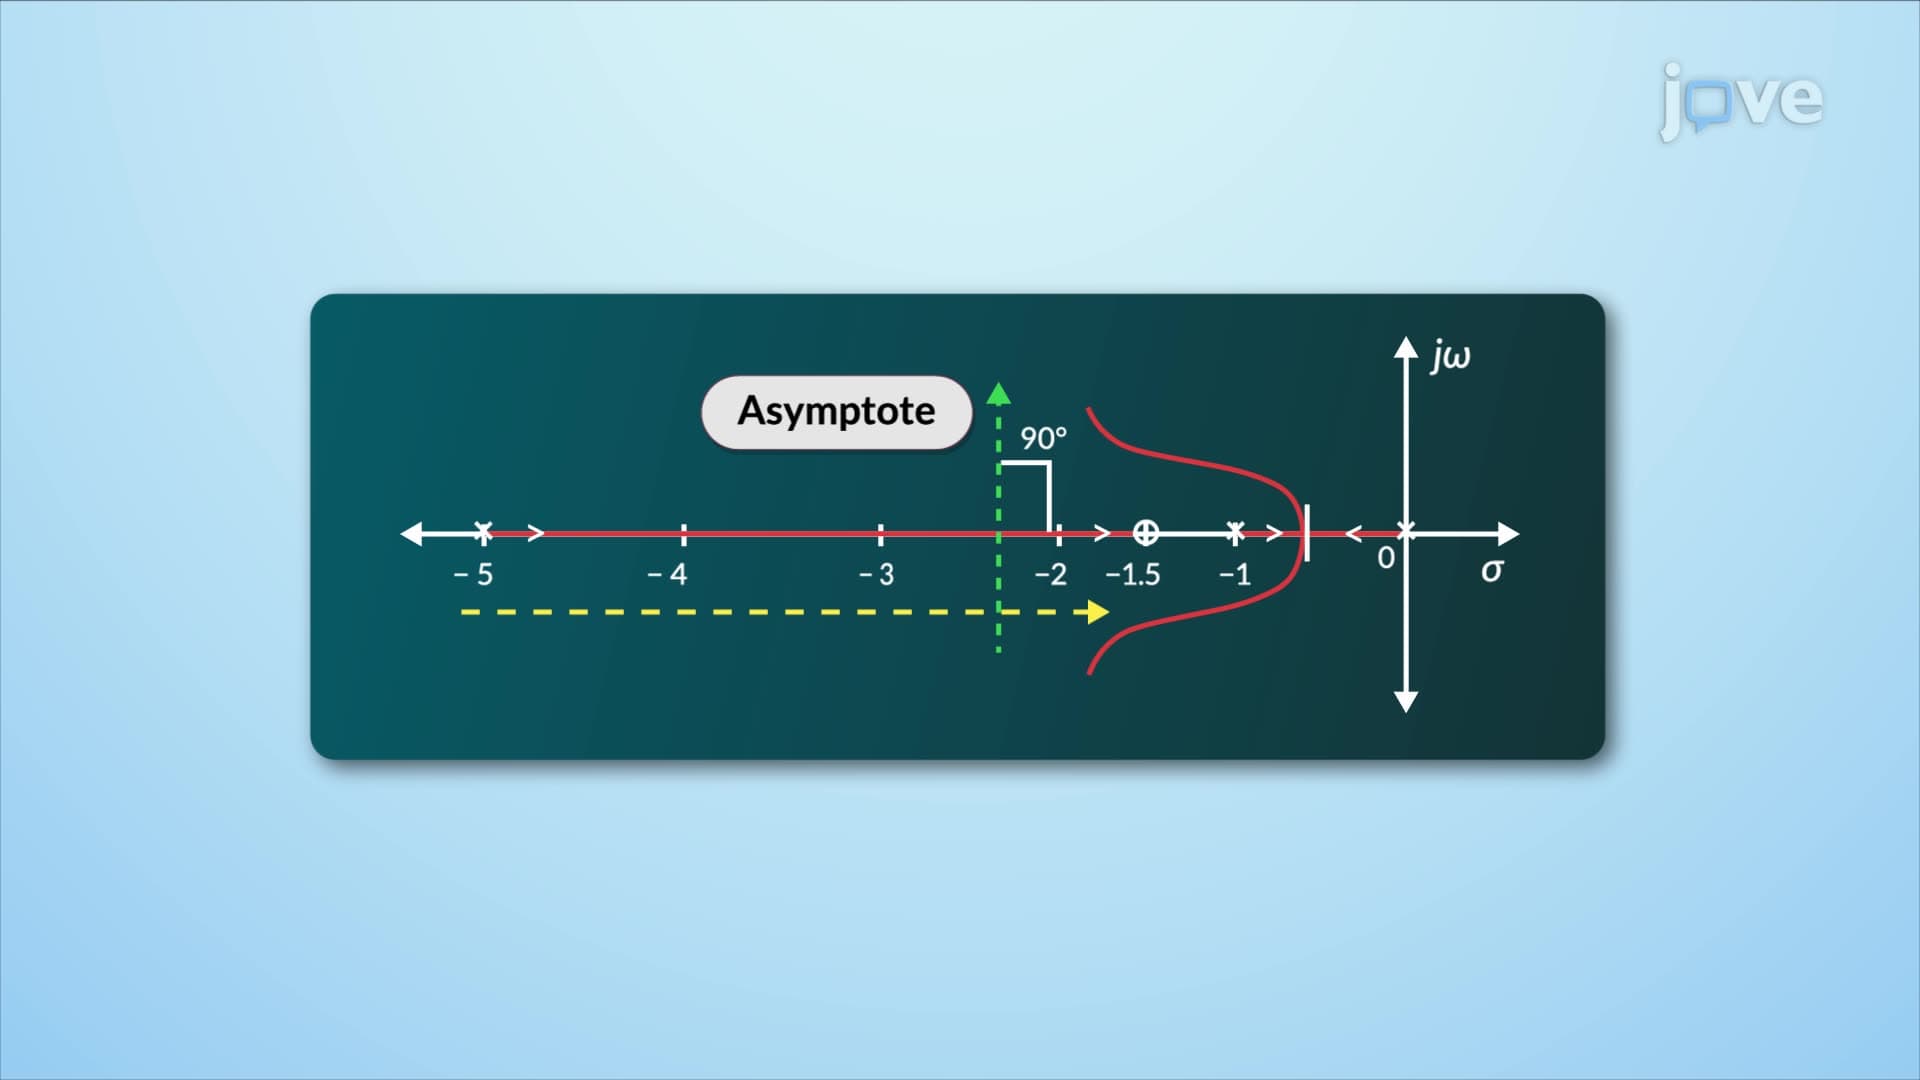
Construction of Root Locus
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain increases.
 01:19
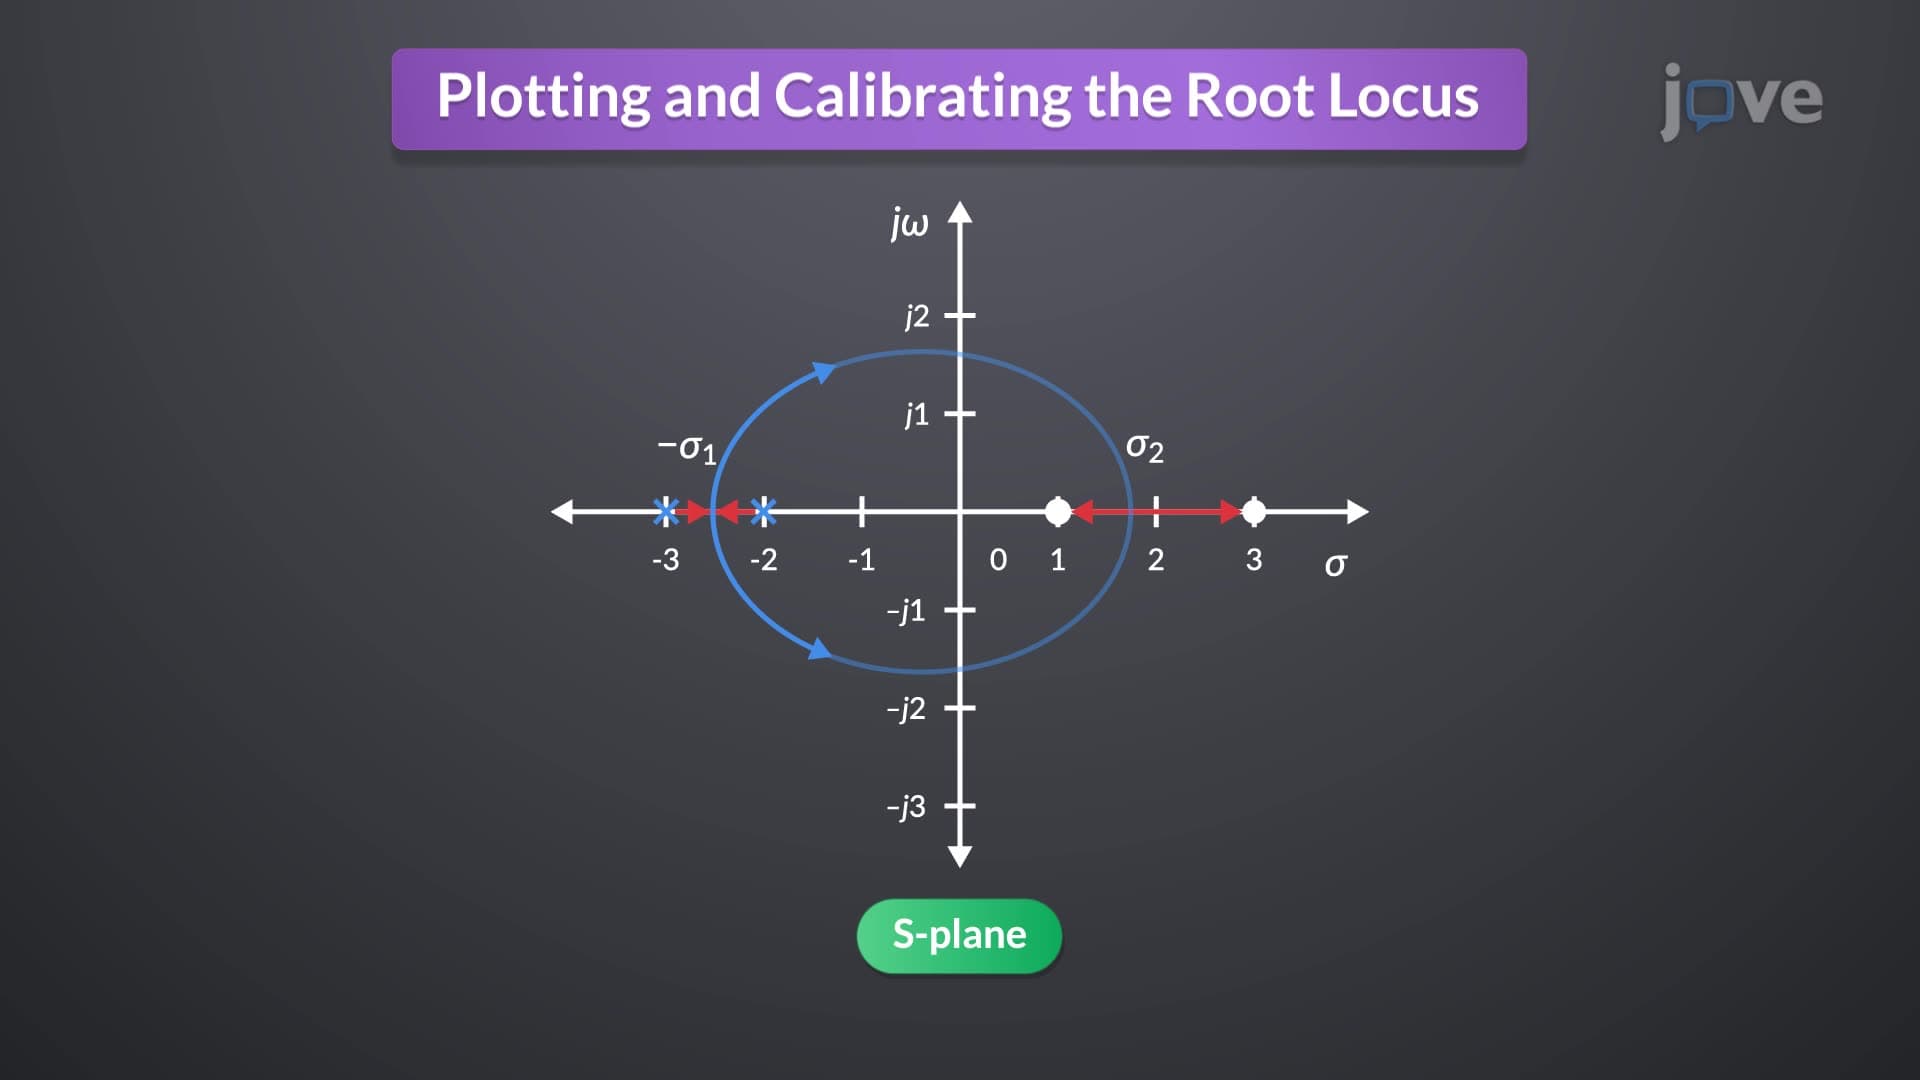
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:18
Second Order systems II
If ζ...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...