Related Experiment Video
Updated: May 28, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Residual Stress-Based Soft Robot with Capability for Grasping and Buoyancy Control
Minchae Kang1, Suyeon Seo1, Eunsol Park1
1Advanced Manufacturing & Soft Robotics Lab, Department of Mechanical Engineering, Dongguk University, 30 Pildong-ro 1, Seoul 04620, Republic of Korea.

Abstract:
Underwater soft robots offer many potential applications, including exploration, search, and rescue missions. Notably, these recently developed underwater soft robots present a safer and more adaptable alternative to rigid robots currently in use. Their flexible and deformable bodies enable them to easily adapt to challenging underwater environments and interact with diverse aquatic creatures and structures. In this paper, we present a soft buoyancy gripper that can manage buoyancy and adjust its position in the water without relying on external mechanisms. Modulating the volume of internal fluid can function both as a gripper and adjust buoyancy as needed. When buoyancy is reduced and fluid volume is minimized, the gripper can securely grasp objects, while increased fluid volume and buoyancy allow for delicate object placement. During experiments, the gripper successfully grasped and released multiple objects. When an extra channel was added, the crawling motion was achieved. The buoyancy control system demonstrates versatility and adaptability, offering the possibility of safe underwater exploration and research. Its ability to operate without harming marine environments or organisms makes it suitable for underwater research.


Related Concept Videos
 01:11
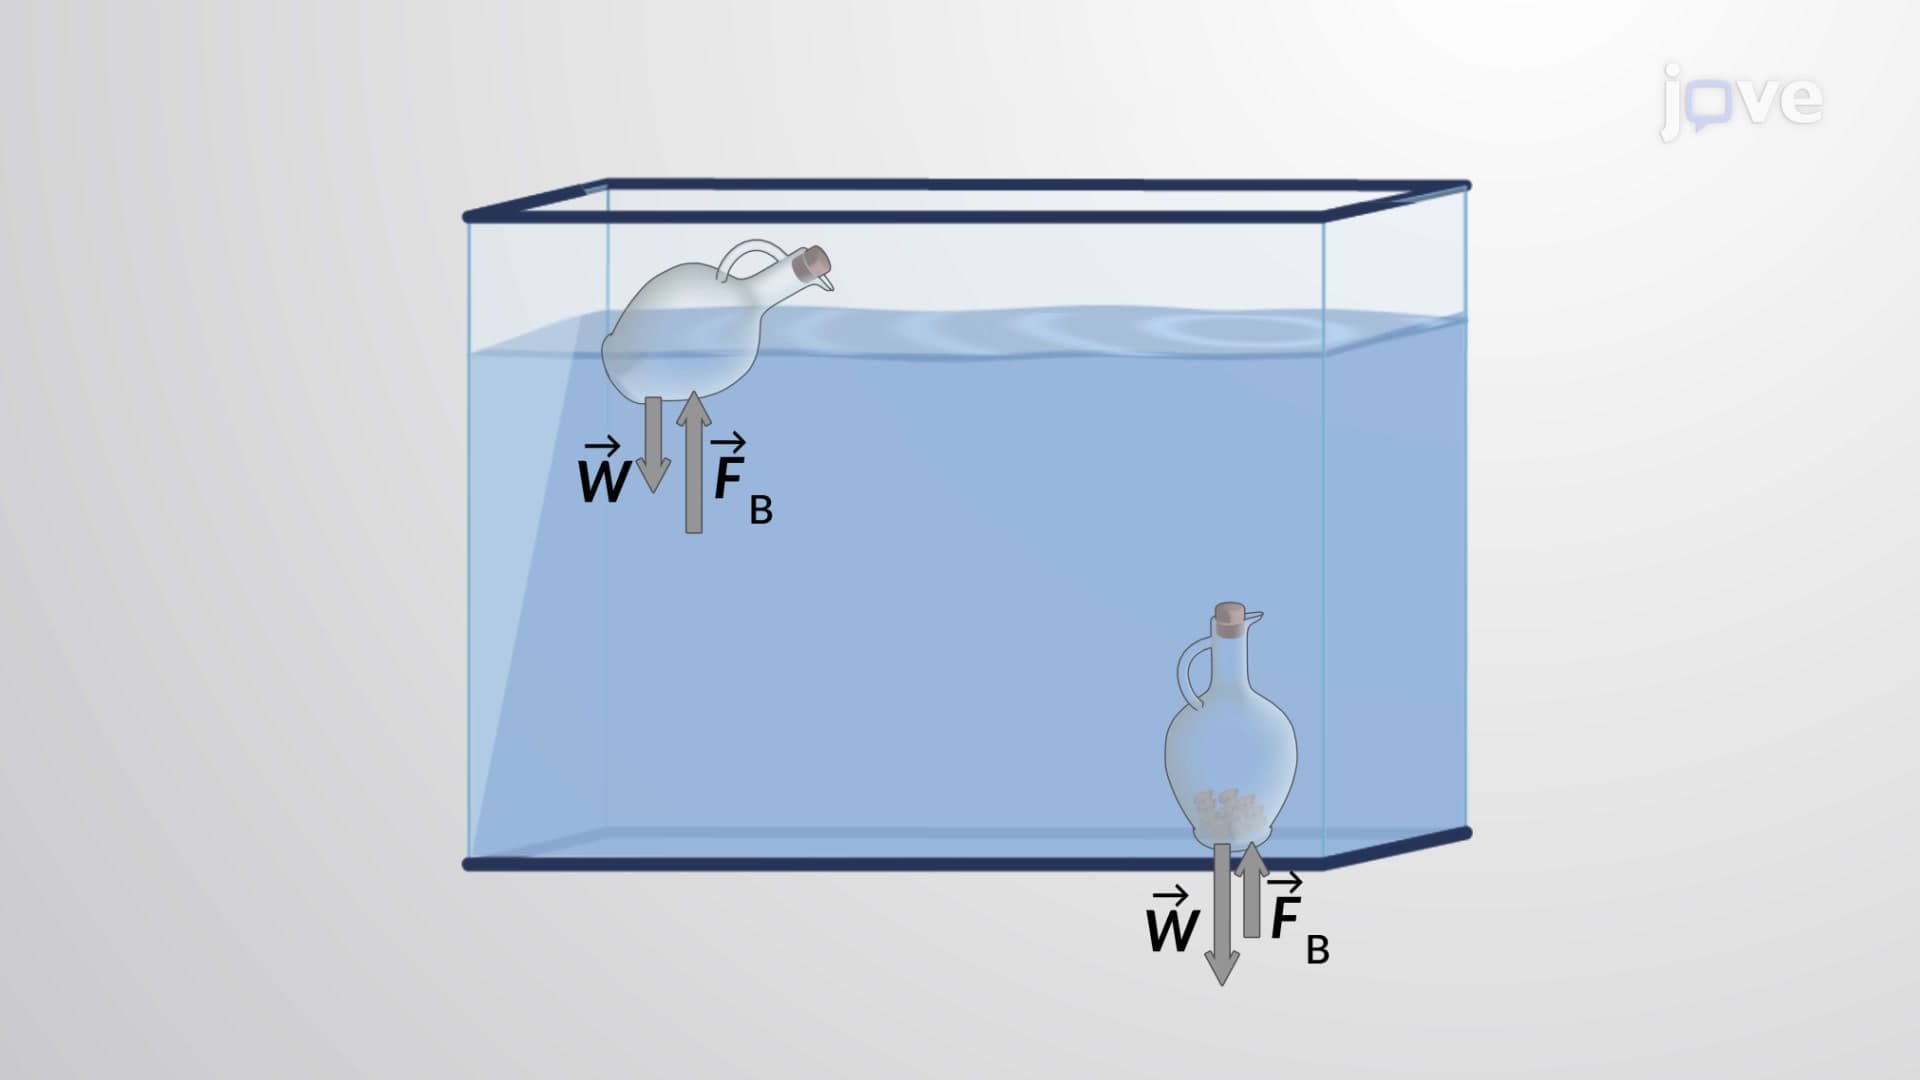
Buoyancy and Stability for Submerged and Floating Bodies
 01:12
Buoyancy
To get...
 01:11
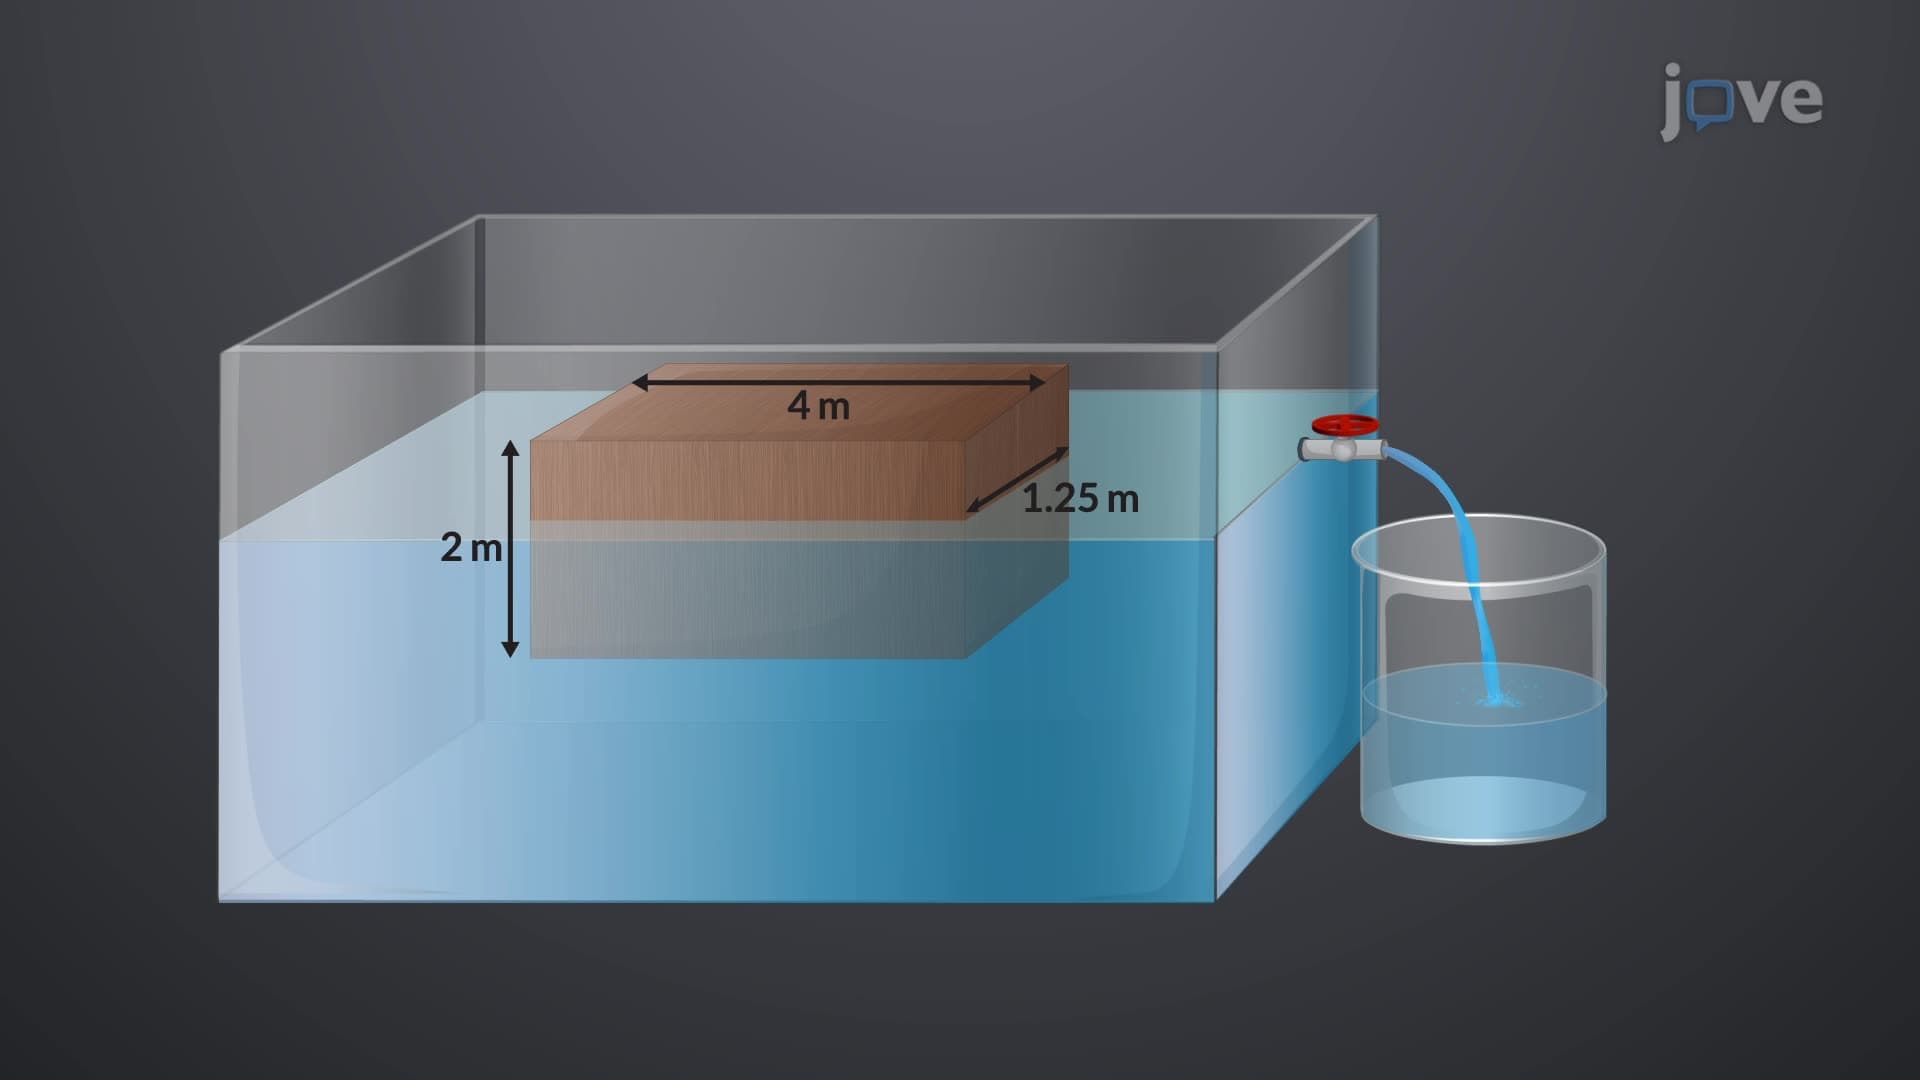
Design Example: Application of Archimedes' Principle
The volume of seawater displaced by the block is determined by first calculating the block's weight. This is done by multiplying the block's volume by...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:04
Hydrostatic Pressure Force on a Curved Surface