Related Experiment Video
Updated: Aug 6, 2026

Multimodal Cross-Device and Marker-Free Co-Registration of Preclinical Imaging Modalities
Published on: October 27, 2023
TempoCross: instance-aware sparse representation for multimodal temporal fusion in 3D detection
Changqiang Wang1, Yuanqi Liang2, Bolin Zhang1
1School of Geomatics, Liaoning Technical University, Fuxin, 123000, China.

Abstract:
With rising performance demands for autonomous driving perception systems, bird's-eye-view (BEV) perception that combines heterogeneous sensor data and temporal information has become a key research focus. Recent studies have advanced either multimodal temporal detection through BEV-level feature aggregation or sparse object-centric temporal modeling. However, integrating these two directions while preserving modality-specific temporal states remains less explored for LiDAR-camera detection. In this work, we present TempoCross, a 3D detection method based on instance-aware sparse representations for multimodal temporal fusion. TempoCross encodes features from different timestamps and sensor modalities in a unified instance space, enabling adaptive extraction of critical target information from modality- and time-specific states. Initially, both branches perform a preliminary cross-modal fusion to generate queries for the current frame. In the motion compensation module, a hybrid motion modeling strategy reduces alignment discrepancies between historical and current instances caused by complex object motion. This strategy combines explicit rigid-body transformations with implicit learnable deformation residuals, improving both accuracy and robustness in cross-frame instance association. Next, temporal-aware enhancement integrates the initial queries and current-frame features with motion-compensated historical instances. Finally, a lightweight cross-attention fuses current and historical instances from both branches. This formulation reduces the reliance on repeatedly propagating full-scene fused BEV features and concentrates temporal interaction on target-related instance states. On the nuScenes test set, TempoCross achieves 74.1% mAP and 75.7% NDS, outperforming mainstream baseline detectors. The results support the effectiveness of combining LiDAR-camera fusion with instance-aware sparse temporal modeling.
Related Concept Videos
 01:05
Collisions in Multiple Dimensions: Introduction
 01:25
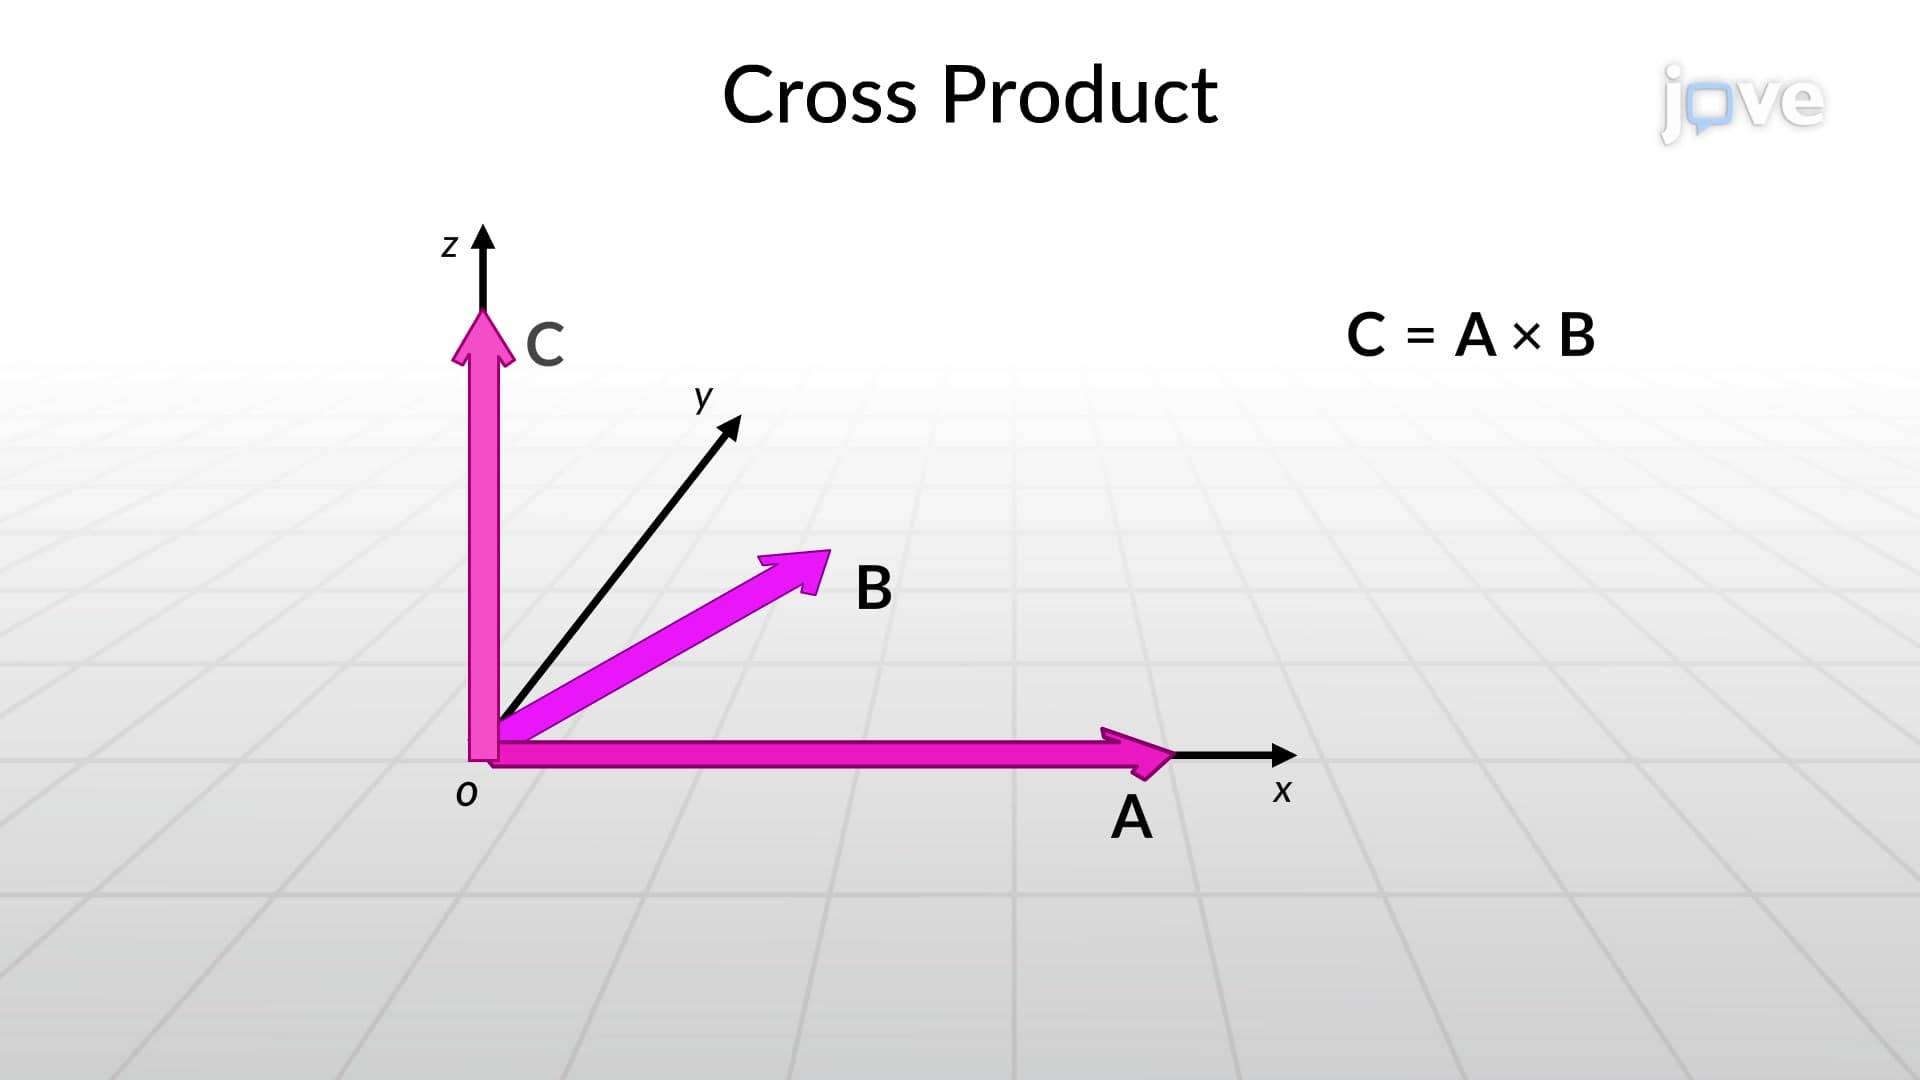
Cross Product
The magnitude of the cross product is obtained by multiplying the magnitude of both the vectors and the sine of the angle between them. This means that a larger angle between the vectors will lead to a greater magnitude of the cross product.
 01:17
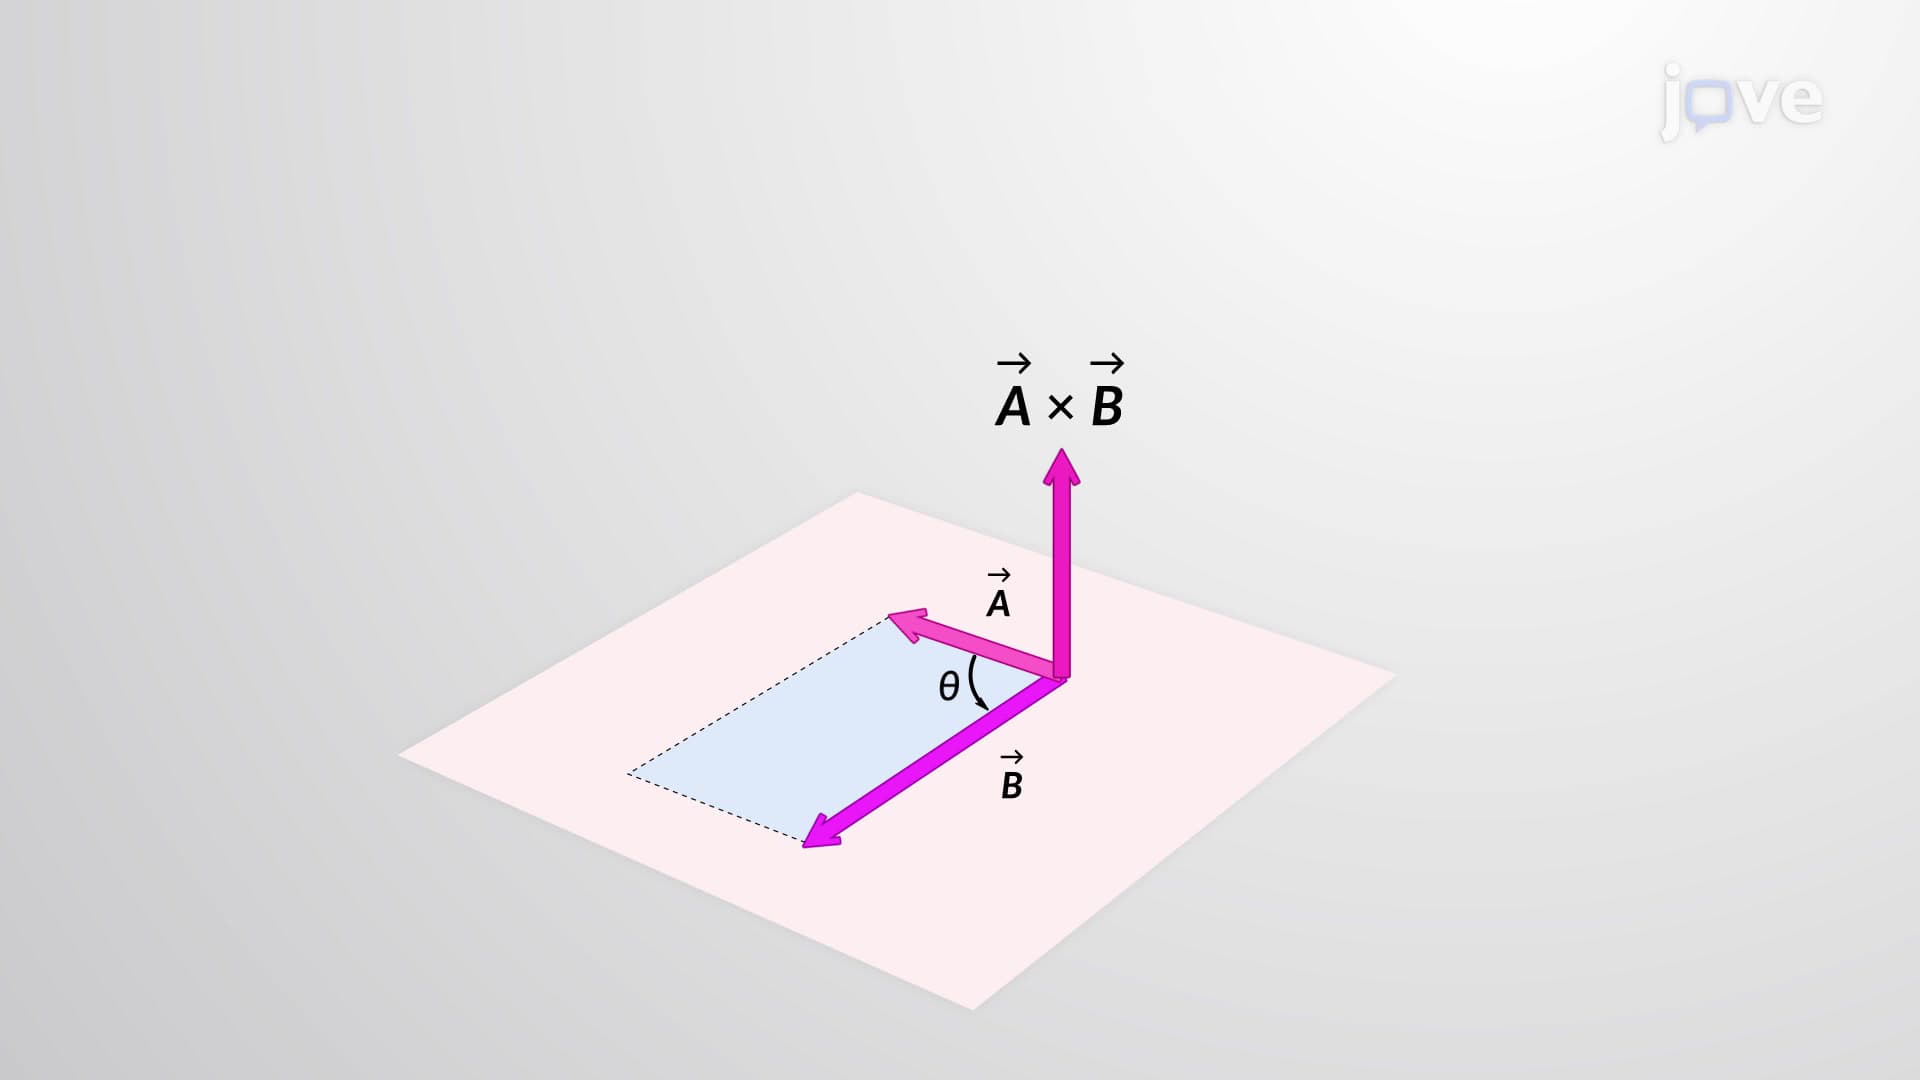
Vector or Cross Product
Consider the cross product of two vectors. Imagine rotating the first vector about...
 01:27
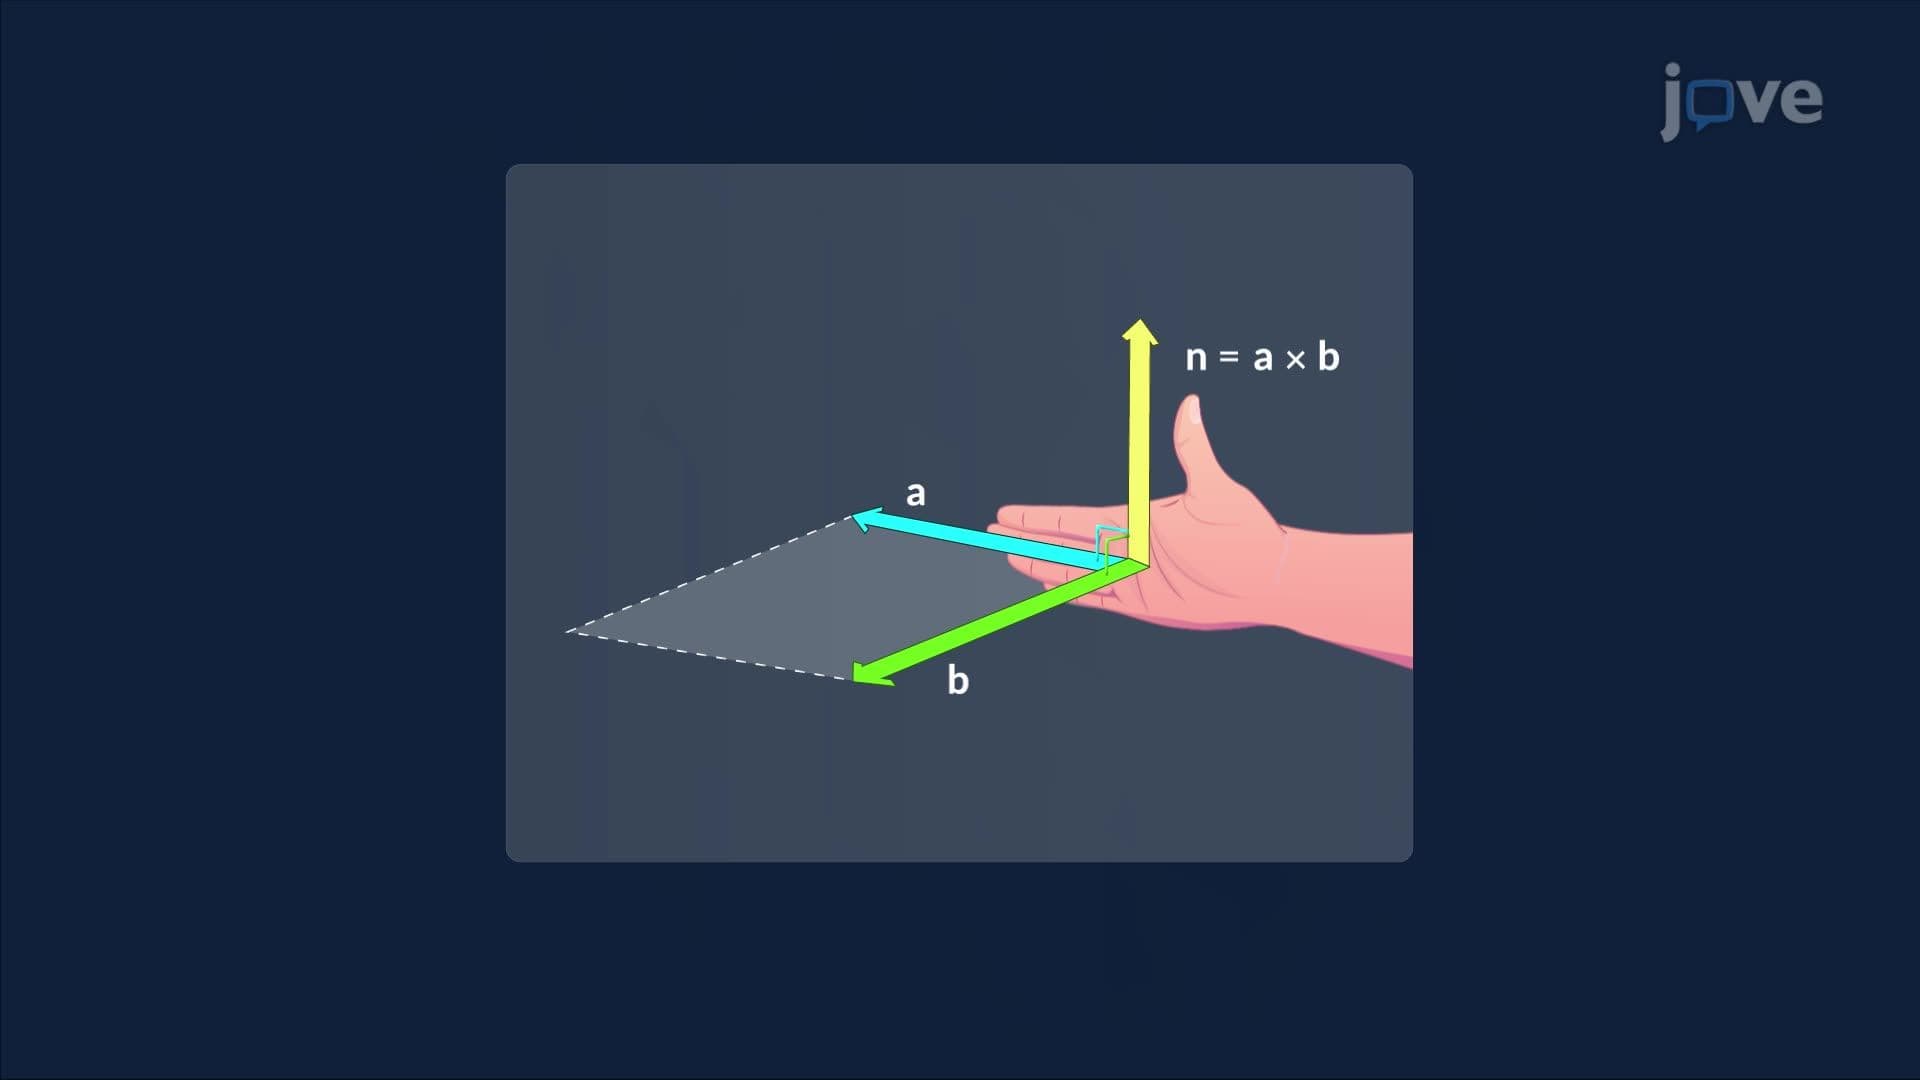
Cross Product and Its Geometry
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...