Related Experiment Video
Updated: Aug 5, 2026
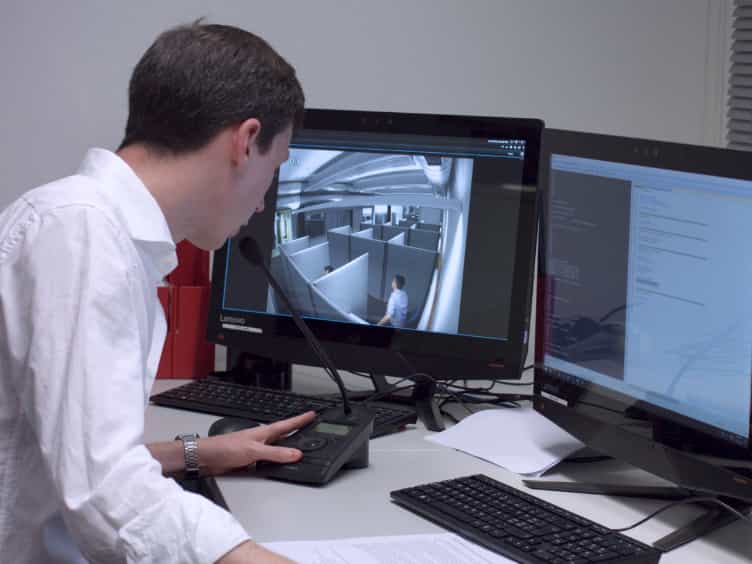

A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
EA-AHS: A Perception-Driven Adaptive Heuristic Framework for Real-Time UAV Path Planning in Complex Urban
Ruijie Song1, Haohan Zhang2, Xianghua Zeng1
1School of Earth Sciences and Engineering, Hohai University, Nanjing 210098, China.

Abstract:
With the progressive opening of urban low-altitude airspace, drone applications increasingly rely on real-time environmental perception for safe navigation in complex, obstacle-dense environments. Traditional planning algorithms struggle to efficiently process spatially heterogeneous sensor data, leading to computational bottlenecks and unsafe trajectories. To bridge raw perception and agile decision-making, we propose an Environment-Aware Adaptive Heuristic Search (EA-AHS) framework that translates local obstacle density into adaptive heuristic weights via a sliding window, while a historical feedback loop enables macro-level parameter adaptation. Experiments demonstrate that EA-AHS reduces planning time by 87.9% in a simple maze and by 81.0% in a complex point-block map compared to standard A*. In a 3D urban scenario, EA-AHS trades a modest computational overhead for substantial safety gains: its cumulative risk is only 48% of that of standard A* and 57% of that of weighted A*, and its minimum obstacle distance increases to 6.04 m. Unlike learning-based methods, EA-AHS requires no pre-training or neural inference, offering a highly practical, lightweight solution for resource-constrained onboard sensor systems.
Related Concept Videos
 01:42
Schemas
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:29
Application of Linearization and Approximation
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...