Related Experiment Video
Updated: Aug 9, 2026
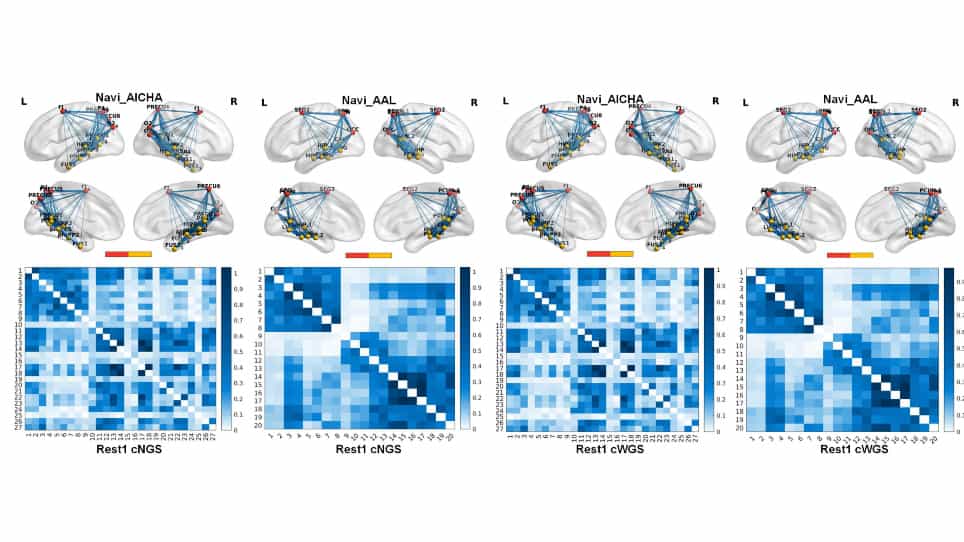

Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
Benchmark evaluation in task and motion planning using iteratively deepened AND/OR graph networks
Hossein Karami1, Antony Thomas2, Fulvio Mastrogiovanni1
1Department of Informatics, Bioengineering, Robotics, and Systems Engineering, University of Genoa, Genoa, Italy.

Abstract:
In robotics research, each subdomain presents a distinct set of challenges, and any framework designed for a given domain must effectively address these complexities. However, a single application within that domain may not fully capture the breadth of challenges inherent to it. To enable systematic and comprehensive evaluation, the robotics community has developed standardized problem scenarios and associated performance metrics, commonly referred to as benchmarks, which collectively represent the diverse challenges arising across applications. In this work, we evaluate our task-motion Planning (TMP) framework on five benchmarks proposed by the TMP community. We begin by briefly describing our iterative deepening AND/OR graph-based TMP planner. Subsequently, we assess its performance across these benchmarks, each designed to capture different aspects of the challenges in TMP. The evaluation demonstrates that the proposed planner successfully solves all five benchmarks, thereby indicating that our framework constitutes a robust and effective solution for TMP.