Related Experiment Video
Updated: Aug 5, 2026
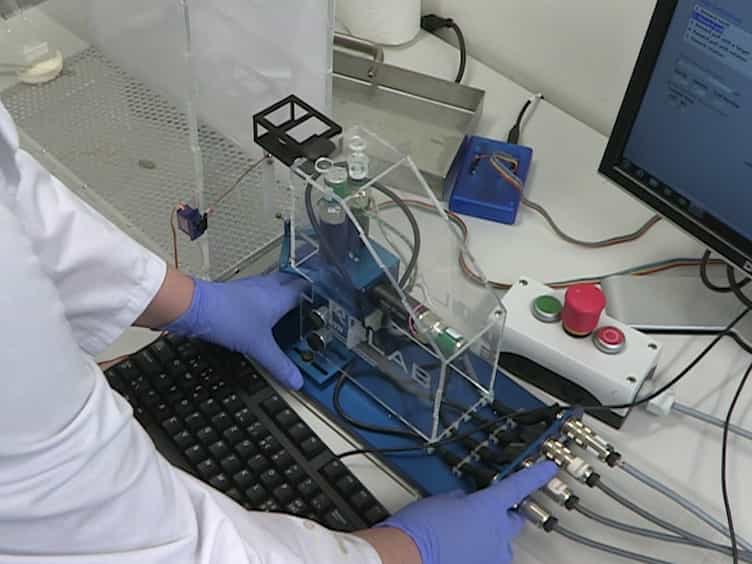
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Object-centric diffusion policies for real-world robotic-arm imitation learning
Prashant Reddy Kasu1, Dugan Um2
1College of Computer Science and Engineering, Computer Science, Texas A&M University - Corpus Christi, Corpus Christi, TX, United States.

Abstract:
Imitation learning in complex, unstructured environments remains challenging due to the difficulty of grounding perception in physically meaningful representations and the need to model multimodal action distributions. Existing approaches often rely on unstructured pixel-level feature encodings or stochastic latent-variable decoders, which can lead to brittle attention in cluttered scenes. In this work, we present a novel integration of detector-based visual representations with conditional diffusion modeling (DINO + CDP) for real-world robotic imitation learning. Our framework utilizes a DINO object detection transformer to extract spatially-grounded object-query embeddings that serve as the conditioning signal for a diffusion-based policy. A primary contribution of this work is the systematic quantification of how scene complexity-measured via image entropy-affects robotic policy performance. By comparing rigid-object baselines with complex biological plant scenes, we demonstrate that organic morphology induces a measurable increase in pixel-level uncertainty that degrades standard pixel-centric models. Our results show that DINO + CDP mitigates this degradation by grounding action generation in stable object-level features. We evaluate our approach using a fully real-world manipulation dataset collected without simulation or synthetic pre-training. To isolate the impact of our architectural choices, we conduct a comparative study within a unified framework against convolutional (CNN-MLP), transformer-patch (ViT), and latent-variable (DETR + CVAE) variants. Experimental results in a robotic-arm biocell setup demonstrate that object-query-conditioned diffusion significantly improves task success rates, produces smoother trajectories, and exhibits superior robustness to high-entropy visual inputs, establishing a scalable pathway for imitation learning in challenging agricultural domains.
Related Concept Videos
 01:12
Observational Learning
 01:22
Purposive Learning
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:18
Hierarchy of Motor Control
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...