Related Experiment Video
Updated: Sep 18, 2026


Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle (Mercynorrhina torquata)
Published on: September 2, 2016
Hybrid Model-Based and Data-Driven Trajectory Tracking Control for Flapping-Wing Microaerial Vehicles

Abstract:
Trajectory tracking for flapping-wing microaerial vehicles (FWMAVs) is challenging due to inherent nonlinear dynamics and unsteady aerodynamics. While incremental model predictive control (IMPC) effectively manages constraints, its reliance on fixed weighting matrices limits performance during aggressive maneuvers. Conversely, reinforcement learning (RL) offers adaptability but lacks necessary stability guarantees. To address this, we propose a hybrid RL-based IMPC (RLIMPC) architecture. We first establish a quasi-steady aerodynamic model using blade element theory to improve dynamic fidelity. The proposed framework then integrates IMPC as a low-level controller for constraint satisfaction, while a high-level RL agent dynamically optimizes the IMPC weighting matrices in real time. This hierarchical approach compensates for linearization errors and adapts to varying flight envelopes. Validation results demonstrate that RLIMPC outperforms fixed-weight schemes in tracking accuracy, robustness, and control smoothness.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
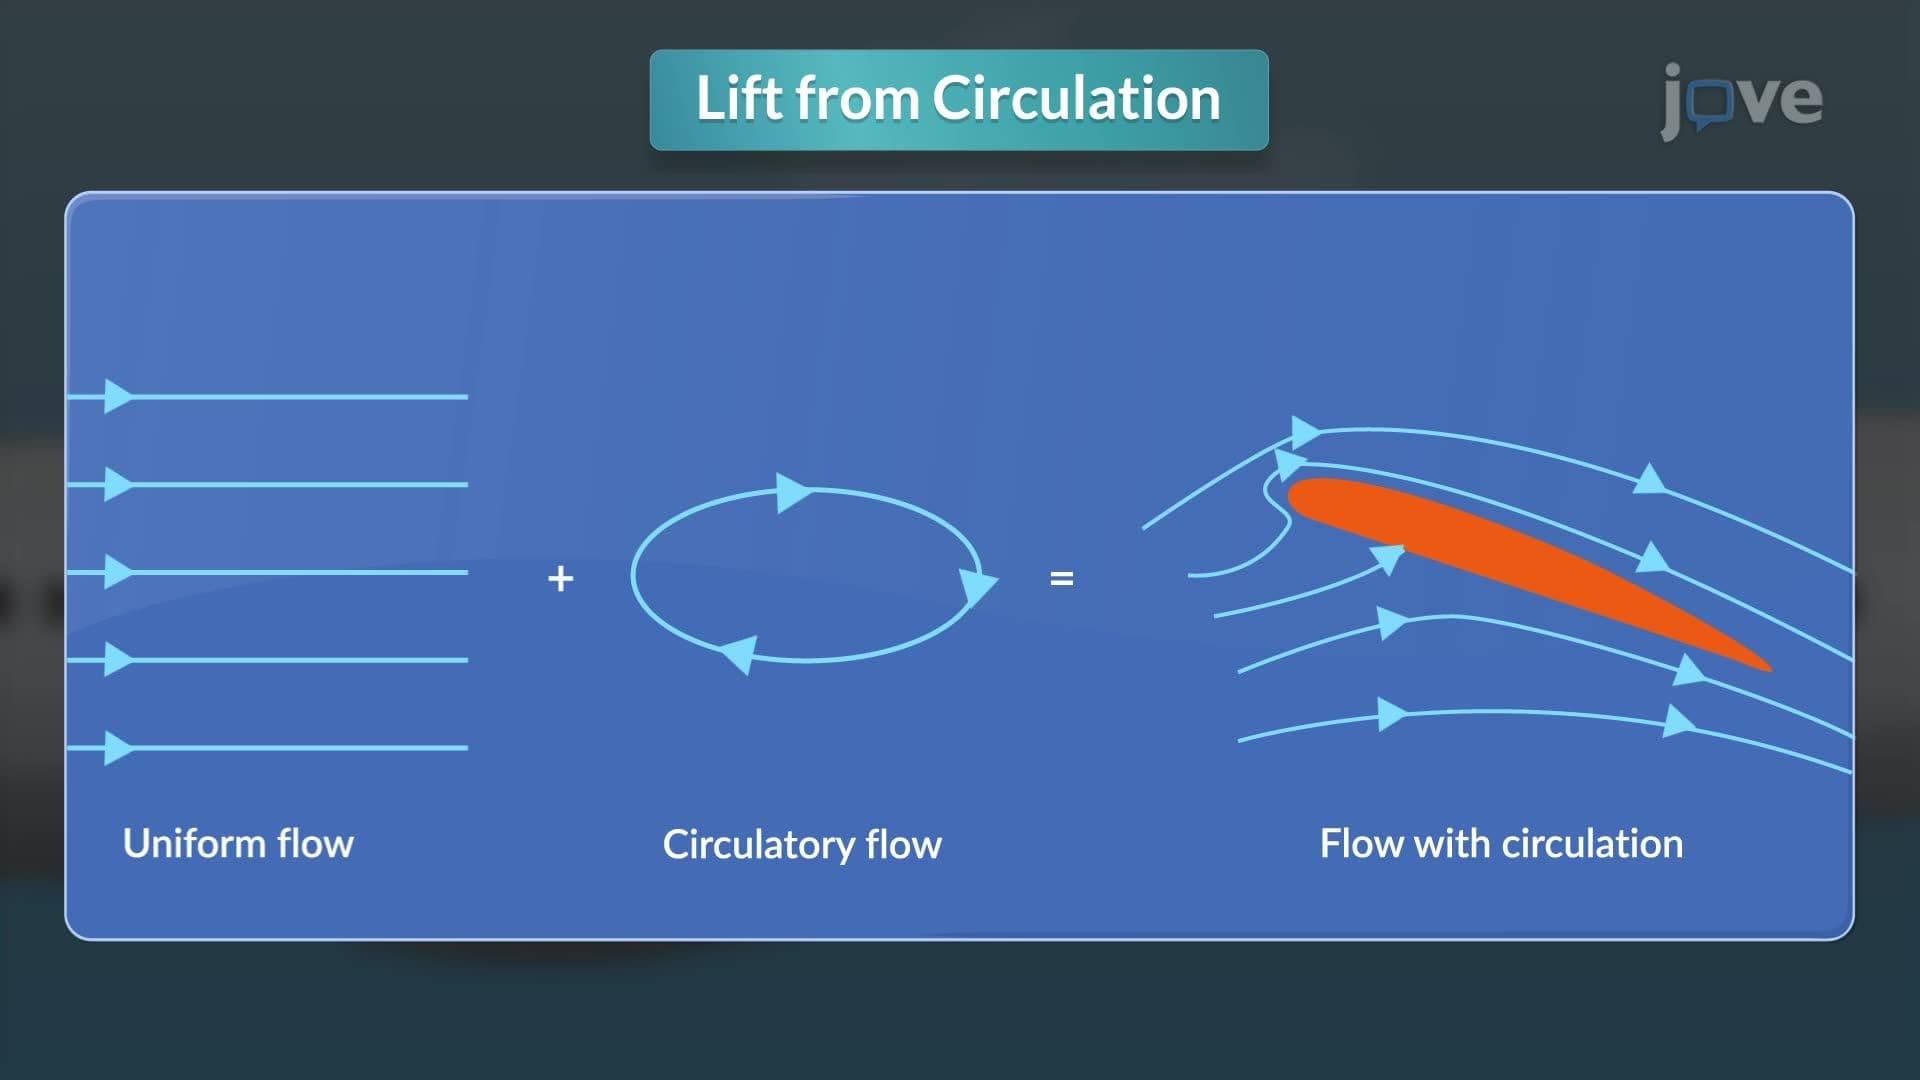
Lift
 01:29
Application of Linearization and Approximation
 01:13
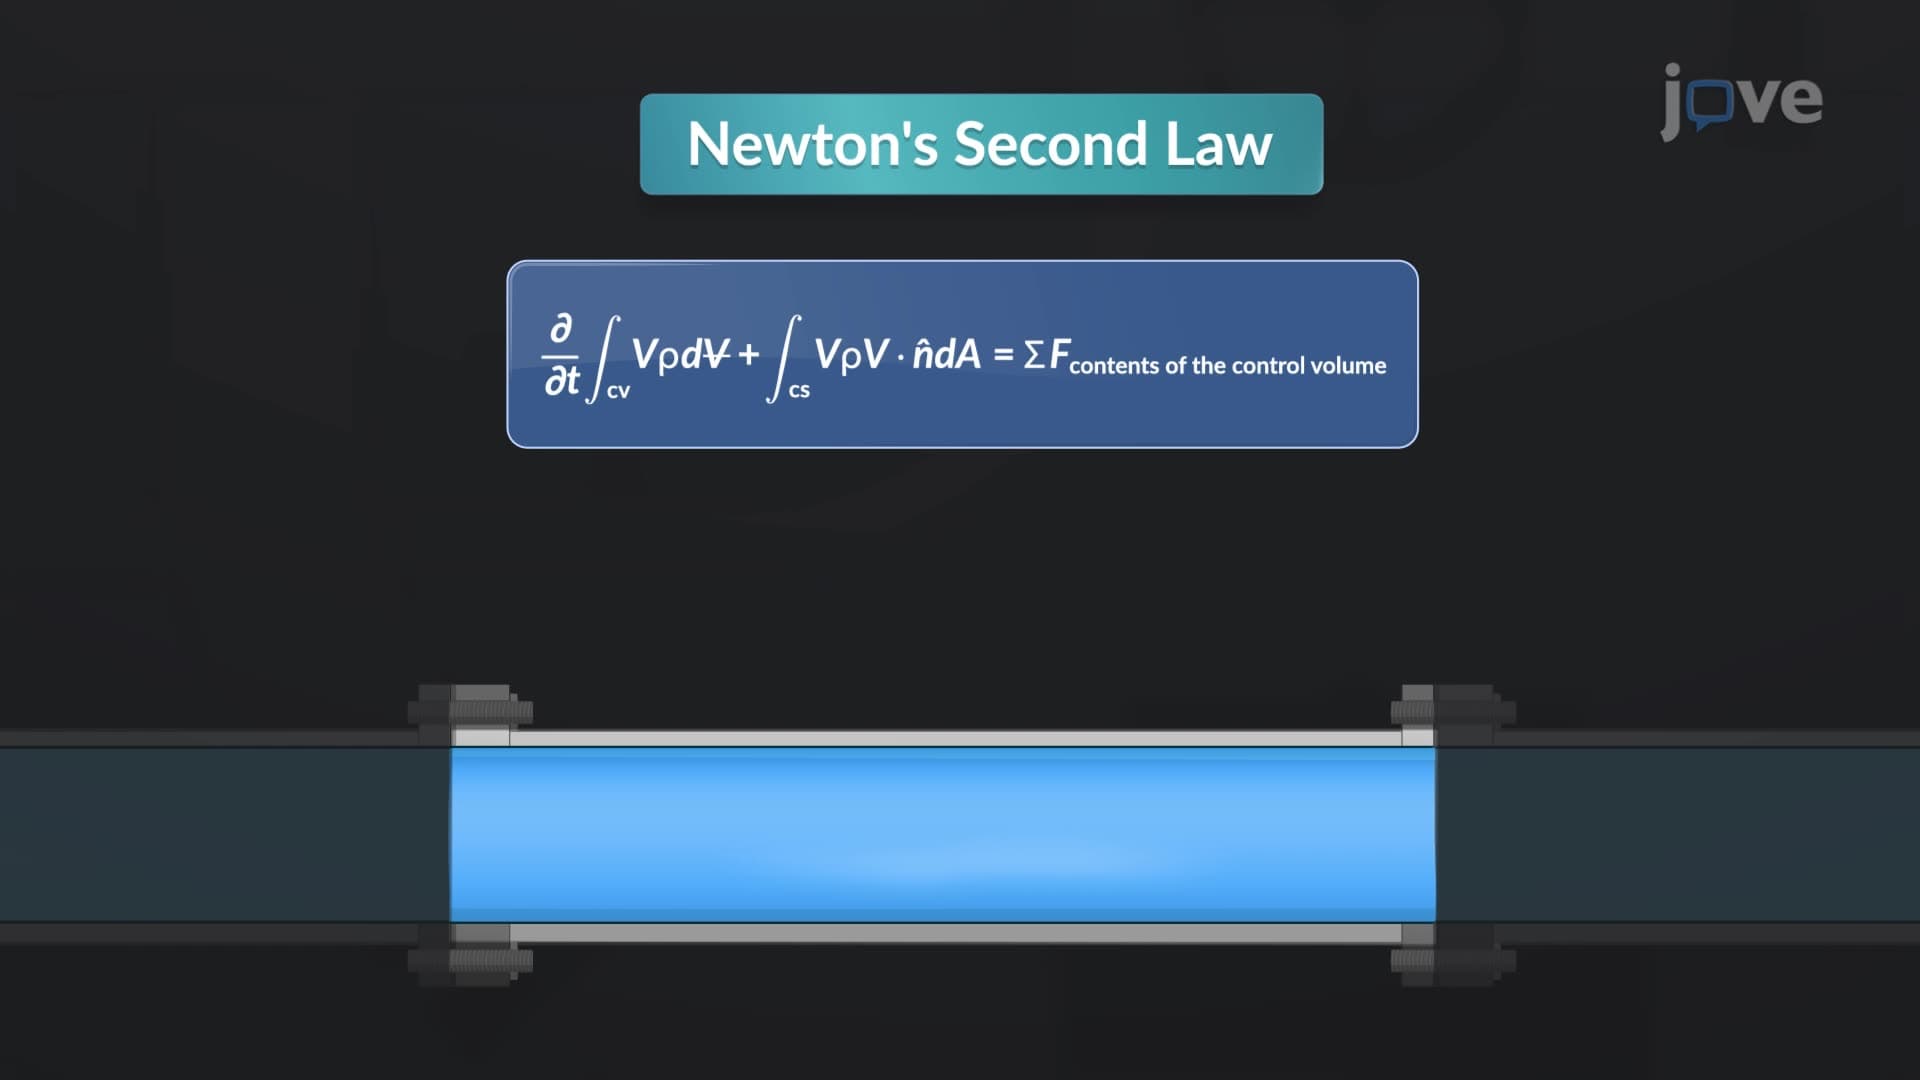
Linear Momentum in Control Volume
 01:11
Velocity and Acceleration in Steady and Unsteady Flow
The acceleration can be generalized to any point in the flow, and expressed as components along three perpendicular directions, representing changes in velocity over time.