Related Experiment Video
Updated: Apr 25, 2026
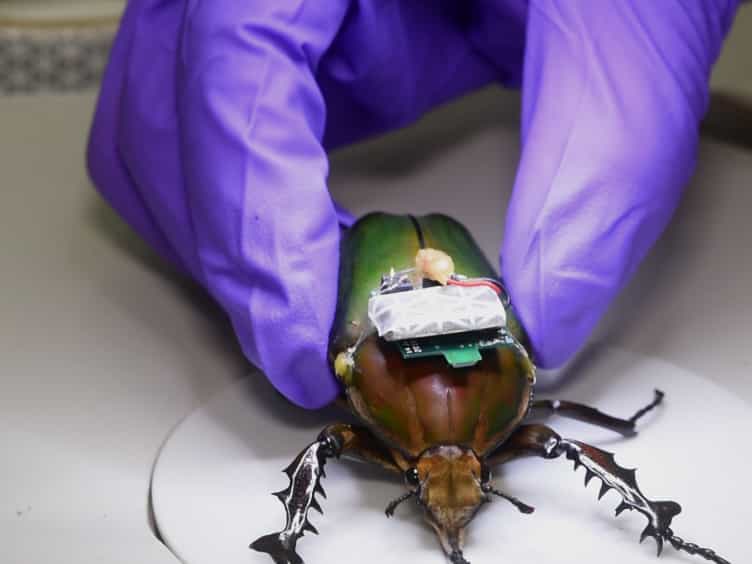

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Robust image-based control for aerial interaction under external disturbances
Junhao Zeng1, Hang Zhong2, Jiacheng Liang1
1College of Electrical and Information Engineering, Hunan University, No. 2 Lushan Road, Changsha, 410082, China; National Engineering Research Center for Robot Visual Perception and Control Technology, Changsha, 410082, China.

Abstract:
This paper proposes a robust image-based control framework for an aerial manipulator (AM) performing infrastructure contact inspection under strong coupling, uncertainties, and external disturbances. A decoupled second-order image dynamics model is derived from virtual-camera image moments. Building on this model, a disturbance observer-based nonlinear model predictive controller (NMPC) is developed to generate position commands, where disturbances are estimated online, and both physical limits and visibility constraints are explicitly enforced. To achieve reliable force interaction, an image-based first-order variable-stiffness impedance controller is designed for contact-direction force-tracking, and a geometric attitude controller based on a commanded filter is adopted to avoid Euler angle singularities. Simulation and experimental results demonstrate improved tracking accuracy and robustness. The contact force RMSE is reduced by 31.6% compared with a representative robust NMPC baseline in simulation, and by 58.3% compared with a hybrid visual compliant baseline in experiments, across nine repeated trials; the average force RMSE reduction reaches 52.9%. These results verify the force-tracking accuracy and reproducibility of the proposed framework in aerial physical interaction (APhI) tasks.


Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:10
Control Systems
At the heart...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...