Related Experiment Videos
Maximizing mutual information in multi-view representation learning for next POI prediction
Tuohang Li1, Jiajing Yu2, Jianyong Zhao2
1School of Computing and Artificial Intelligence, Southwestern University of Finance and Economics, Chengdu, China; Kash Institute of Electronics and Information Industry, Kashi, China.

Abstract:
Next point-of-interest (POI) prediction is a fundamental task in spatiotemporal data mining, aiming to facilitate personalized location-based services through modeling individual mobility trajectories. Despite recent advances in deep neural networks for capturing human mobility patterns from both short- and long-term trajectories, accurate POI prediction remains challenging due to the fragility of short-term intent representations and user preference drift. These challenges arise from intent inconsistency between stable long-term behavioral patterns and transient short-term contingencies, as well as the inherent stochasticity induced by sparse, noisy, and exploratory human mobility trajectories, ultimately causing biased or unstable future intention predictions. In this study, we propose MVMI, a Multi-View representation learning framework based on Mutual Information for next POI prediction. To improve the robustness of short-term intent representations, MVMI decomposes short-term trajectories into instantaneous and context-dependent intents and employs a Gaussian perturbation-based multi-view augmentation strategy to enhance the robustness of short-term intent representations against trajectory stochasticity. To address user preference drift, MVMI further introduces a mutual information (MI) constraint that aligns integrated user preferences with the ground-truth future intentions, where a dual-task learning paradigm is employed to enforce hierarchical spatial constraints at both the POI and region levels. Finally, experiments on four real-world datasets demonstrate that MVMI significantly outperforms representative baselines.
Related Concept Videos
 01:25
Maximizing the Directional Derivative
 01:28
Lagrange Multipliers: Two Constraints
 01:07
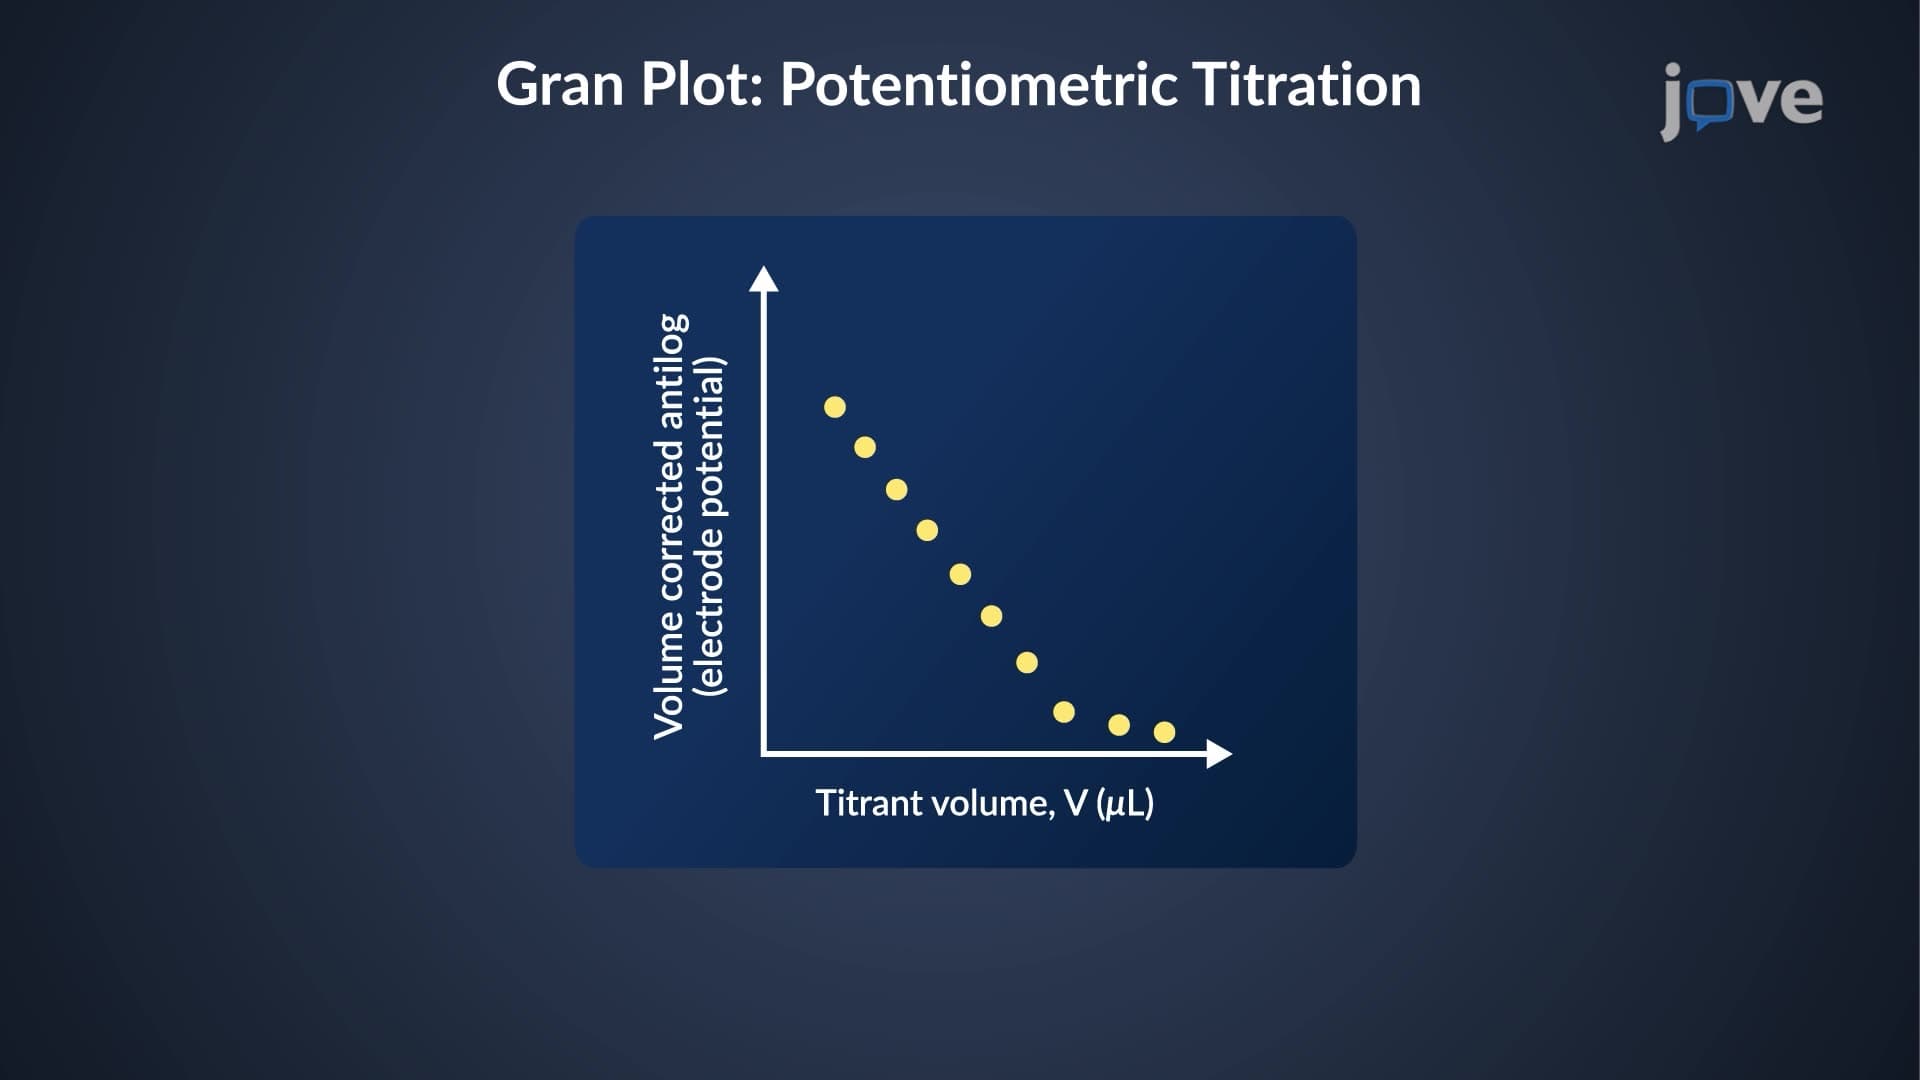
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting the...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:31
Local Maximum and Minimum Values