Related Experiment Video
Updated: Oct 22, 2026
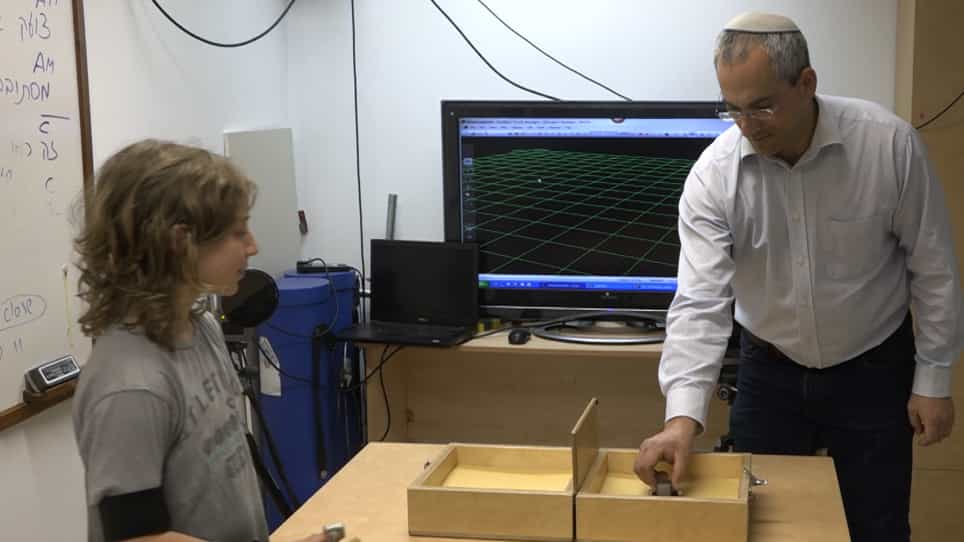
Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Pseudo-Haptic Feedback: Multi-Modal Approaches to Stiffness Perception and User Experience
Mehmet Ege Cansev1, Xiaodong Sun2, Gionata Salvietti3
1Chair of Autonomous Systems and Mechatronics, Department of Electrical Engineering, Friedrich-Alexander-Universität Erlangen-Nürnberg, Erlangen, Germany.

Abstract:
Pseudo-haptics is a technique that creates the illusion of haptic sensations in virtual environments by leveraging visual feedback and the interplay between visual and haptic perception. Pseudo-haptic feedback can enhance virtual reality interactions by providing perceptual cues that substitute for or complement physical haptic feedback. This work extends a 3D deformation rendering approach to generate visual deformation cues for stiffness perception in virtual reality and evaluates their impact on user experience through a user study measuring presence and workload. Results from a user study ( ) indicate that deformation cues support stiffness perception at levels comparable to physical haptic feedback in both objective and subjective measures. Combining pseudo-haptic and force feedback further enhances stiffness perception accuracy and presence without increasing workload. These findings demonstrate that well-designed pseudo-haptic feedback mechanisms can effectively complement or substitute for force feedback in virtual reality interactions.
Related Concept Videos
 01:15
Sensory Modalities
General senses refer to the broad category of sensory information detected by receptors in the body and can be further grouped into somatic and visceral senses. Somatic sensations include touch, pressure, temperature, and pain and are essential for navigating our environment and...
 01:26
Introduction to Special Senses