Related Experiment Video
Updated: Aug 30, 2026

Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
Robot-assisted placement of craniofacial implants
Martin Klein1, Andreas Hein, Tim Lueth
1Clinic for Maxillofacial Sugery-Clinical Navigation and Robotics, Charité University Medicine, Campus Virchow Clinic, Berlin, Germany. martin.klein@charite.de

Purpose:
The purpose of this study was to improve and accelerate the rehabilitation process for patients with severe ear microtia with an implant-anchored auricular prosthesis. A medically approved robot system was used to place the craniofacial implants and a new process was developed for preoperative fabrication of the prosthesis using a rapid prototyping technique.
Materials And Methods:
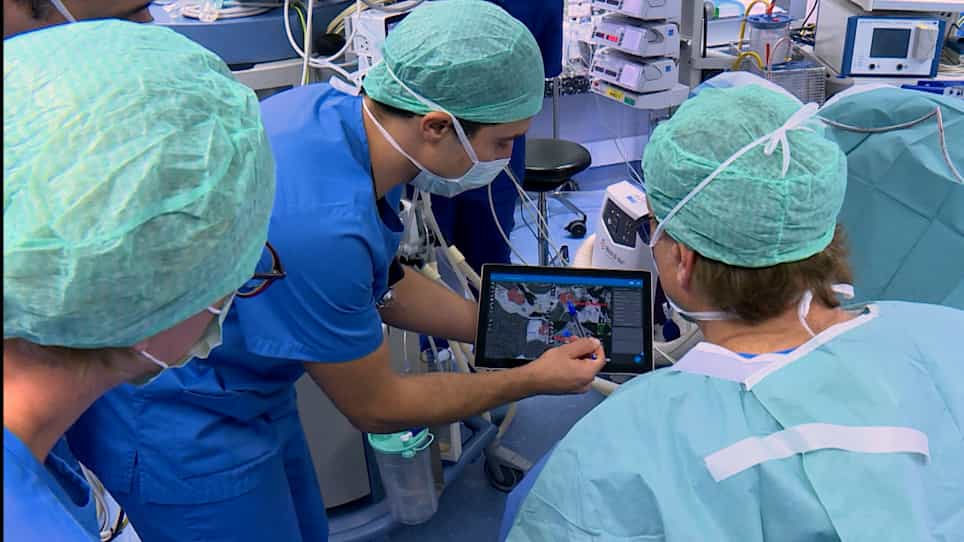
Preoperatively, after computerized tomography, the implant positions were determined in a planning tool according to bone availability and esthetic considerations. Intraoperatively, the robot showed the surgeon the planned implant positions and guided the placement procedure.
Results:
The accuracy measurements showed that with this robot system, absolute implant position accuracy of approximately -0.5 +/- 0.4 mm, a relative accuracy between the implants of approximately 0.2 +/- 0.5 mm, and a deviation from the parallel position of approximately 0.6 +/- 0.5 degrees were achieved. Thirty implants were placed in 13 patients with robot assistance with no intraoperative injuries.
Discussion:
This technique made it possible to apply the preoperatively fabricated auricular prosthesis directly after surgery.
Conclusion:
From this experience it can be concluded that the robot system and the new manufacturing concept for anaplastology can be applied advantageously in other areas of the head as well.