Related Experiment Video
Updated: Aug 7, 2026

Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Intelligent compensation of friction, ripple, and hysteresis via a regulated chatter
1Department of Electrical and Computer Engineering, National University of Singapore.

Abstract:
In this paper, a hybrid control scheme utilizing a PID feedback control with an additional regulated chatter signal is developed to compensate motion impeding influences such as the effects due to friction, force ripples, and hysteresis in linear piezoelectric motor. The regulated chatter signal is a pulse sequence superimposed on the PID control signal. It has a fixed amplitude, and a pulse width regulated via iterative learning control. As such, the scheme is expected to be useful for applications involving iterative motion sequences. An analysis of the closed-loop performance is presented in the paper. Simulation and experimental results are also furnished to demonstrate that the proposed control scheme can reduce tracking errors significantly.
Related Concept Videos
 01:14
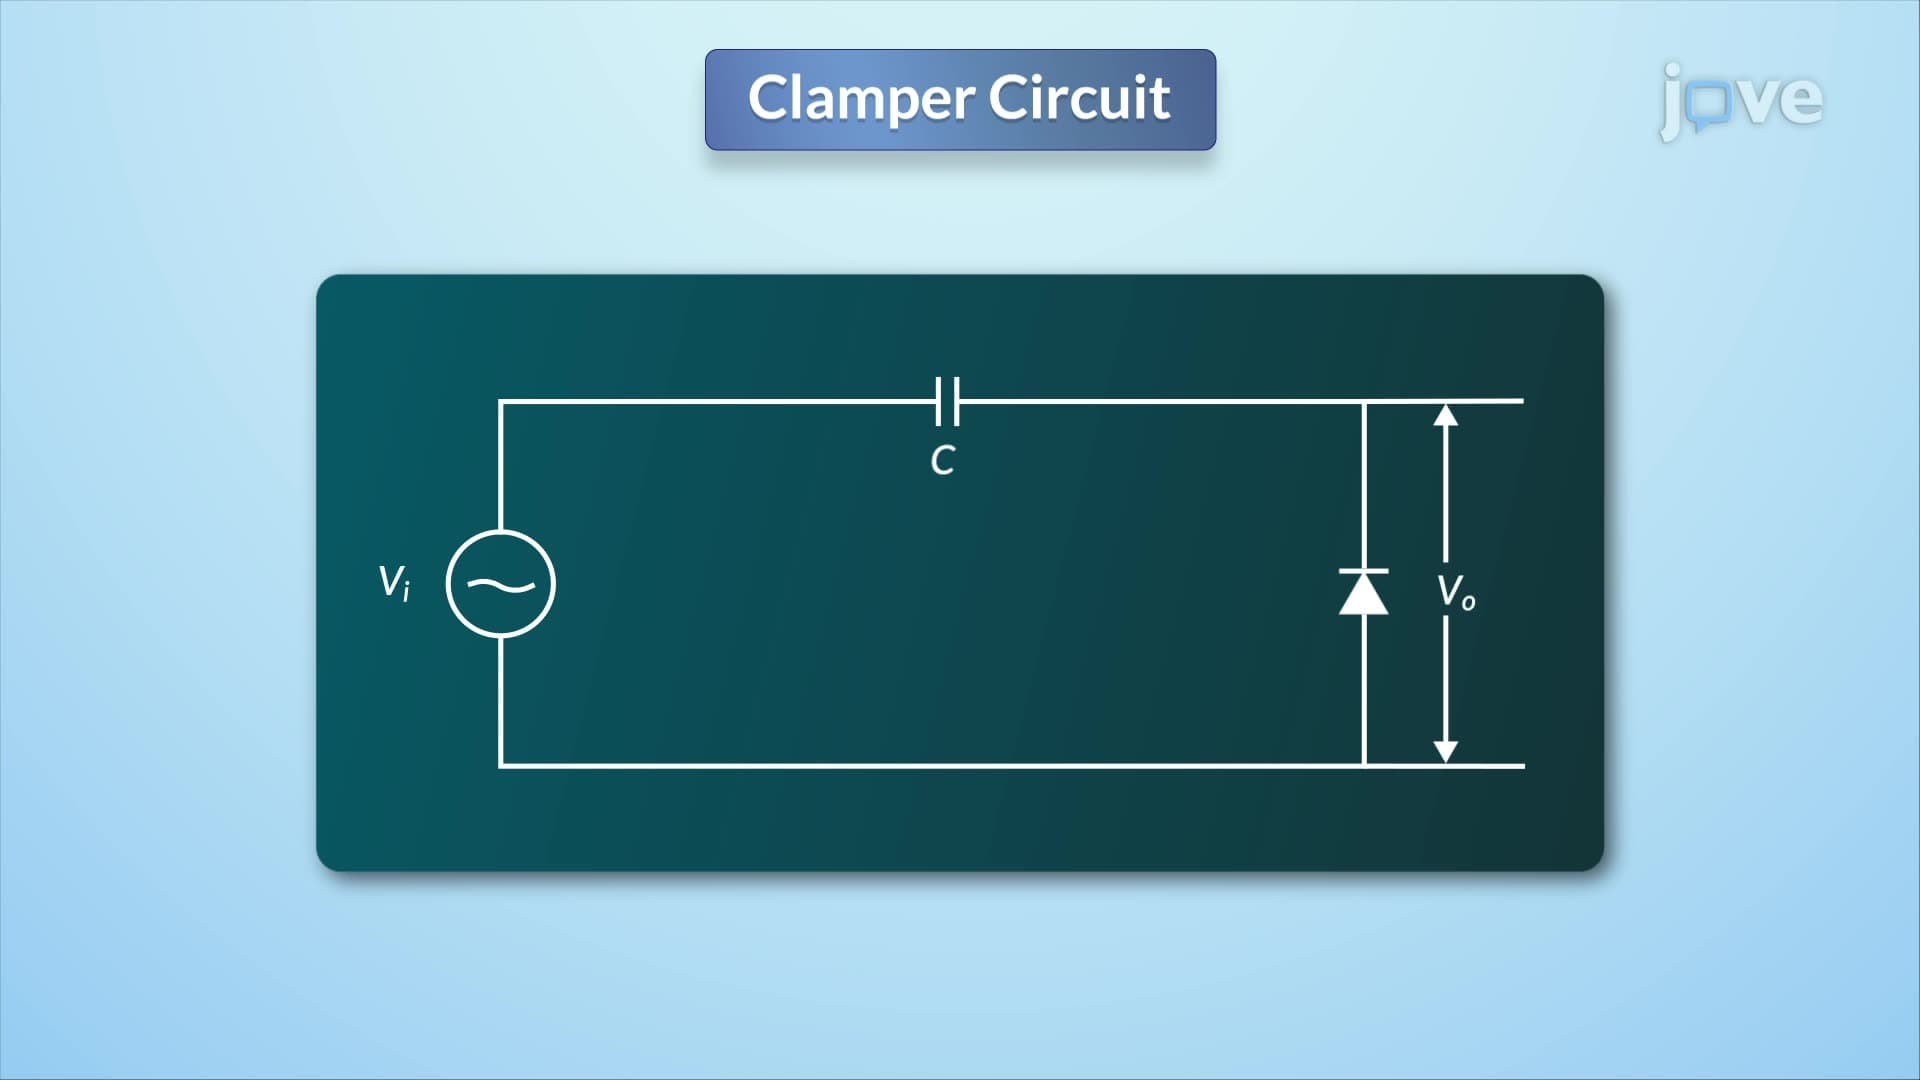
Clamper Circuit
Within this circuit, the diode's orientation prompts the capacitor to charge up to the level of the most negative peak of the input signal. Upon reaching this state, the diode ceases to conduct,...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:20
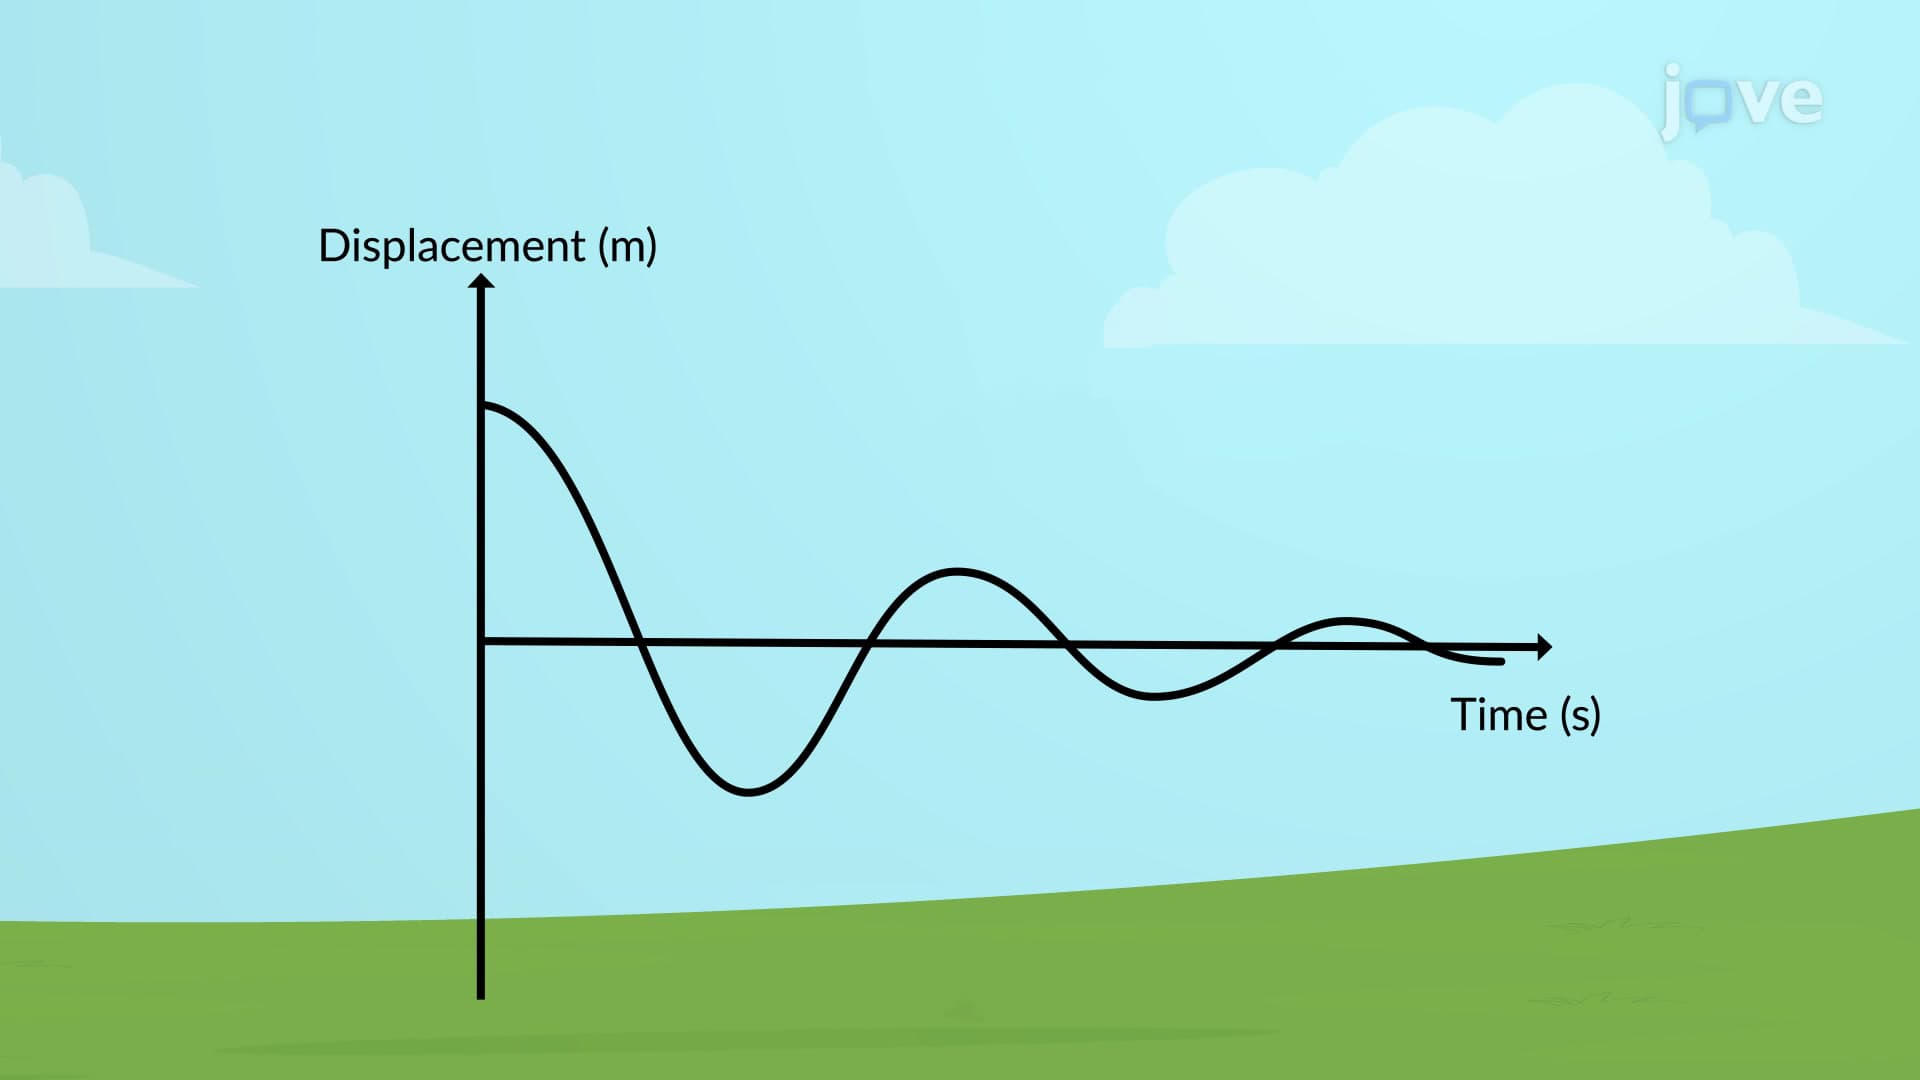
Types of Damping
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:18
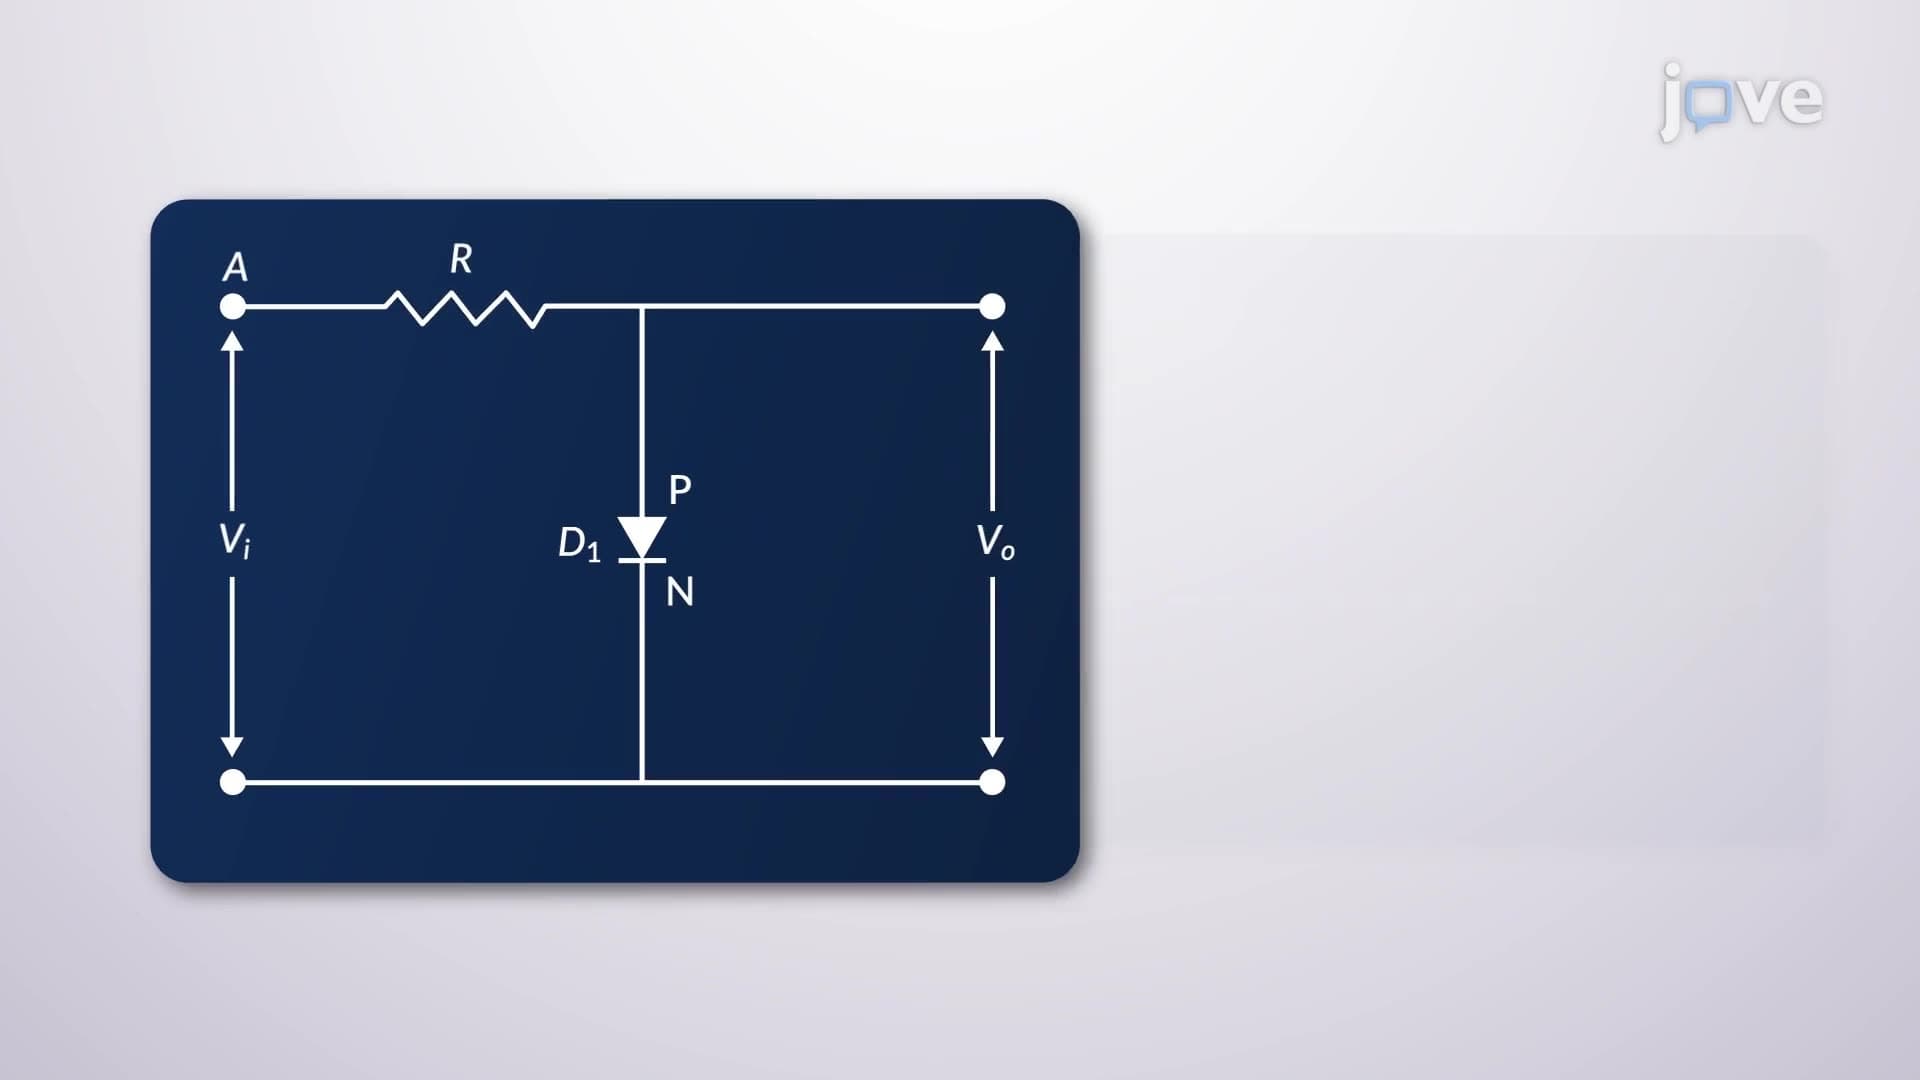
Clipper Circuit
The operation of a clipper circuit can be exemplified by analyzing a dual-clipper configuration setup that integrates two ideal diodes, each paired with a biasing...
 01:07
Damped Oscillations
Although friction and other non-conservative...