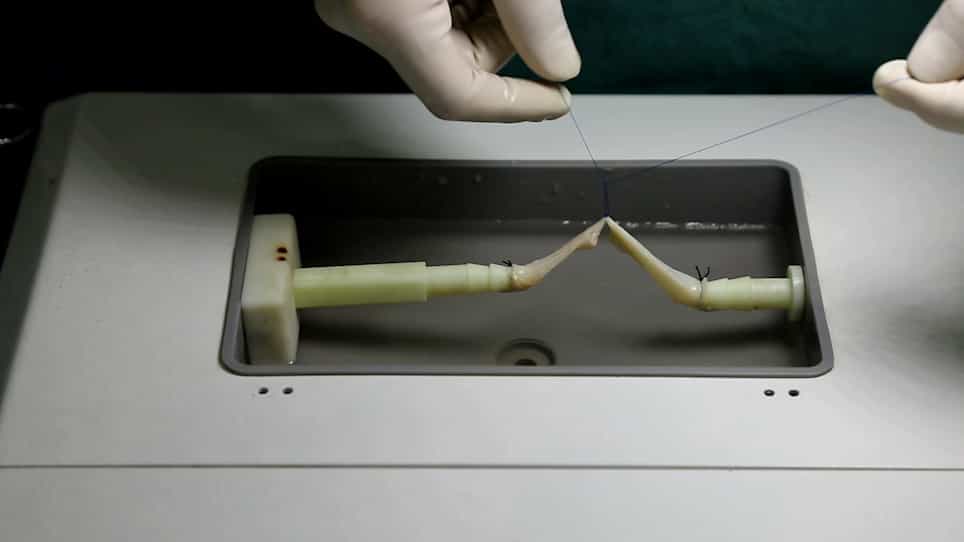
Related Experiment Video
Updated: Jun 20, 2026

Surgical Robot-Assisted Transanal Specimen Extraction Radical Sigmoidectomy Without an Auxiliary Abdominal Incision
Published on: June 13, 2025
Mechanical analysis of end-to-end silk-sutured anastomosis for robot-assisted surgery
Ying Liu1, Shuxin Wang, S Jack Hu
1School of Mechanical Engineering, Tianjin University, Tianjin, People's Republic of China.

Background:
Robot-assisted anastomosis holds great promise for the future. To secure surgery quality, some key process factors, such as the force arrangement of sutures, should be provided because of the lack of haptic feedback in robotics systems
Methods:
A model of anastomosis is presented to establish the mechanical relationship between vessel and sutures. Stress distribution of the vessel loaded by the suture was then achieved through finite-element simulations, based on the material property test results. Further, experiments were performed to validate the reliability of the FEM simulation of the anastomosis process.
Results:
To avoid blood osmosis, the allowable lower limit of the suture tension was 0.05 N. To keep the tissue free from injury, the allowable upper limit of tension on the suture was 0.4 N.
Conclusions:
The study provided meaningful results for directing the robot-assisted anastomosis procedure and design of the surgical tools.