Stabilization of nonlinear systems with a slowly varying parameter by a control Lyapunov function
Related Experiment Video
Updated: Jun 17, 2026

Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
1Control & Intelligent Processing Center of Excellence, School of Electrical and Computer Engineering, University of Tehran, Tehran, Iran. shafiei@ut.ac.ir

Abstract:
Based on a control Lyapunov function (CLF) strategy, a novel approach for designing a controller for a slowly varying nonlinear system is proposed. The approach may be thought of as being in between the time-invariant and time-varying CLF techniques. If the time-invariant technique is used to control a slowly varying system, stability will not be guaranteed. On the other hand, the time-varying CLF technique, due to the control law, has complexity and needs to measure or estimate the derivative of system parameters. The advantage of the proposed method is its independence from the measurement or estimation of the derivatives of the system parameters. It is shown that the proposed control law can even be independent of the parameters of the system. In this paper, the conditions are derived that allow using the simple CLF formula that guarantees the stability of a slowly varying system. The efficiency of the approach is shown through some simulations.
Related Concept Videos
 01:28
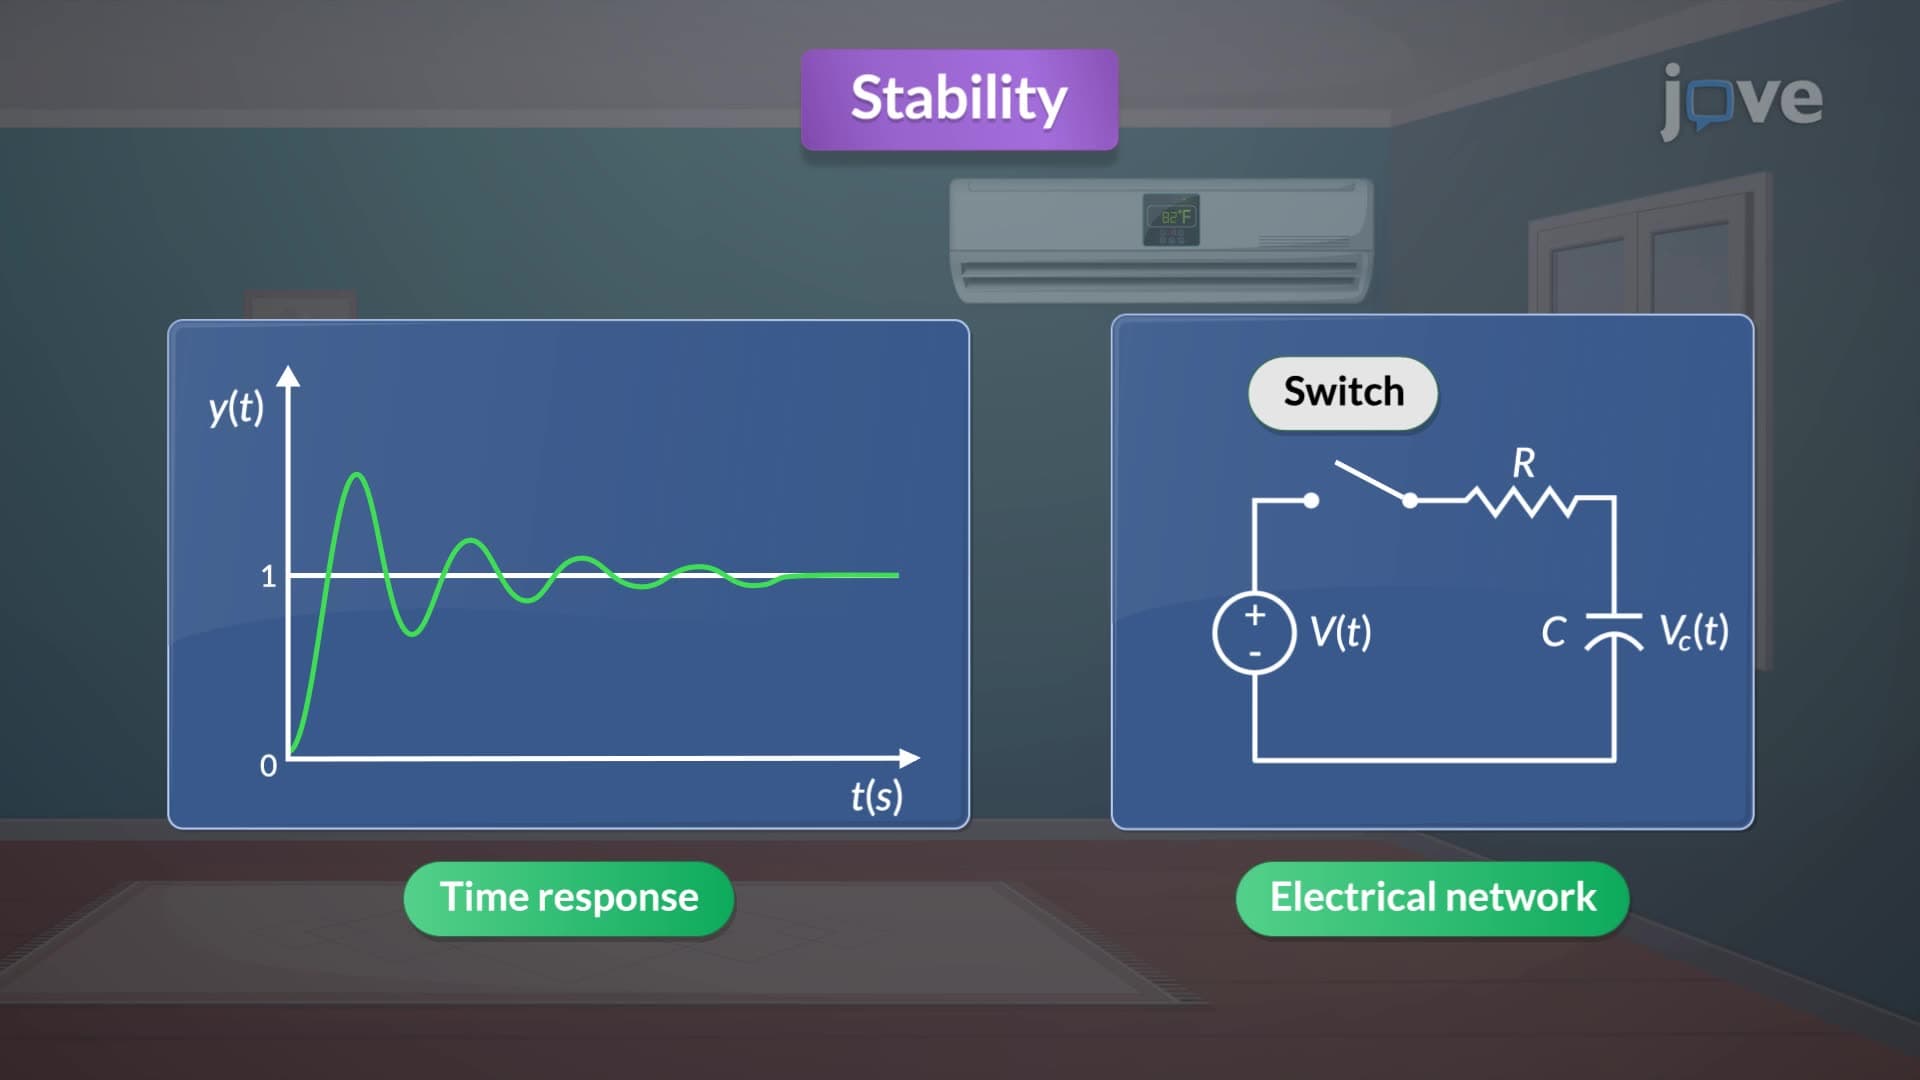
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.