Real-time random delay compensation with prediction-based digital redesign

Yongpeng Zhang1, Penrose Cofie, Augustine N Ajuzie

  • 1Engineering Technology Department, Prairie View A&M University, Prairie View, TX 77446, United States. ypzhang@pvamu.edu

ISA Transactions
|January 4, 2011
PubMed

Related Concept Videos

PD Controller: Design01:26

PD Controller: Design

In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Time-Domain Interpretation of PD Control01:07

Time-Domain Interpretation of PD Control

Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Reconstruction of Signal using Interpolation01:10

Reconstruction of Signal using Interpolation

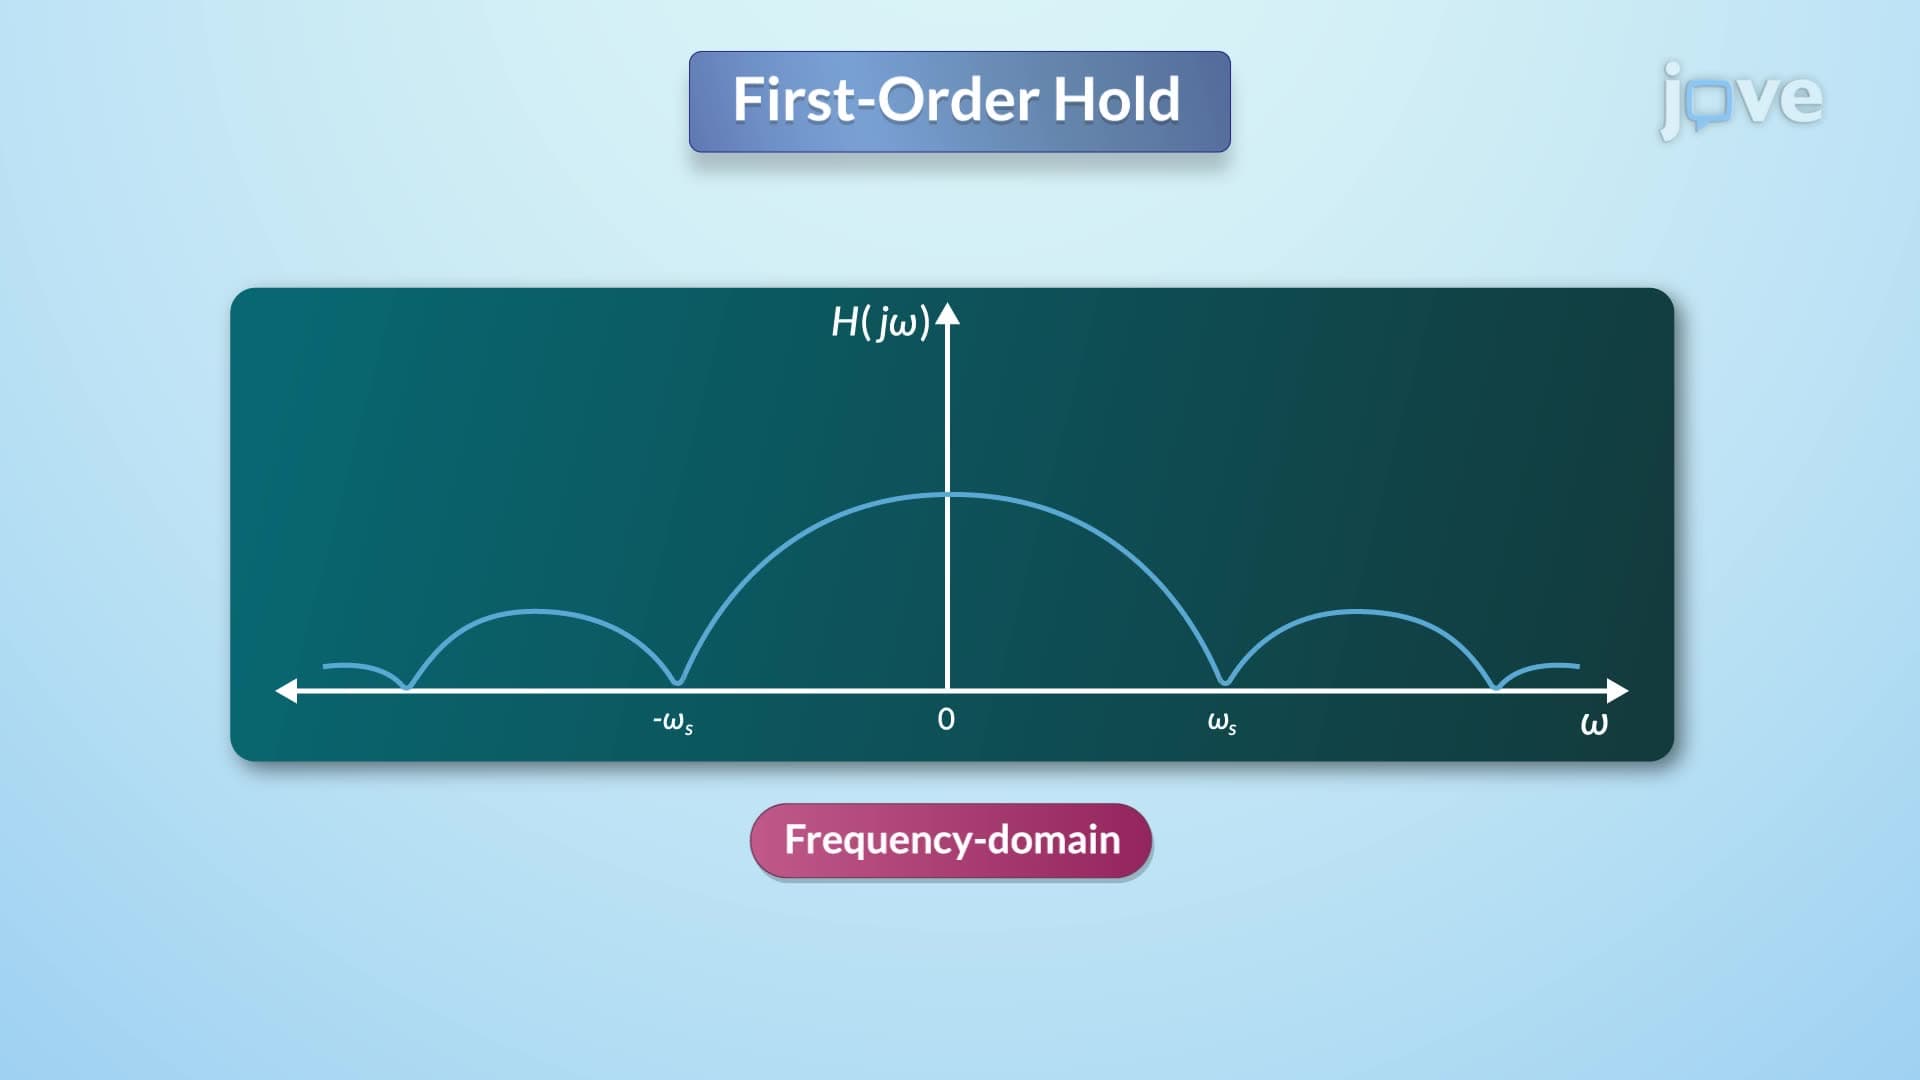
Signal processing techniques are essential for accurately converting continuous signals to digital formats and vice versa. When a continuous signal is sampled with a period T, the resulting sampled signal exhibits replicas of the original spectrum in the frequency domain, spaced at intervals equal to the sampling frequency. To handle this sampled signal, a zero-order hold method can be applied, which creates a piecewise constant signal by retaining each sample's value until the next sampling...
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
Upsampling01:22

Upsampling

Managing signal sampling rates is essential in digital signal processing to maintain signal integrity. A decimated signal, characterized by a reduced frequency range due to its lower sampling rate, can be upsampled by inserting zeros between each sample. This upsampling process expands the original spectrum and introduces repeated spectral replicas at intervals dictated by the new Nyquist frequency. To refine this zero-inserted sequence, it is passed through a lowpass filter with a cutoff...
Time and frequency -Domain Interpretation of Phase-lead Control01:24

Time and frequency -Domain Interpretation of Phase-lead Control

Phase-lead controllers are commonly used in various control systems to enhance response speed and stability. Adjusting the brightness on a television screen offers a practical example of phase-lead control. When contrast is enhanced, a phase-lead controller is employed. Mathematically, phase-lead control is identified when the first parameter is smaller than the second.
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...

