Related Experiment Video
Updated: Jun 2, 2026
Experimental Investigation of Secondary Flow Structures Downstream of a Model Type IV Stent Failure in a 180° Curved Artery Test Section
Published on: July 19, 2016
Steerable pyramids and tight wavelet frames in L2(R(d))
Michael Unser1, Nicolas Chenouard, Dimitri Van de Ville
1Biomedical Imaging Group, École Polytechnique Fédérale de Lausanne, CH-1015 Lausanne, Switzerland.

Abstract:
We present a functional framework for the design of tight steerable wavelet frames in any number of dimensions. The 2-D version of the method can be viewed as a generalization of Simoncelli's steerable pyramid that gives access to a larger palette of steerable wavelets via a suitable parametrization. The backbone of our construction is a primal isotropic wavelet frame that provides the multiresolution decomposition of the signal. The steerable wavelets are obtained by applying a one-to-many mapping (Nth-order generalized Riesz transform) to the primal ones. The shaping of the steerable wavelets is controlled by an M×M unitary matrix (where M is the number of wavelet channels) that can be selected arbitrarily; this allows for a much wider range of solutions than the traditional equiangular configuration (steerable pyramid). We give a complete functional description of these generalized wavelet transforms and derive their steering equations. We describe some concrete examples of transforms, including some built around a Mallat-type multiresolution analysis of L(2)(R(d)), and provide a fast Fourier transform-based decomposition algorithm. We also propose a principal-component-based method for signal-adapted wavelet design. Finally, we present some illustrative examples together with a comparison of the denoising performance of various brands of steerable transforms. The results are in favor of an optimized wavelet design (equalized principal component analysis), which consistently performs best.
Related Concept Videos
 01:19
Routh-Hurwitz Criterion II
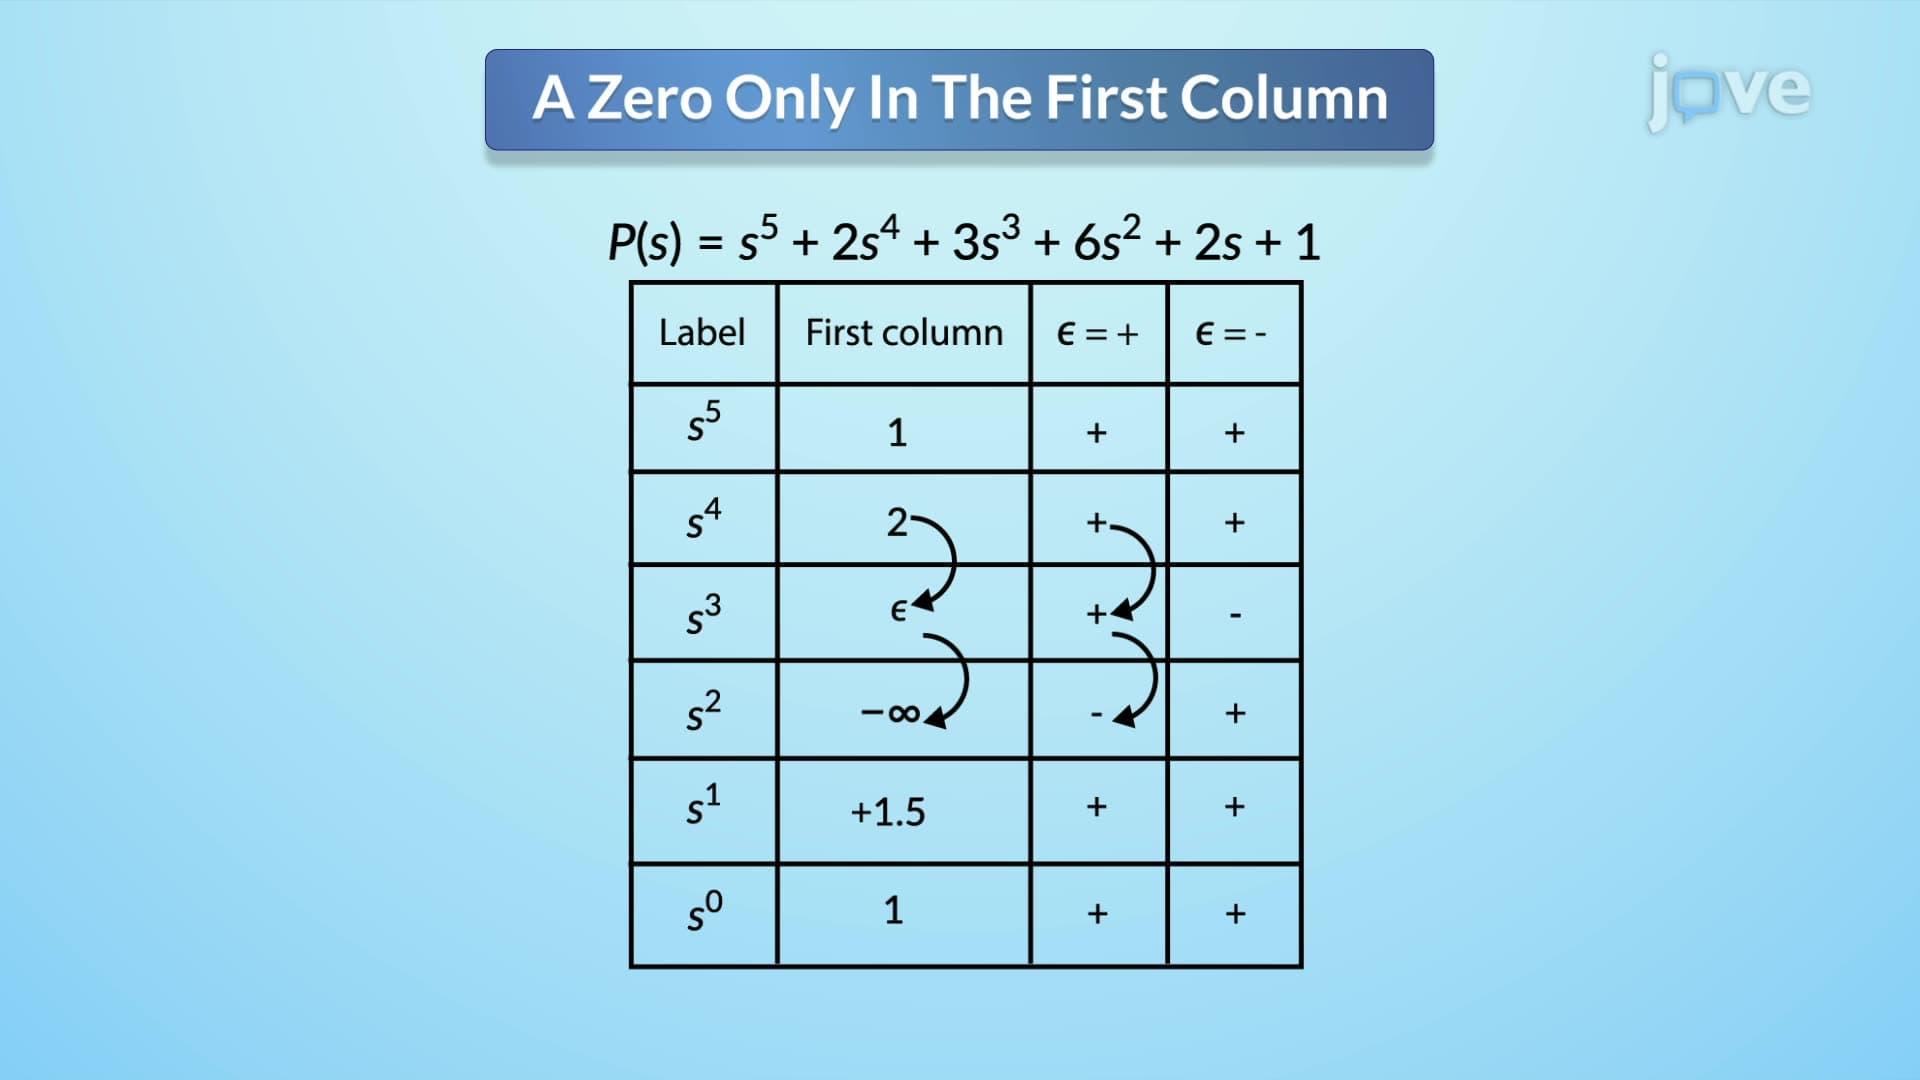
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first column of the Routh...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:15
Routh-Hurwitz Criterion I
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...