Related Experiment Video
Updated: May 25, 2026
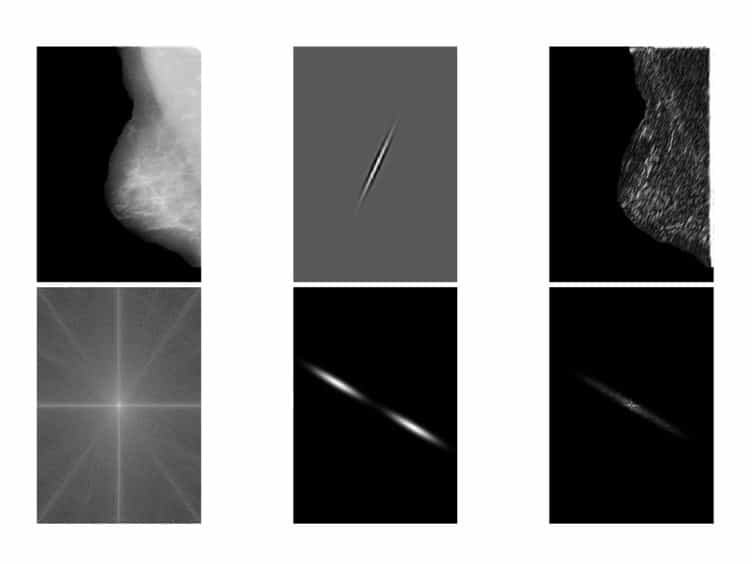
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Rigid-motion-invariant classification of 3-D textures
Saurabh Jain1, Manos Papadakis, Sanat Upadhyay
1Center for Imaging Science, John Hopkins University, Baltimore, MD 21218, USA.

Abstract:
This paper studies the problem of 3-D rigid-motion-invariant texture discrimination for discrete 3-D textures that are spatially homogeneous by modeling them as stationary Gaussian random fields. The latter property and our formulation of a 3-D rigid motion of a texture reduce the problem to the study of 3-D rotations of discrete textures. We formally develop the concept of 3-D texture rotations in the 3-D digital domain. We use this novel concept to define a "distance" between 3-D textures that remains invariant under all 3-D rigid motions of the texture. This concept of "distance" can be used for a monoscale or a multiscale 3-D rigid-motion-invariant testing of the statistical similarity of the 3-D textures. To compute the "distance" between any two rotations R(1) and R(2) of two given 3-D textures, we use the Kullback-Leibler divergence between 3-D Gaussian Markov random fields fitted to the rotated texture data. Then, the 3-D rigid-motion-invariant texture distance is the integral average, with respect to the Haar measure of the group SO(3), of all of these divergences when rotations R(1) and R(2) vary throughout SO(3). We also present an algorithm enabling the computation of the proposed 3-D rigid-motion-invariant texture distance as well as rules for 3-D rigid-motion-invariant texture discrimination/classification and experimental results demonstrating the capabilities of the proposed 3-D rigid-motion texture discrimination rules when applied in a multiscale setting, even on very general 3-D texture models.
Related Concept Videos
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...
 01:27
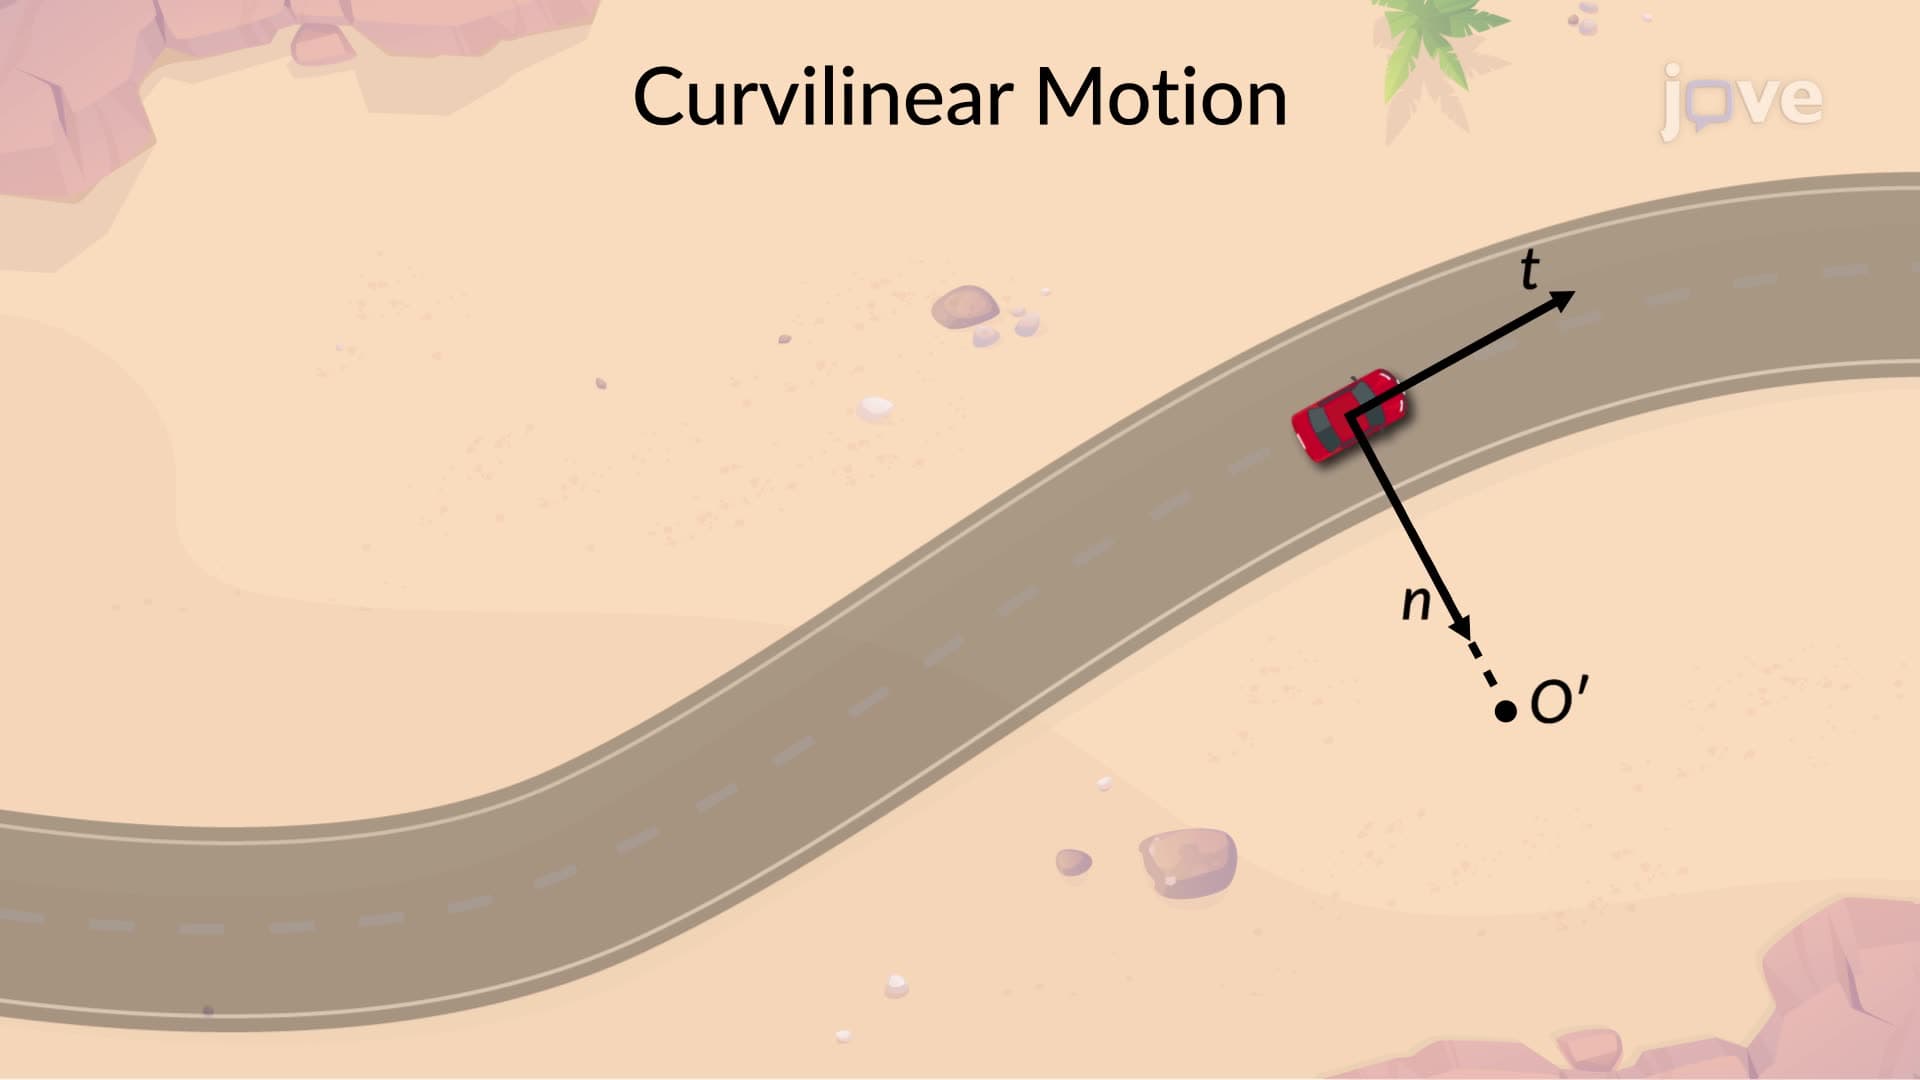
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...