The simulation of aerial movement--I. The determination of orientation angles from film data
Related Experiment Video
Updated: Aug 19, 2026
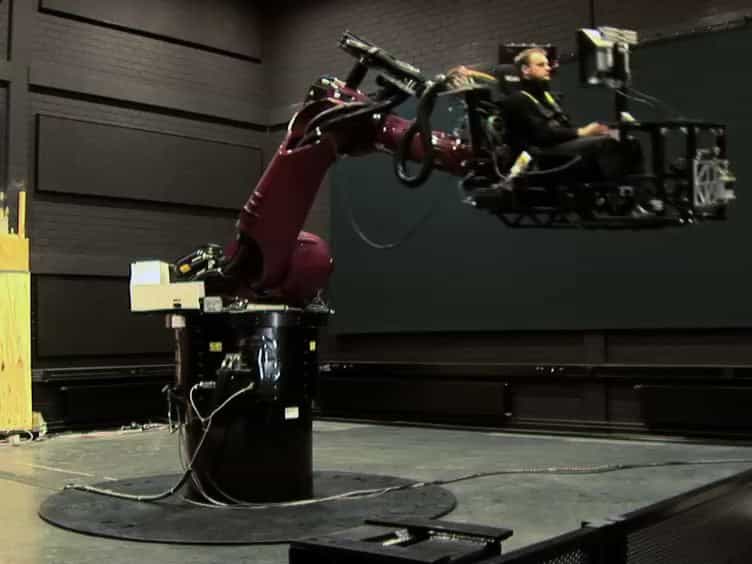
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
1Biomechanics Laboratory, Faculty of Physical Education, University of Calgary, Canada.

Abstract:
Quantitative mechanical analyses of human movement require the time histories of the angles which specify body configuration and orientation. When these angles are obtained from a filmed performance they may be used to evaluate the accuracy of a simulation model. This paper presents a method of determining orientation angles and their rates of change from film data. The stages used comprise the synchronization of data obtained from two camera views, the determination of three-dimensional coordinates of joint centres, the calculation of an angle from a sequence of sine and cosine values and the curve fitting of angles using quintic splines. For each stage, other possible approaches are discussed. Original procedures are presented for obtaining individual error estimates of both the film data and the calculated angles to permit the automatic fitting of quintic splines for interpolation and differentiation and for deriving the time history of an angle as a continuous function from a sequence of sine and cosine values. The method is applied to a forward somersault with 1 1/2 twists and the average error estimate of 17 orientation angles is obtained as 2.1 degrees.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Application of Linearization and Approximation
 01:30
Vector Functions and Motion: Problem Solving