Related Experiment Video
Updated: May 14, 2026
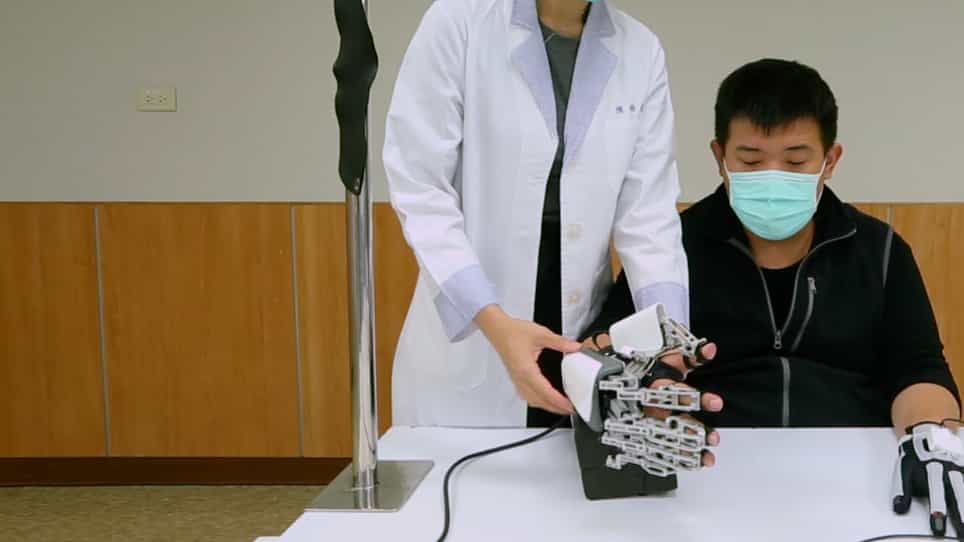
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
On the design of ergonomic wearable robotic devices for motion assistance and rehabilitation
Azzurra Chiri1, Marco Cempini, Stefano Marco Maria De Rossi
1The BioRobotics Institute, Scuola Superiore di Studi Universitari e di Perfezionamento Sant’Anna, viale Rinaldo Piaggio, 34, 56025, Pontedera, Pisa, Italy. a.chiri@sssup.it

Abstract:
The appropriate ergonomic design of a wearable robotic device is critical for the effectiveness of the device itself. In this paper we identified two key requirements for a structural ergonomics: the correct kinematic compatibility with the human limb and a comfortable and adaptable physical human-robot interface. We then show how the aforementioned requirements have been faced and implemented in the mechanical design of two wearable devices for elbow and hand rehabilitation, both developed at The BioRobotics Institute of Scuola Superiore Sant' Anna.

