H2 control of linear uncertain systems considering input quantization with encoder/decoder mismatch
Related Experiment Video
Updated: May 9, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Bo-Chao Zheng1, Guang-Hong Yang
1School of Information and Control, Nanjing University of Information Science and Technology, Nanjing, 210044, China. zhengbochao81@126.com

Abstract:
In this paper, an H2 control design for linear uncertain systems with input quantization in the presence of more general encoder/decoder mismatch is investigated. The construction of the control law includes two parts: linear part and nonlinear part. The gain of the linear part is derived from linear matrix inequalities (LMIs), and the linear part of the control law is designed for achieving the H2 performance against system characteristic matrix uncertainty and encoder/decoder mismatch. The nonlinear part is designed to eliminate the influence of external disturbance and quantization error. Finally, examples are provided to illustrate the effectiveness of the proposed method.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
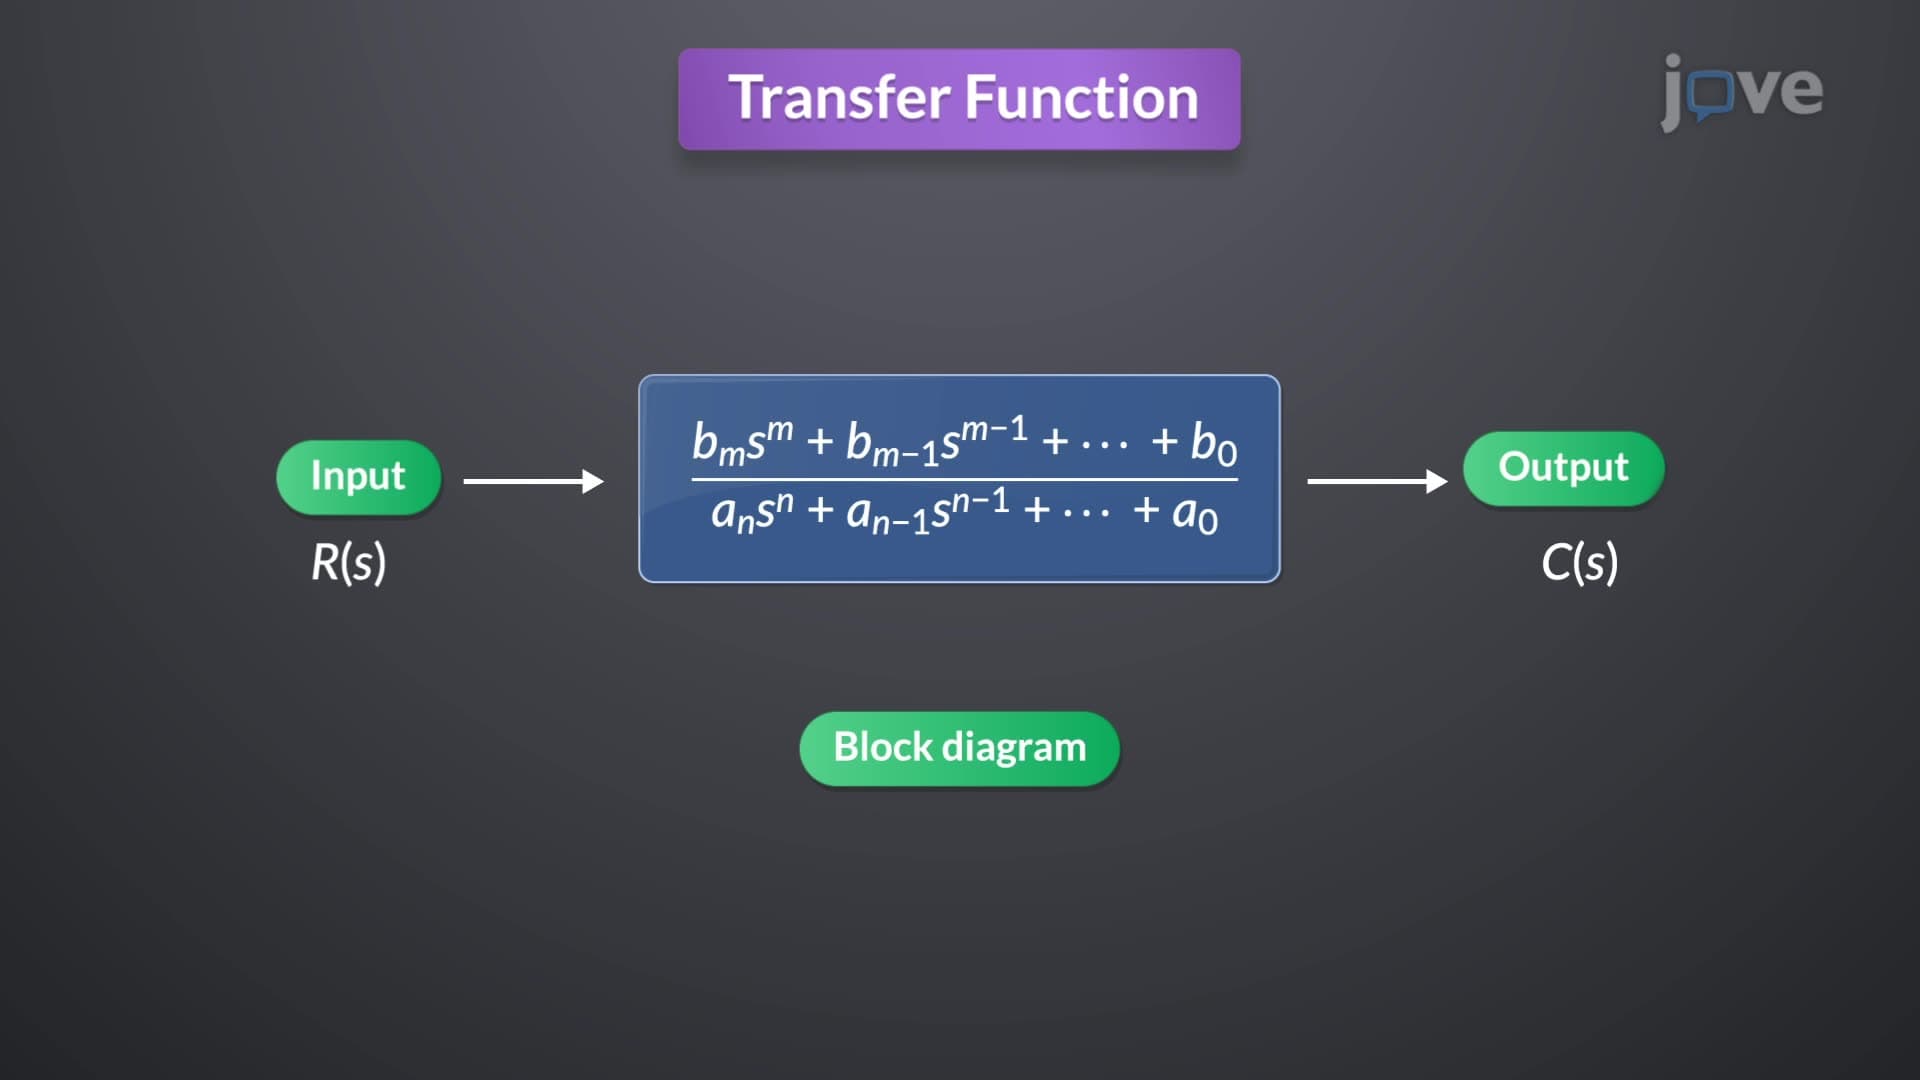
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:26
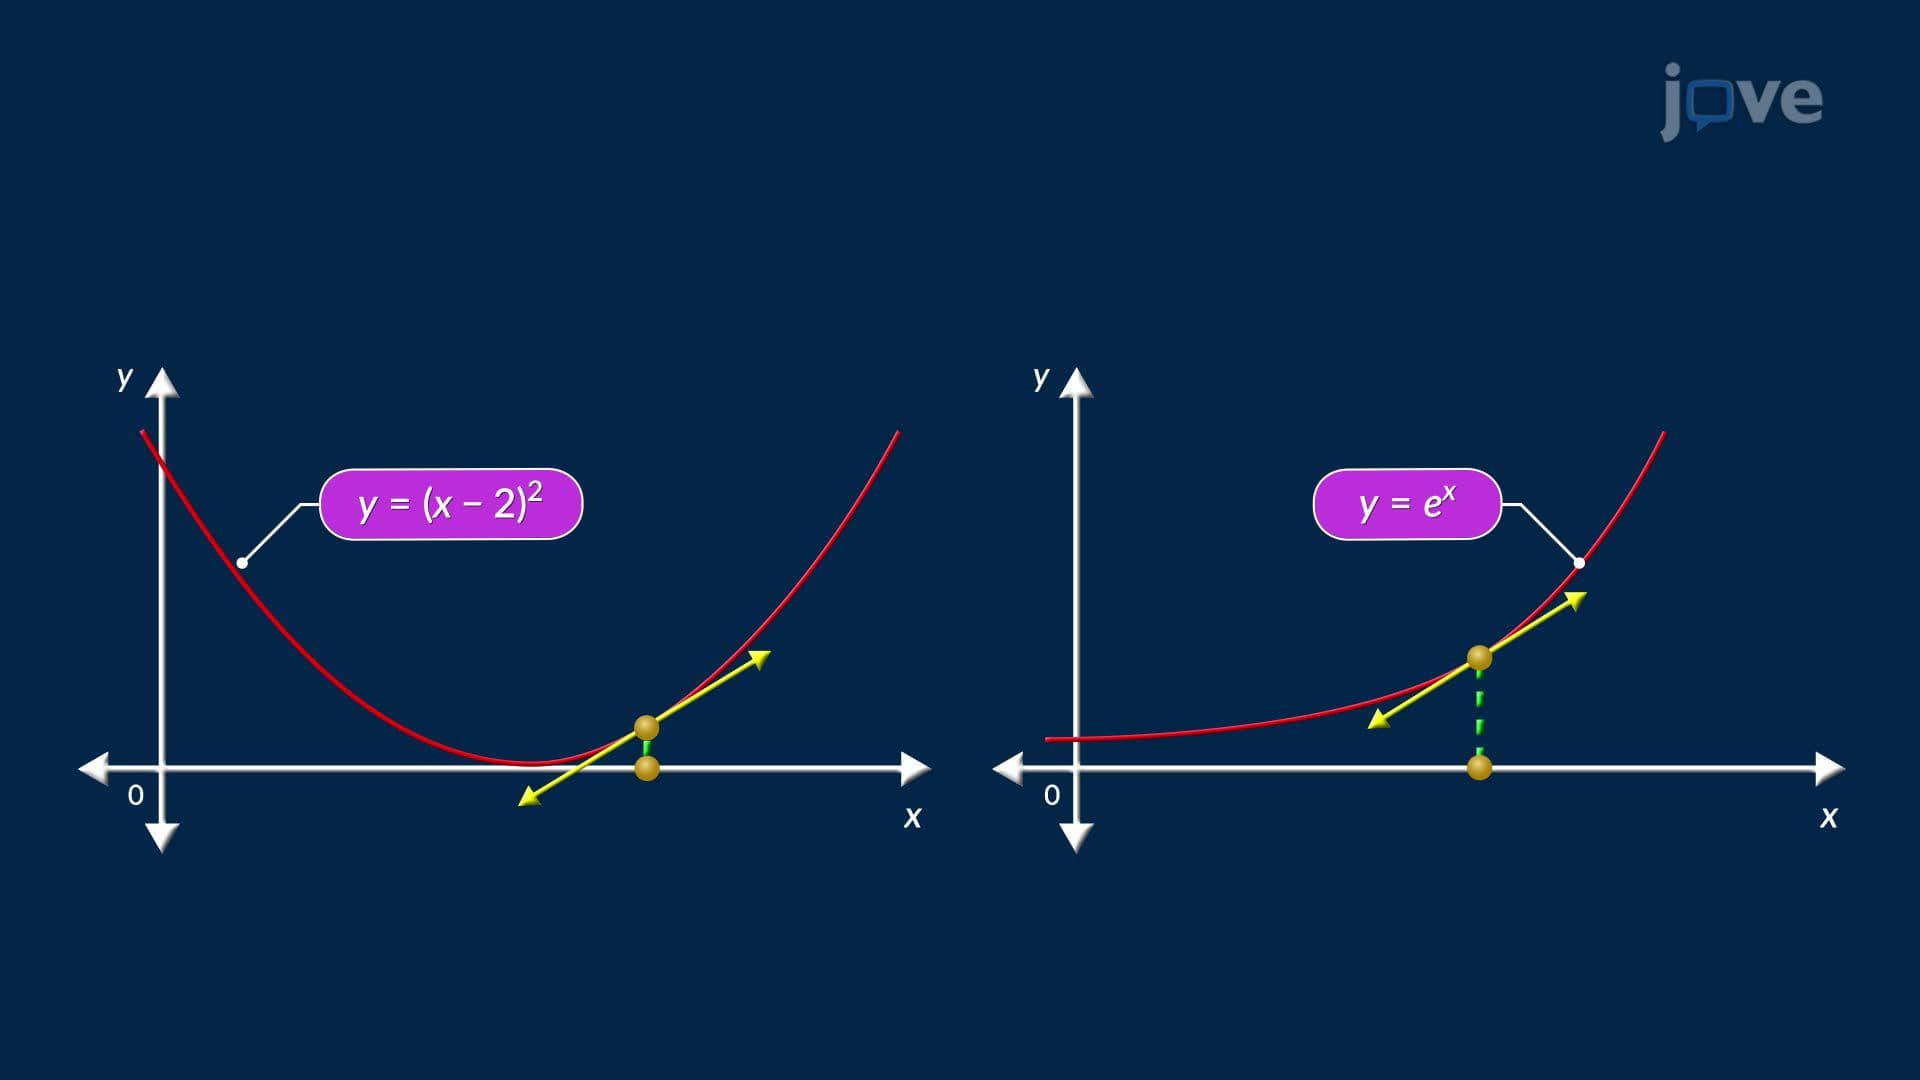
Linearization and Approximation
 01:18
Second Order systems II
If ζ...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...