Related Experiment Video
Updated: May 6, 2026

Measuring Delay Discounting in Humans Using an Adjusting Amount Task
Published on: January 9, 2016
Further results on delay-range-dependent stability with additive time-varying delay systems
1Department of Automation Engineering Institute of Mechatronoptic System, Chienkuo Technology University, 1 Chien-Shous N. Load, Changhua 500, Taiwan, ROC.

Abstract:
In this paper, new conditions for the delay-range-dependent stability analysis of time-varying delay systems are proposed in a Lyapunov-Krasovskii framework. Time delay is considered to be time-varying and has lower and upper bounds. A new method is first presented for a system with two time delays, integral inequality approach (IIA) used to express relationships among terms of Leibniz-Newton formula. Constructing a novel Lyapunov-Krasovskii functional includes information belonging to a given range; new delay-range-dependent criterion is established in term of linear matrix inequality (LMI). The advantage of that criterion lies in its simplicity and less conservative. This paper also presents a new result of stability analysis for continuous systems with two additive time-variant components representing a general class of delay with strong application background in network-based control systems. Resulting criteria are then expressed in terms of convex optimization with LMI constraints, allowing for use of efficient solvers. Finally, three numerical examples show these methods reducing conservatism and improving maximal allowable delay.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:28
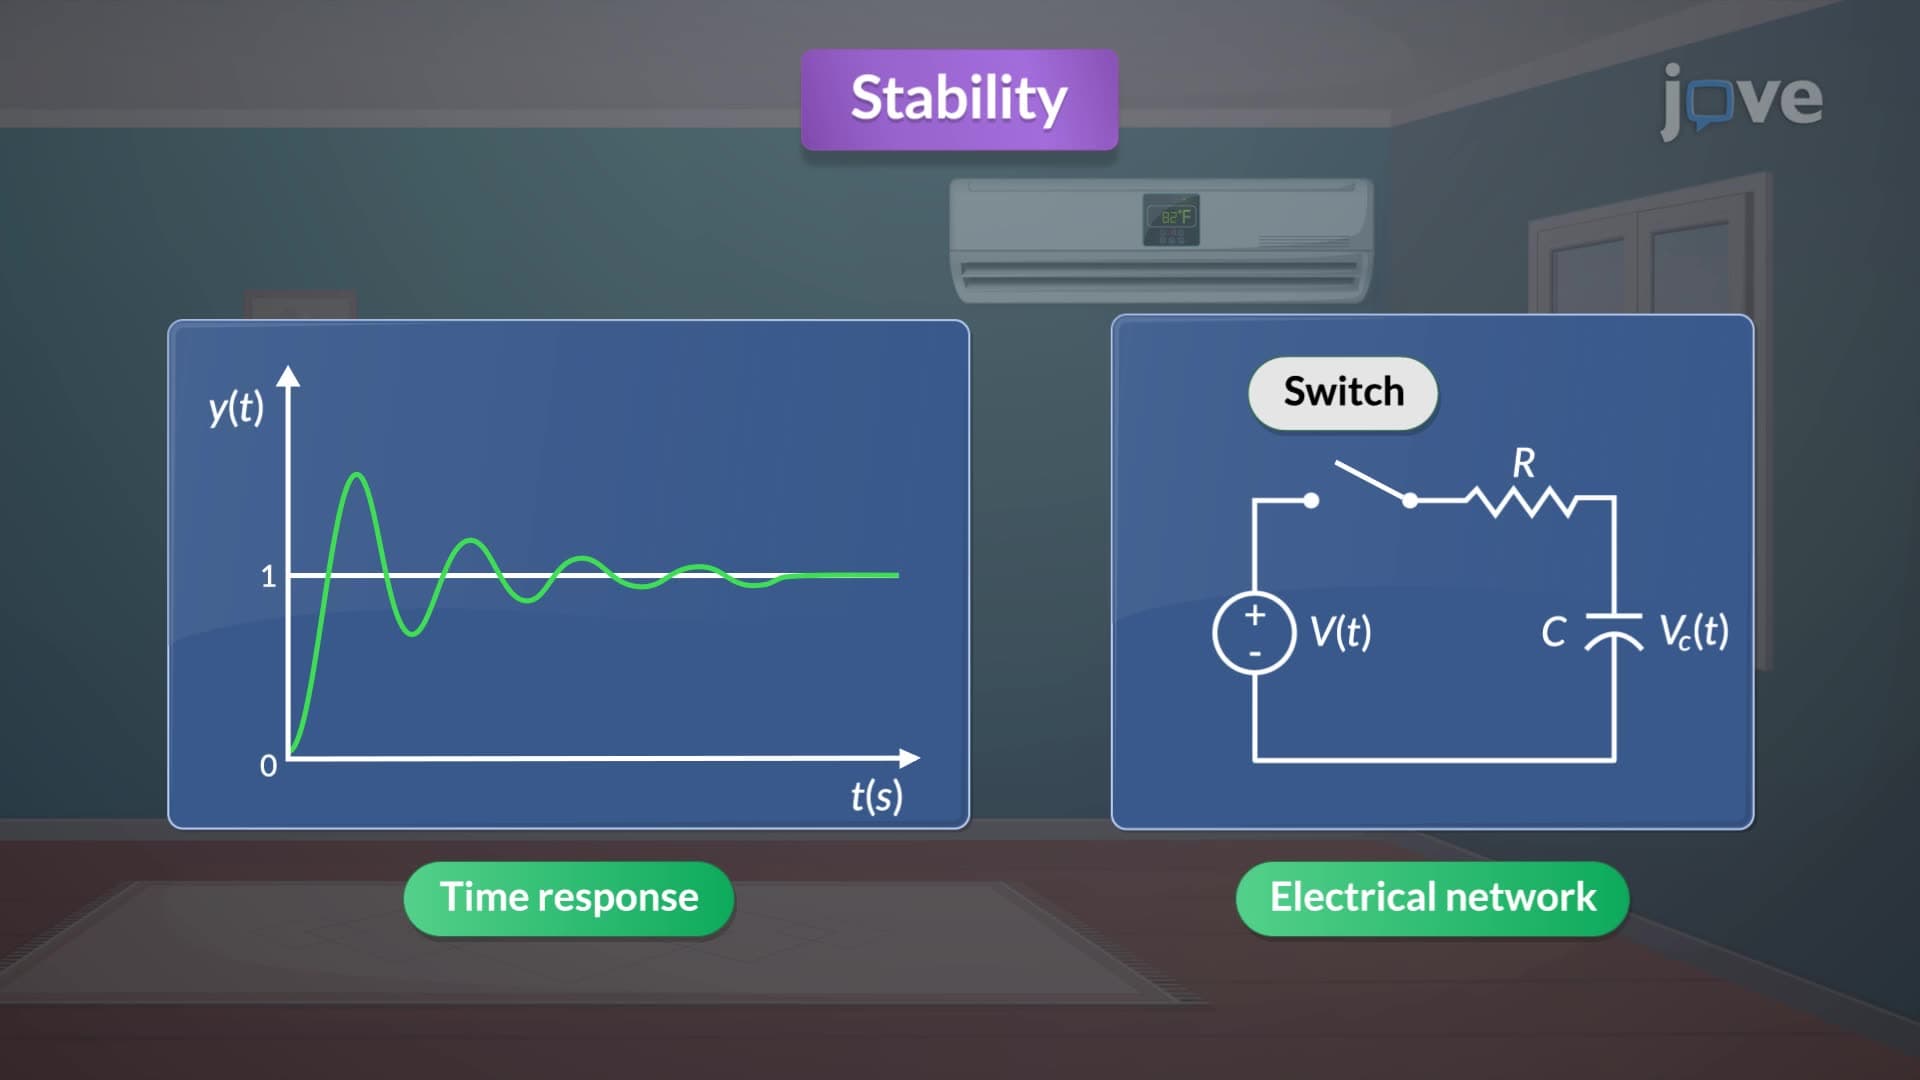
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:31
Classification of Systems-II
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...